Related Experiment Video
Updated: Jan 10, 2026


Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
High-Speed, Maneuverable, and Terrain-Adaptive Micro-Robot with Tree Frog-Inspired Bionic Feet
Weizhi Zhao1, Shijia Li1, Kaiwen Zhang1,2
1Research Institute of Aero Engine, Beihang University, Beijing, 100191, China.

Abstract:
Micro-robots hold promise for complex tasks such as fault diagnosis and emergency response, where conventional detection methods are limited by size and maneuverability constraints. However, their adaptability in complex environments remains insufficient owing to reduced propulsion efficiency. This study proposes a 7.5 mm micro-robot actuated by an electromagnetic linear motor and integrated with tree frog-inspired bionic feet (MRBF) to enhance traction and locomotion performance. The bionic feet are fabricated via angled photolithography to realize the microstructured design. The integration of bionic feet enables the MRBF to reach a maximum velocity of 39 body lengths per second (BL s-1) on dry surfaces and 28.5 BL s-1 on wet surfaces, representing improvements of 75% and 40%, respectively, compared to the non-bionic version. The MRBF can also climb inclines of up to 21.8°, nearly doubling its original climbing limit of 11°, demonstrating a considerably enhanced slope-climbing capability. A dual-MRBF system is specifically designed to achieve rapid and controllable turning, attaining angular velocities of ≈311° s-1. When equipped with a micro-camera, MRBFs are successfully deployed for in situ blade inspection within the confined intake duct of a micro-aero-engine. This strategy provides a scalable framework for adaptive, high-performance systems in aerospace inspection, soft robotics, and autonomous sensing.


Related Concept Videos
 01:14
Design Example: Frog Muscle Response
When the switch connecting the RL circuit is closed, a brief muscle contraction is observed. This is because, at a steady state, the inductor acts like a short...
 01:16
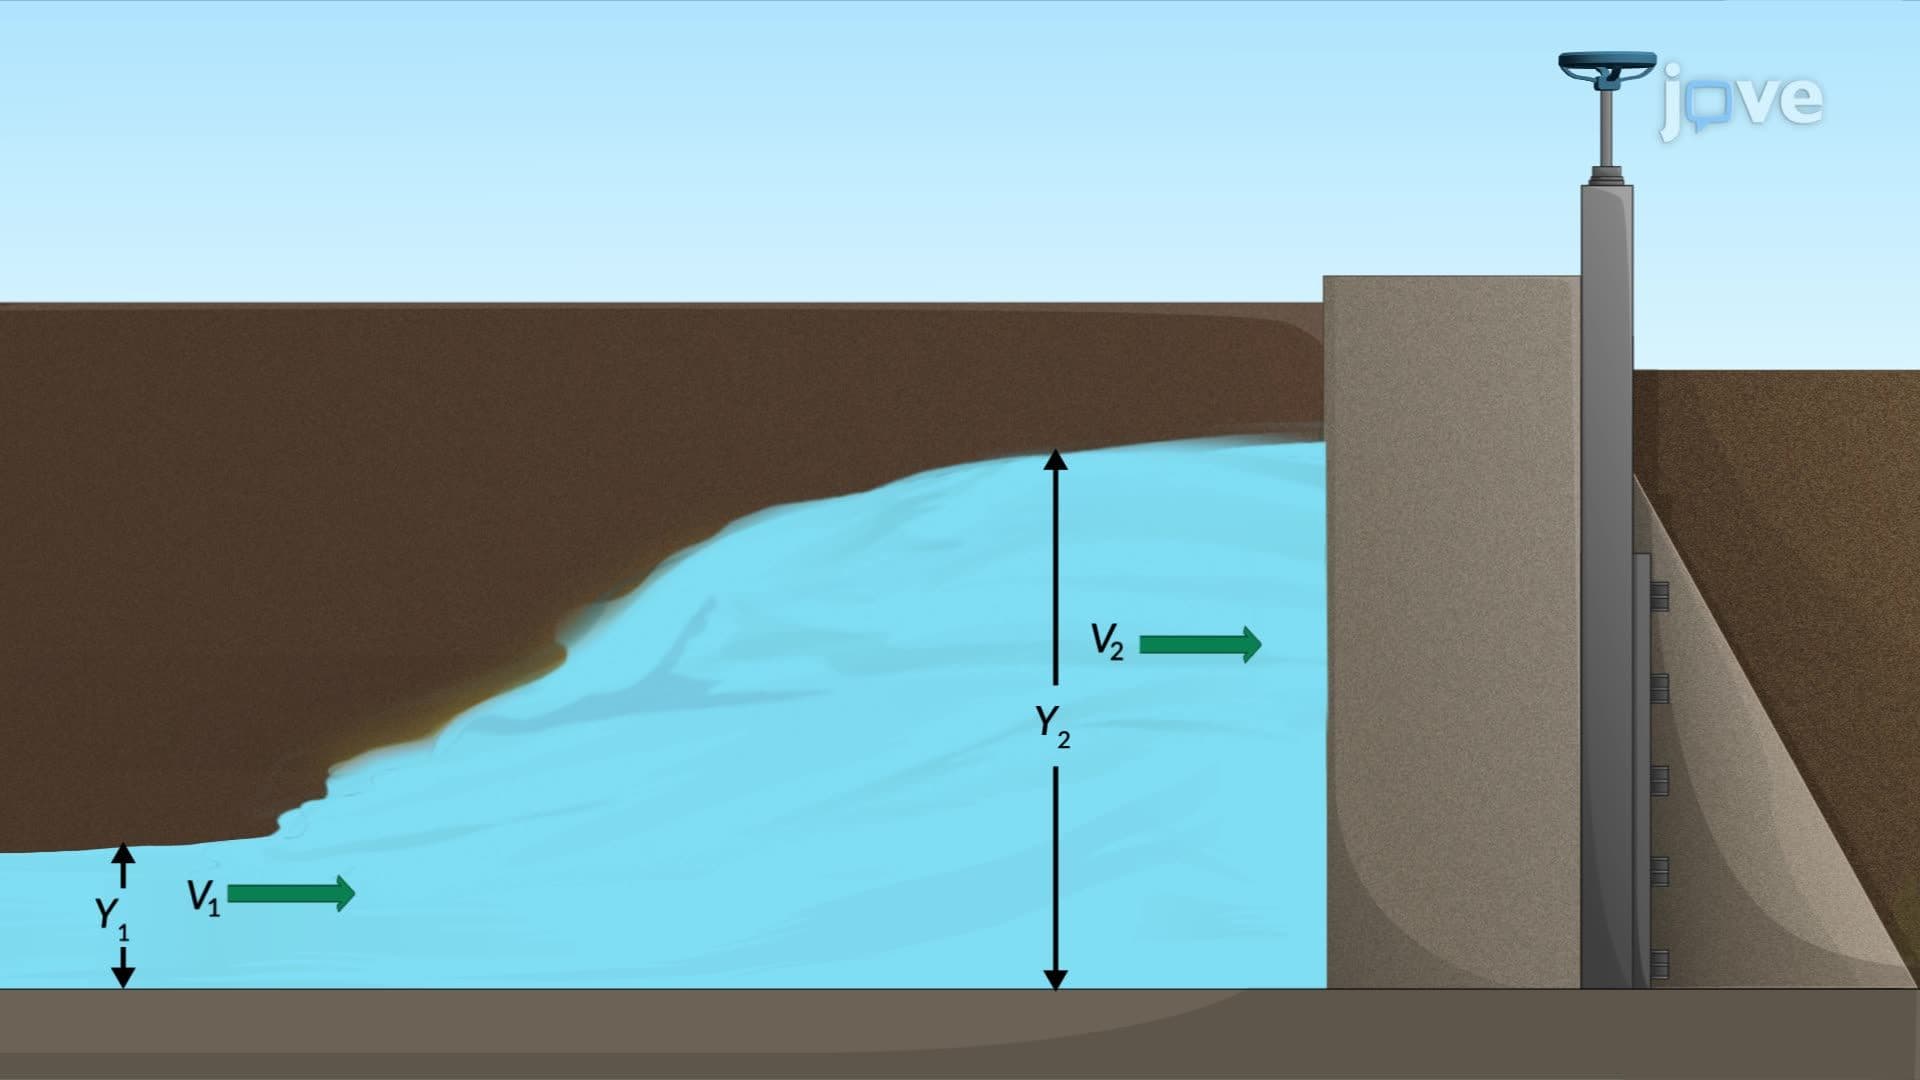
Hydraulic Jump: Problem Solving