Related Experiment Video

Updated: May 6, 2026

Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
08:08

Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis

Published on: May 8, 2014

17.2K

A Simplified Approach to Automatic Stance Control of Unilateral Knee Exoskeletons

Jason J Wiebrecht, Jacob A Strick, Douglas A Wajda

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference
    |December 3, 2025
    PubMed

    Abstract:

    For lower limb exoskeletons to be practical in real-world settings, their control systems must ensure both safety and effectiveness. A key challenge is achieving this with a simplified set of sensors, reducing system complexity without compromising performance. This paper presents a stance control algorithm that relies solely on motor current data and user kinematic information from a thigh-worn inertial measurement unit and knee encoder. The algorithm was implemented on a unilateral knee exoskeleton using a Finite State Machine to apply an automatic joint lock during stance phase of gait. The algorithm was evaluated in real-time with six healthy subjects walking on an instrumented treadmill at speeds of 0.60 m/s, 0.80 m/s and 1.00 m/s. Across subjects, no false positive or negative state transitions were observed. Locking was applied prior to heel strike, with a mean phase error of 4.81% ± 2.70%. Unlocking occurred within the desired terminal stance window, prior to toe off with a mean phase error of 5.28% ± 2.52%. These preliminary results suggest that the algorithm is effective in healthy users with varying anthropometrics and biomechanics, motivating further testing with a larger subject pool and individuals with mobility impairments.Clinical Relevance- The presented mid-level controller establishes a simple and effective methodology for automatic stance control of unilateral knee exoskeletons.

    More Related Videos

    Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
    11:16

    Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis

    Published on: July 22, 2014

    16.6K
    Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
    09:46

    Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton

    Published on: June 16, 2016

    21.3K

    Related Experiment Videos

    Last Updated: May 6, 2026

    Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
    08:08

    Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis

    Published on: May 8, 2014

    17.2K
    Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
    11:16

    Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis

    Published on: July 22, 2014

    16.6K
    Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
    09:46

    Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton

    Published on: June 16, 2016

    21.3K

    Related Concept Videos

    Knee Joint01:23

    Knee Joint

    3.4K
    The knee joint is the most complicated joint in the body. It consists of three articulations– two tibiofemoral and one patellofemoral. As is characteristic of synovial joints, the knee joint has a thin articular capsule that partially surrounds this joint cavity. Additionally, several ligaments, muscles, and cartilaginous structures support the movement of the knee.
    A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
    3.4K
    Ankle Joint01:10

    Ankle Joint

    3.4K
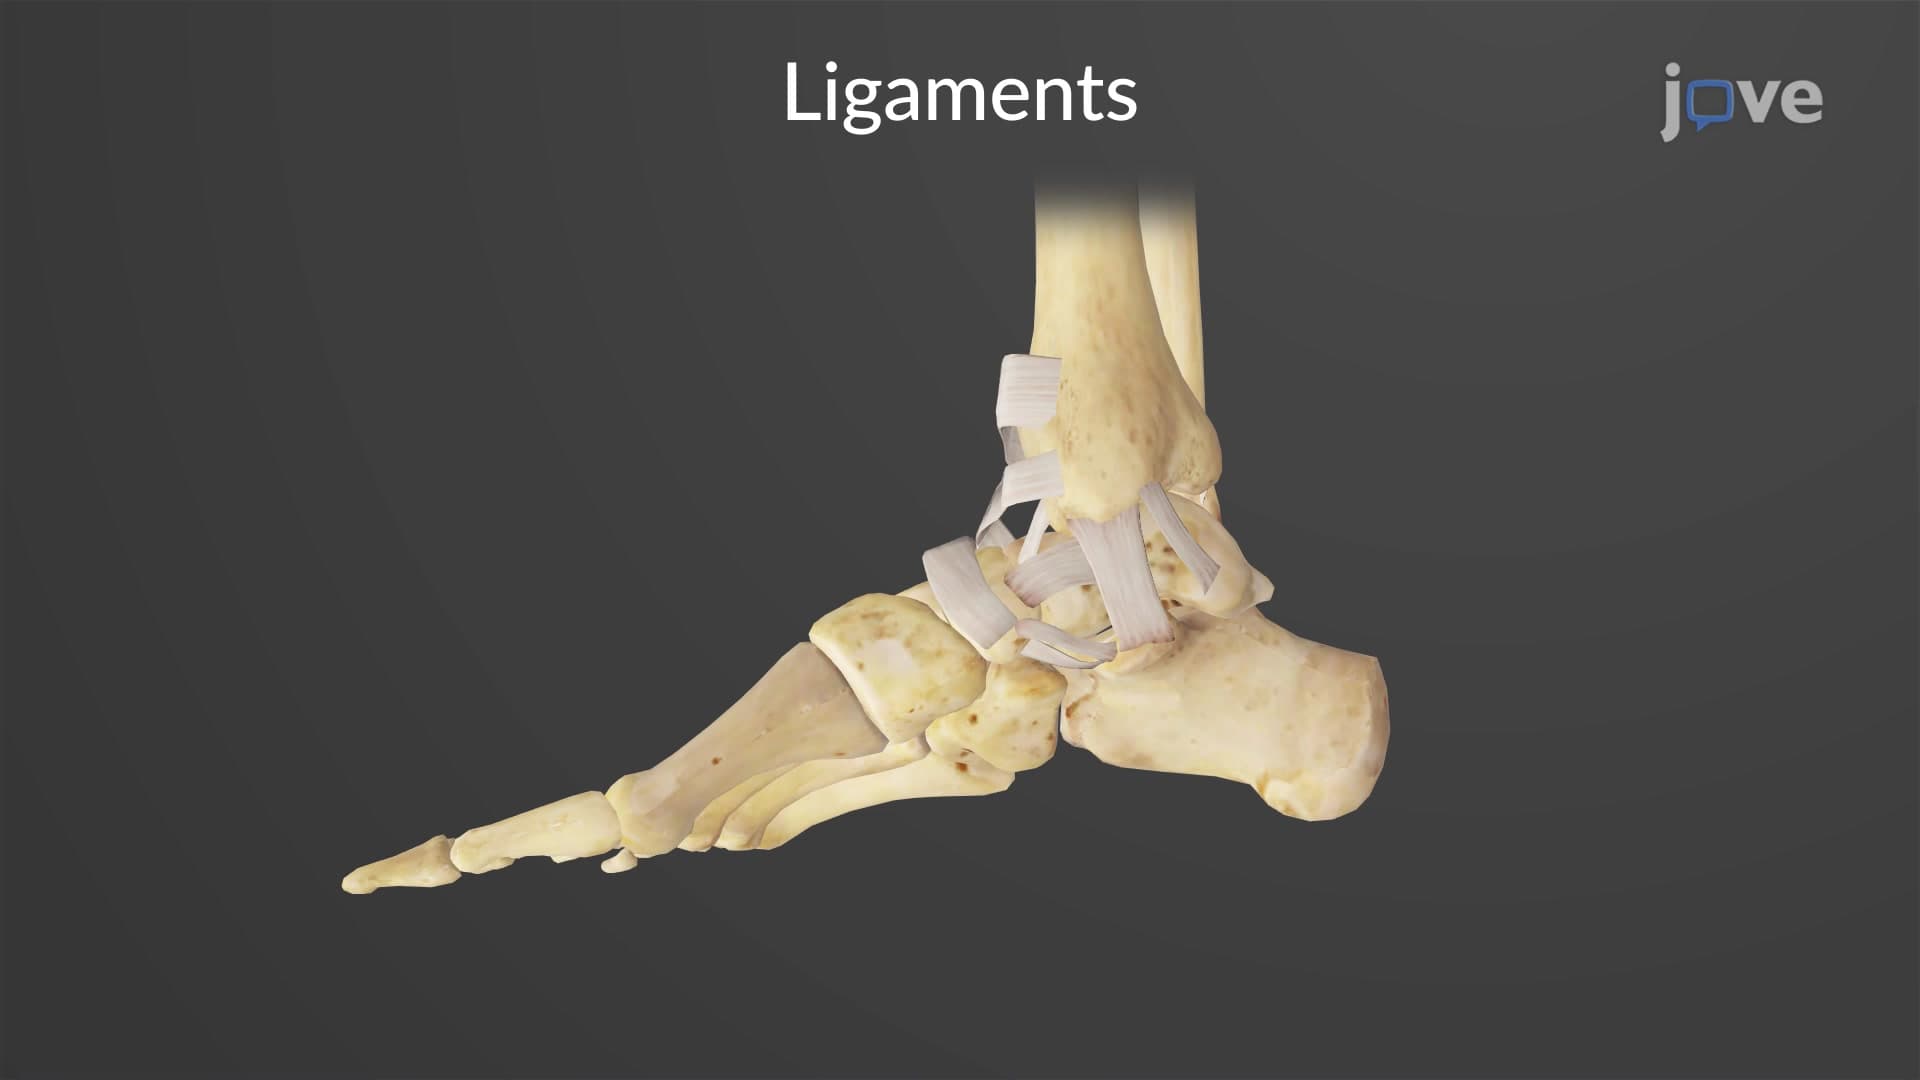
    The ankle is formed by the talocrural joint (crural = leg). It consists of the articulations between the talus bone of the foot and the distal ends of the tibia and fibula of the leg. The superior aspect of the talus bone is square-shaped and has three areas of articulation. The top of the talus articulates with the inferior tibia. This is the portion of the ankle joint that carries the body weight between the leg and foot. The sides of the talus are firmly held in position by the articulations...
    3.4K

    Articles linked to this work by shared authors, journal, and citation graph.

    Biomechanical Consequences of Motion-Restricting Lower Extremity Orthoses.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    Enhanced Gait Phase Estimation for Lower Limb Exoskeletons by Integrating Contralateral Leg Information.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    Design of a Low-Cost Solenoid Actuated Stance Control Knee Orthosis.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    Design and Validation of a Cable-Driven Joint Actuator for Pediatric Knee Orthoses.

    Journal of biomechanical engineering·2025

    Preliminary Experimental Validation of a Cable-Driven Joint System for Custom Orthoses.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    Experimental Evaluation of Machine Learning Models for Gait Segmentation.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    Analysis of End-Tidal CO2 Variability During Plateau Waves Episodes: An Information Theoretic Approach.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    AI and Tomosynthesis for Breast Cancer Molecular Subtyping: A step toward precision medicine.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    Towards Sustainable Protein Recovery from Biological Waste: Assessing Polyethersulfone-based Microfiltration.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    Analysis of the cardiovascular response to standardized polymicrobial peritonitis experimental model.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    Automated Wrist Ultrasound Image Bone Enhancement and Segmentation Using Deep Learning.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    A Deep Learning approach for Depressive Symptoms assessment in Parkinson's disease patients using facial videos.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    Efficacy of a soft robotic exoskeleton for upper-limb rehabilitation in subacute stroke inpatient rehabilitation: a randomised controlled trial.

    Journal of neuroengineering and rehabilitation·2026

    Clinical efficacy and cortical network modulation of a multimodal sensory feedback upper-limb rehabilitation robot for post-stroke upper-limb recovery: a randomized controlled trial.

    Frontiers in neurology·2026

    Whisker-based tactile flight for tiny drones.

    Nature communications·2026

    No difference in short-term revision risk between robot-assisted total knee arthroplasty and conventional techniques: An analysis of 79,115 total knee arthroplasties in the Dutch arthroplasty register.

    The Knee·2026

    Theta-gamma transcranial alternating current stimulation and complex visuomotor training in healthy young adults.

    Journal of neurophysiology·2026

    Prediction-driven active assistance control for lower-limb exoskeletons using multisource information fusion and short-term gait prediction.

    Frontiers in bioengineering and biotechnology·2026
    See all related articles
    JoVE
    x logofacebook logolinkedin logoyoutube logo
    ABOUT JoVE
    OverviewLeadershipBlogJoVE Help Center
    AUTHORS
    Publishing ProcessEditorial BoardScope & PoliciesPeer ReviewFAQSubmit
    LIBRARIANS
    TestimonialsSubscriptionsAccessResourcesLibrary Advisory BoardFAQ
    RESEARCH
    JoVE JournalMethods CollectionsJoVE Encyclopedia of ExperimentsArchive
    EDUCATION
    JoVE CoreJoVE BusinessJoVE Science EducationJoVE Lab ManualFaculty Resource CenterFaculty Site
    Terms & Conditions of Use
    Privacy Policy
    Policies
    Jove
    Visualize
    Contact Us
