Exploring Position, Velocity, and Torque Control via Minimal sEMG Calibration for Robotic Ankle Prostheses
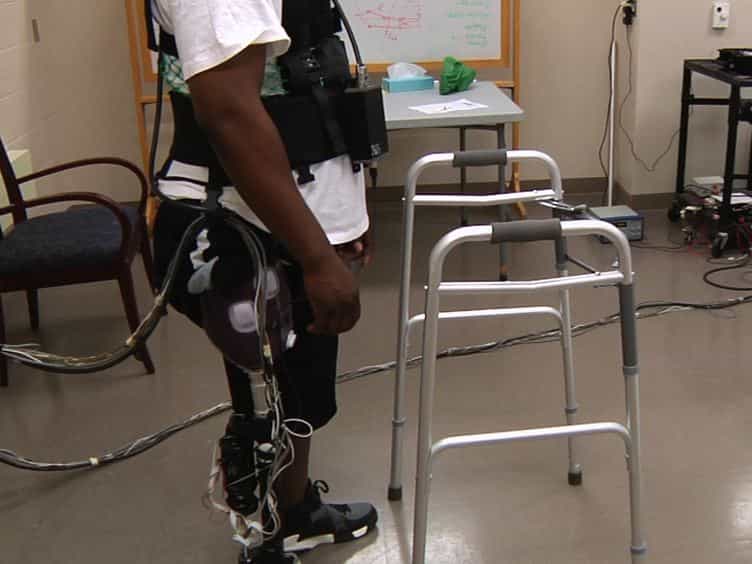
Related Experiment Video
Updated: Jan 9, 2026

Experimental Methods to Study Human Postural Control
Published on: September 11, 2019

Abstract:
Utilizing myoelectric control systems in robotic lower-limb prosthetics is becoming increasingly prevalent, capturing user intent. However, AI-based myoelectric systems often experience high latency and require extensive training data and calibration. Our study introduces a minimalist ridge regression approach for interpreting surface electromyography signals, enabling real-time control of ankle prosthetics. The proof-of-concept system features three open-loop control modes: Position, Velocity, and Torque, which require minimal calibration. Five able-bodied participants participated in a Target Achievement Control test with varying levels of difficulty. Velocity control yielded the highest Completion Rate (CR = 83.3%, p = 0.031 vs Torque) but differences in Overshoot and Movement Time were not statistically significant. Position control achieved solid performance (CR = 71.4 %), whereas direct Torque control suffered from large variability (CR = 40.0 %). The results emphasize the promise of ridge regression for real-time myoelectric control, which could lead to affordable, low-latency prosthetic operation.
More Related Videos
 06:58
A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
