Related Experiment Video
Updated: Jan 9, 2026


Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
S2R-Bench: A Sim-to-Real Evaluation Benchmark for Autonomous Driving
Li Wang1,2, Guangqi Yang3, Lei Yang4
1School of Machanical Engineering, Beijing Institute of Technology, Beijing, 100081, China.

Abstract:
Safety is a long-standing and final pursuit in the development of autonomous driving systems, with many safety challenge arising from perception. How to effectively evaluate the safety and reliability of perception algorithms is becoming an emerging issue. Despite its critical importance, existing perception methods exhibit a limitation in their robustness, primarily due to benchmarks being entirely simulated, which fail to align predicted results with actual outcomes, particularly under extreme weather conditions and sensor anomalies that are prevalent in real-world scenarios. To fill this gap, in this study, we propose a Sim-to-Real Evaluation Benchmark for autonomous driving (S2R-Bench). We collect diverse sensor anomaly data across various road conditions to evaluate the robustness of perception methods comprehensive and realistic manner. This is the first corruption robustness dataset based on real-world scenarios, encompassing various road conditions, weather conditions, lighting intensities, and time periods. By comparing real-world data with simulated data, we demonstrate the reliability the collected data for real-world use and aim to foster research on more robust perception models for autonomous driving.
More Related Videos
 11:12
Driving Simulation in the Clinic: Testing Visual Exploratory Behavior in Daily Life Activities in Patients with Visual Field Defects
Published on: September 18, 2012
 11:41
Evaluation of an Exclusive Spur Dike U-Turn Design with Radar-Collected Data and Simulation
Published on: February 1, 2020
Related Concept Videos
 01:12
Modeling and Similitude
 01:10
Relative Motion Analysis - Acceleration
 01:17
Rolling Resistance: Problem Solving
 01:14
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:30
Average Acceleration
 01:21
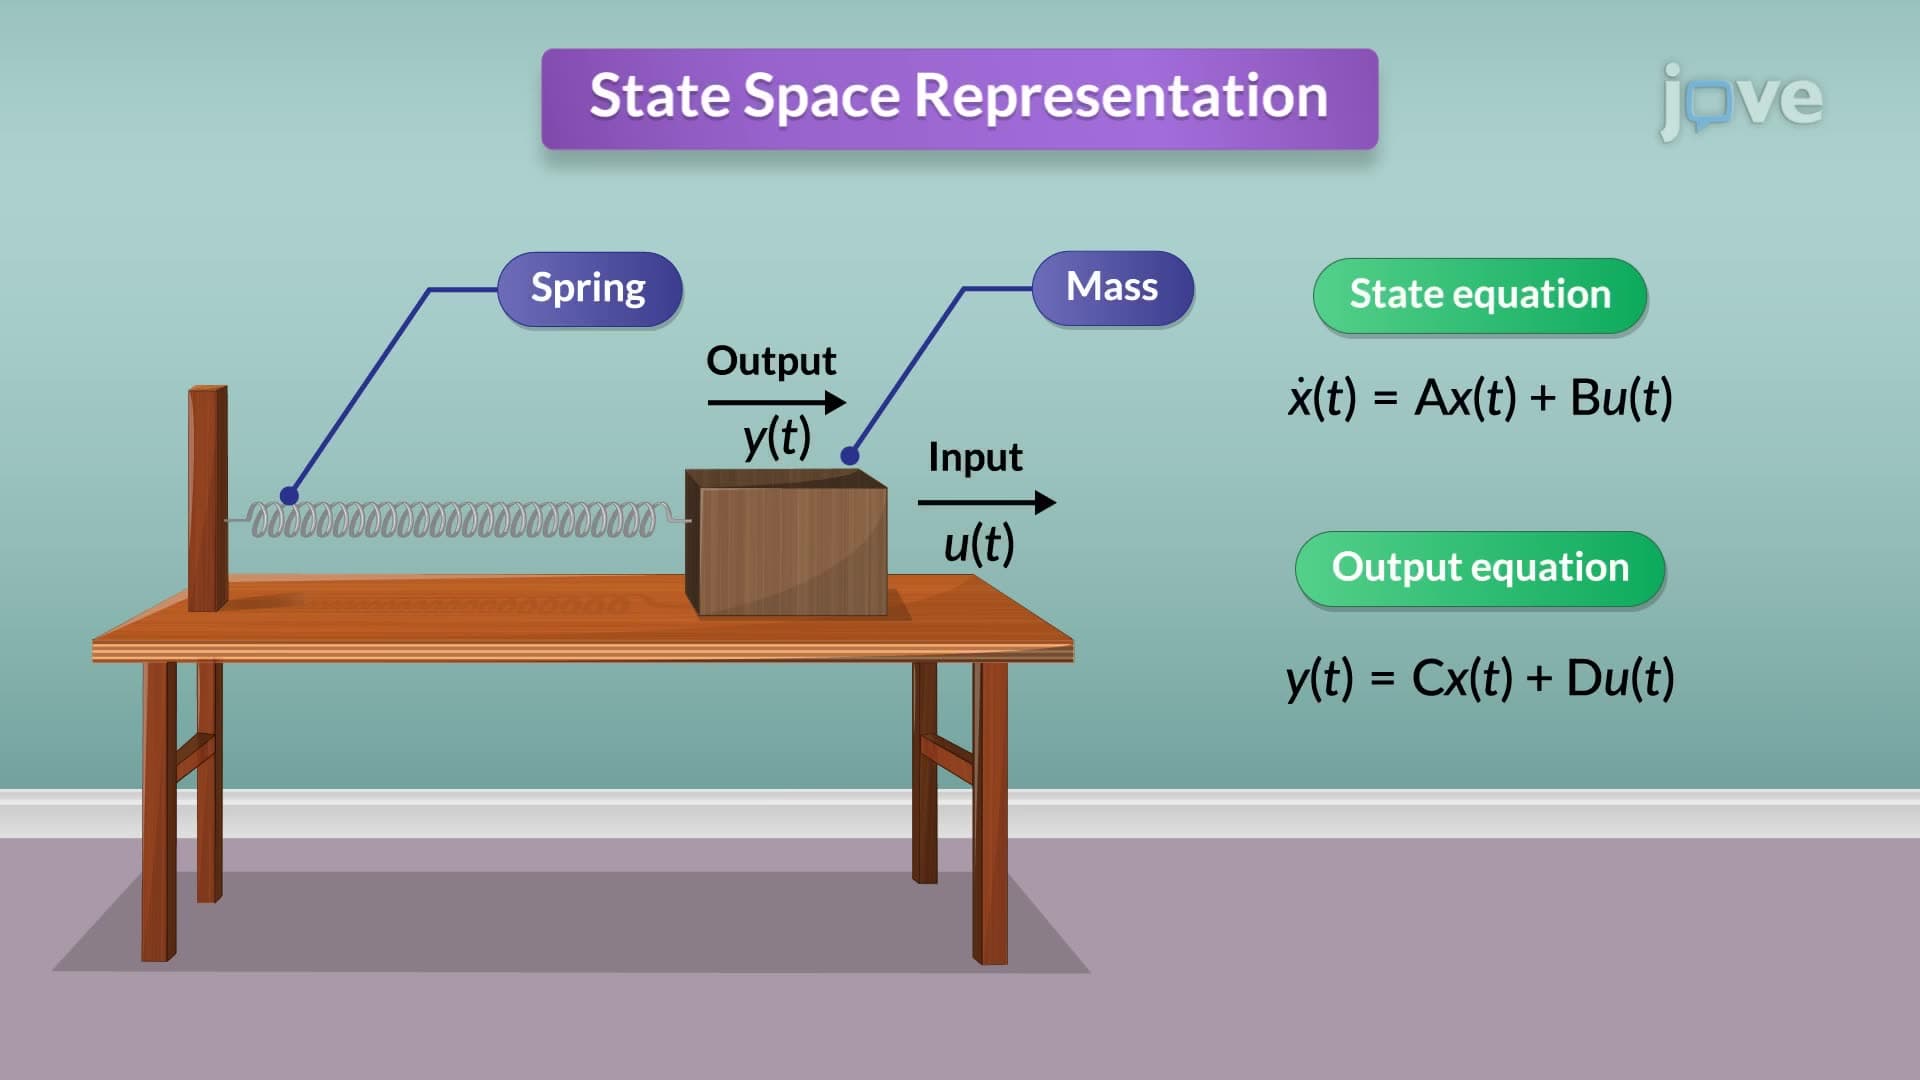
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as: