Related Experiment Video
Updated: Jan 9, 2026


Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
Natural Grasping in Virtual Worlds: Validation of a Haptic Setup for Human Object Manipulation

Abstract:
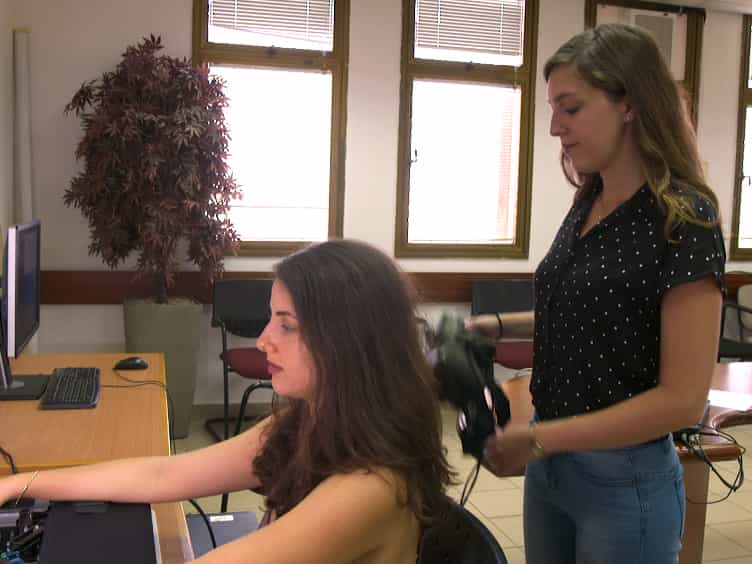
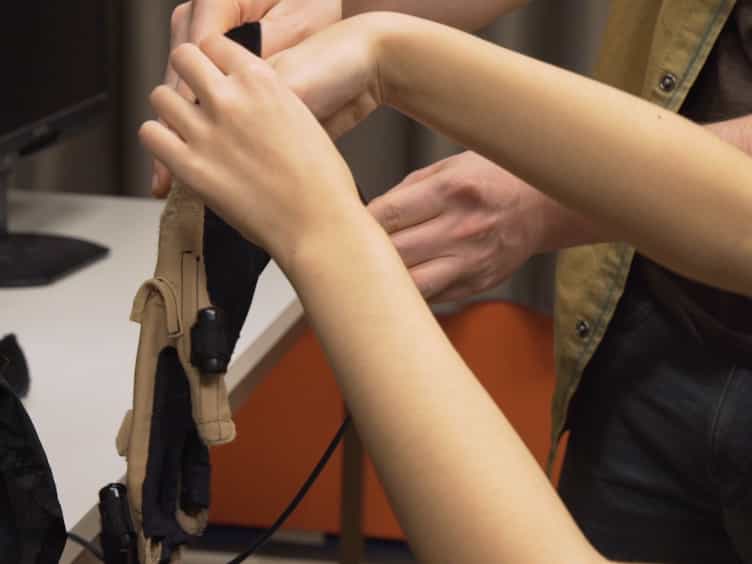
Humans have exceptional object manipulation skills. By combining feedforward and feedback control, the sensorimotor system is able to predictively scale grip and manipulation forces and quickly adapt to environmental changes. Using technologies such as virtual reality, researchers can investigate the underlying mechanisms in ways that are not possible in the physical world. Here, we present our custom-built virtual reality setup, including an open-source software framework, and show its validity in human motor control studies. We replicated two well-established experiments involving physical objects that investigated how humans adapt to different object mass and center of mass. Our results show that the general force and position control strategies employed in the virtual experiment closely mirrored those observed in the real world. Specifically, participants scaled grip forces with object mass and coordinated digit positions and forces according to the object's center of mass and shape. However, the trial-by-trial adaptation rate was slower, and the grip forces were slightly increased in the virtual setup, likely due to increased uncertainty arising from the 2D visual feedback and the lack of cutaneous feedback. Additionally, we tested the effect of visual feedback complexity by comparing a simple and detailed representation of the fingers, finding that participants exhibited similar manipulation strategies across both conditions. Our results validate this setup as a reliable platform for future studies in human motor control.