Related Experiment Video
Updated: Jan 11, 2026
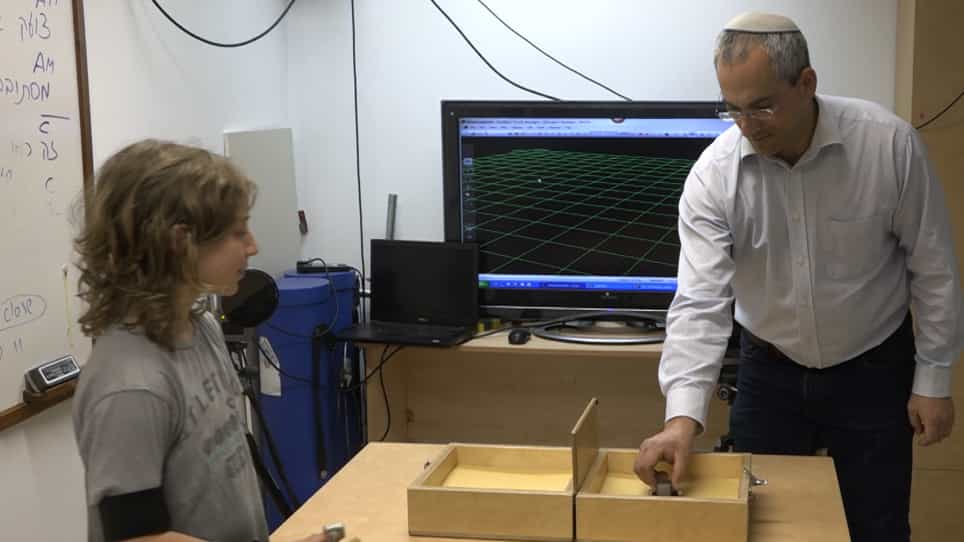

Applying Incongruent Visual-Tactile Stimuli during Object Transfer with Vibro-Tactile Feedback
Published on: May 23, 2019
Partner-sourced haptic feedback rather than environmental inputs drives coordination improvement in human dyadic
Yiming Liu1, Raz Leib2, William Dudley3
1Neuromuscular Diagnostics, TUM School of Medicine and Health, Technical University of Munich, Munich, 80809, Germany. yiming.liu@tum.de.

Abstract:
Haptic communication is a critical communication channel in physical collaboration. However, most studies focus on simplistic tasks with predetermined solutions, restricting the exploration of collaborative behaviors. In this study, we designed a complex task derived from the classic ball-beam control problem, requiring pairs of participants to collaboratively control an unstable object with internal degrees of freedom. The task's redundant nature allowed diverse strategies and collaboration patterns to emerge. We systematically examined the impact of different sources of haptic feedback, distinguishing between forces arising from the collaborator's actions and forces arising from the task dynamics. Participants collaborated across five haptic feedback conditions: full haptics, partner only, environment only, no haptics, or unrelated haptics. Haptic feedback significantly enhanced interpersonal coordination, primarily via partner-sourced rather than environment-sourced haptic feedback. Despite equal access to information and mechanical leverage, participants naturally assumed leader-follower roles, which were robustly quantified across multiple metrics. We showed how leadership dynamics evolved throughout the experiment and varied across different haptic conditions. This study advances the understanding of haptic communication, highlighting the value of partner haptics in developing more effective and adaptive strategies for both human-human and human-robot collaboration.
Related Concept Videos
 01:24
Facial Feedback Hypothesis
 02:12
Relationship Formation