A novel scheme for speed variation of a robotic cane to improve step length symmetry during overground walking
Related Experiment Video
Updated: Jan 8, 2026
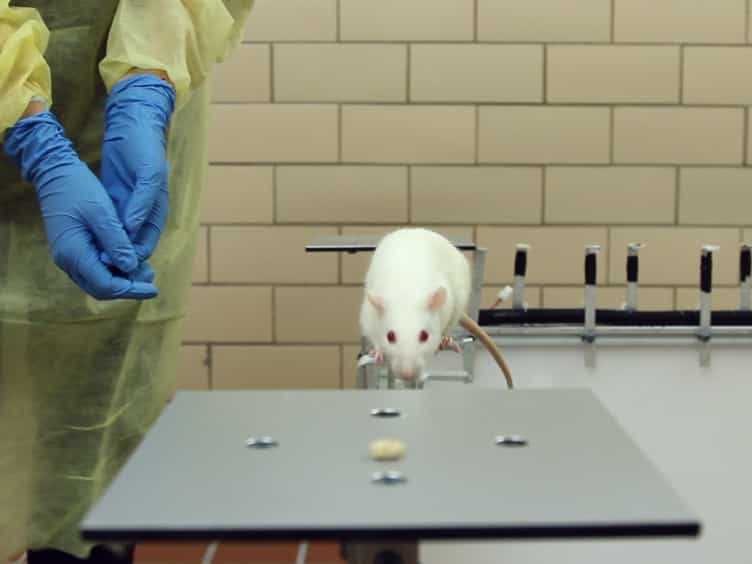
Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion
Published on: January 15, 2016
Hosu Lee1, Junyeong Lee2, Hyunggi Park3
1Department of Control and Robot Engineering, Gyeongsang National University (GNU), Defence Institute of Science and Technology (GADIST)), Jinju, 52828, Republic of Korea.

Abstract:
Gait symmetry is a vital index for improving and evaluating the walking ability of patients with hemiplegia. Asymmetric gait disturbs walking balance and increases unnecessary energy consumption, causing serious damage to the musculoskeletal system. The restoration of step length symmetry (SLS) is one of the gait parameters targeted for rehabilitation and can be easily accessed and adjusted in the clinic. Therefore, we proposed a novel scheme based on a speed variation method (SVM) using a robotic haptic cane (HC) to improve SLS on overground walking. To evaluate the proposed method and check protocols for a patient study, we conducted an experiment to lengthen the left step length of 24 healthy young participants using positive (P), negative (N), and positive & negative (PN) SVM. Additionally, we examined its feasibility in one stroke patient. As a result of the healthy subjects’ experiment, walking speed and SLS ratio significantly increased with P and PN SVM while maintaining Root Mean Square (RMS) of pelvic tilt (p < .001). Results from the patient pilot test were similar to those of the healthy subjects, with decreased RMS of pelvic tilt. SLS ratio improved from -0.13 ± 0.00 (Normal Walking) to -0.07±0.01 (P SVM) and -0.04±0.01 (PN SVM). However, swing phase symmetry also improved. Furthermore, the patient was sensitive to the baseline HC speed and Negative SVM. The results indicate that the proposed methods may be effective in stroke patients and the relationship between walking speed and the ratio of PN SVM should be verified in a larger number of patients.