Related Experiment Video
Updated: Jan 8, 2026
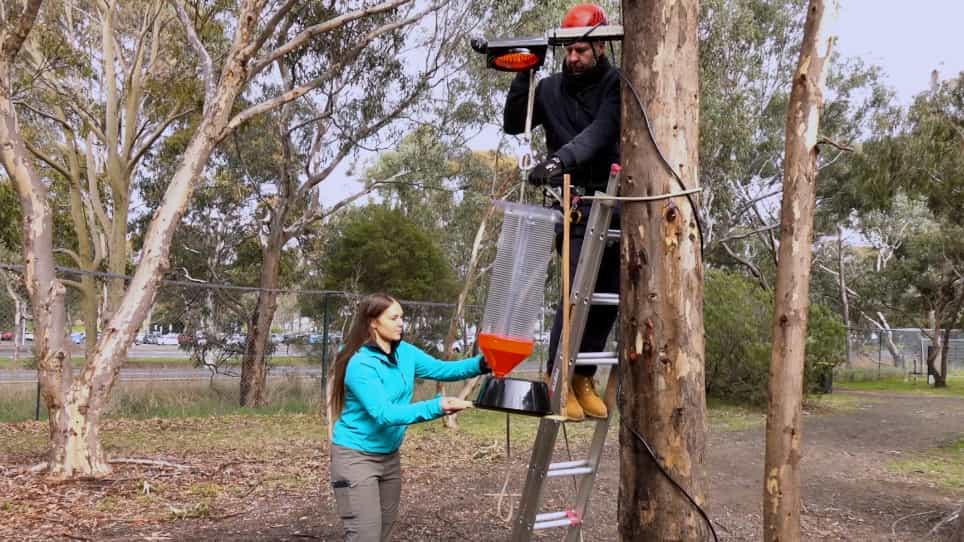
Low-Cost Automated Flight Intercept Trap for the Temporal Sub-Sampling of Flying Insects Attracted to Artificial Light at Night
Published on: December 29, 2021
Boundary-locked event-triggered mechanism-based adaptive flocking control for multi-USV systems
1College of Intelligent Systems Science and Engineering, Harbin Engineering University, Harbin, 150001, China.

Abstract:
Unmanned surface vehicle swarms (USVS), comprising multiple unmanned surface vehicles (USVs), serve as critical platforms for a wide range of demanding marine operations. However, coordinating USVS poses challenges relating to flock cohesion and communication, as well as the adverse effects of uncertainty. Within this context, this paper introduces an event-based adaptive flocking control law for USVS to address these issues. Firstly, an integrated dual-mode potential function, combining a novel artificial potential function (APF) and a directionally consistent potential function (DCPF), is designed to enhance flocking cohesion while guaranteeing connectivity. Then, a boundary-locked event-triggered (BLET) mechanism effectively reduces the communication load with computable minimum inter-event time (MIET) and maximum triggering interval time (MTIT). Finally, a reinforcement learning-based echo state network (RLESN) is incorporated to compensate for unmodeled dynamics and external disturbances, thereby significantly improving the system's robustness. Simulation results and comparative analyses validate the effectiveness and advantages of the proposed methodology.

Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:19
PID Controller