Related Experiment Video
Updated: Jan 7, 2026


Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
Collaborative Control for a Robot Manipulator via Interaction-Force-Based Impedance Method and Extremum Seeking
1School of Information and Control Engineering, Southwest University of Science and Technology, Mianyang 621010, China.

Abstract:
This paper introduces an adaptive impedance control strategy for robotic manipulators, developed through the extremum seeking technique. A model-based disturbance observer (DOB) is employed to estimate contact forces, removing the dependency on torque sensors. An impedance vector is constructed to correct the errors arising from motor uncertainties and unknown couplings, without considering the threshold value of the control parameters. Joint tracking errors and fluctuations in contact force are incorporated into the cost function. For various tasks, suitable control parameters are adaptively optimized in real time using an extremum seeking approach, which continuously evaluates the cost function. A rigorous analysis is conducted on the stability of the proposed controller. Compared to conventional approaches, the proposed adaptive impedance control offers a more streamlined design for adjusting the manipulator's contact impedance. Experimental results confirm that the extremum seeking strategy successfully tuned the controller parameters online according to variations in the cost function.


Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:23
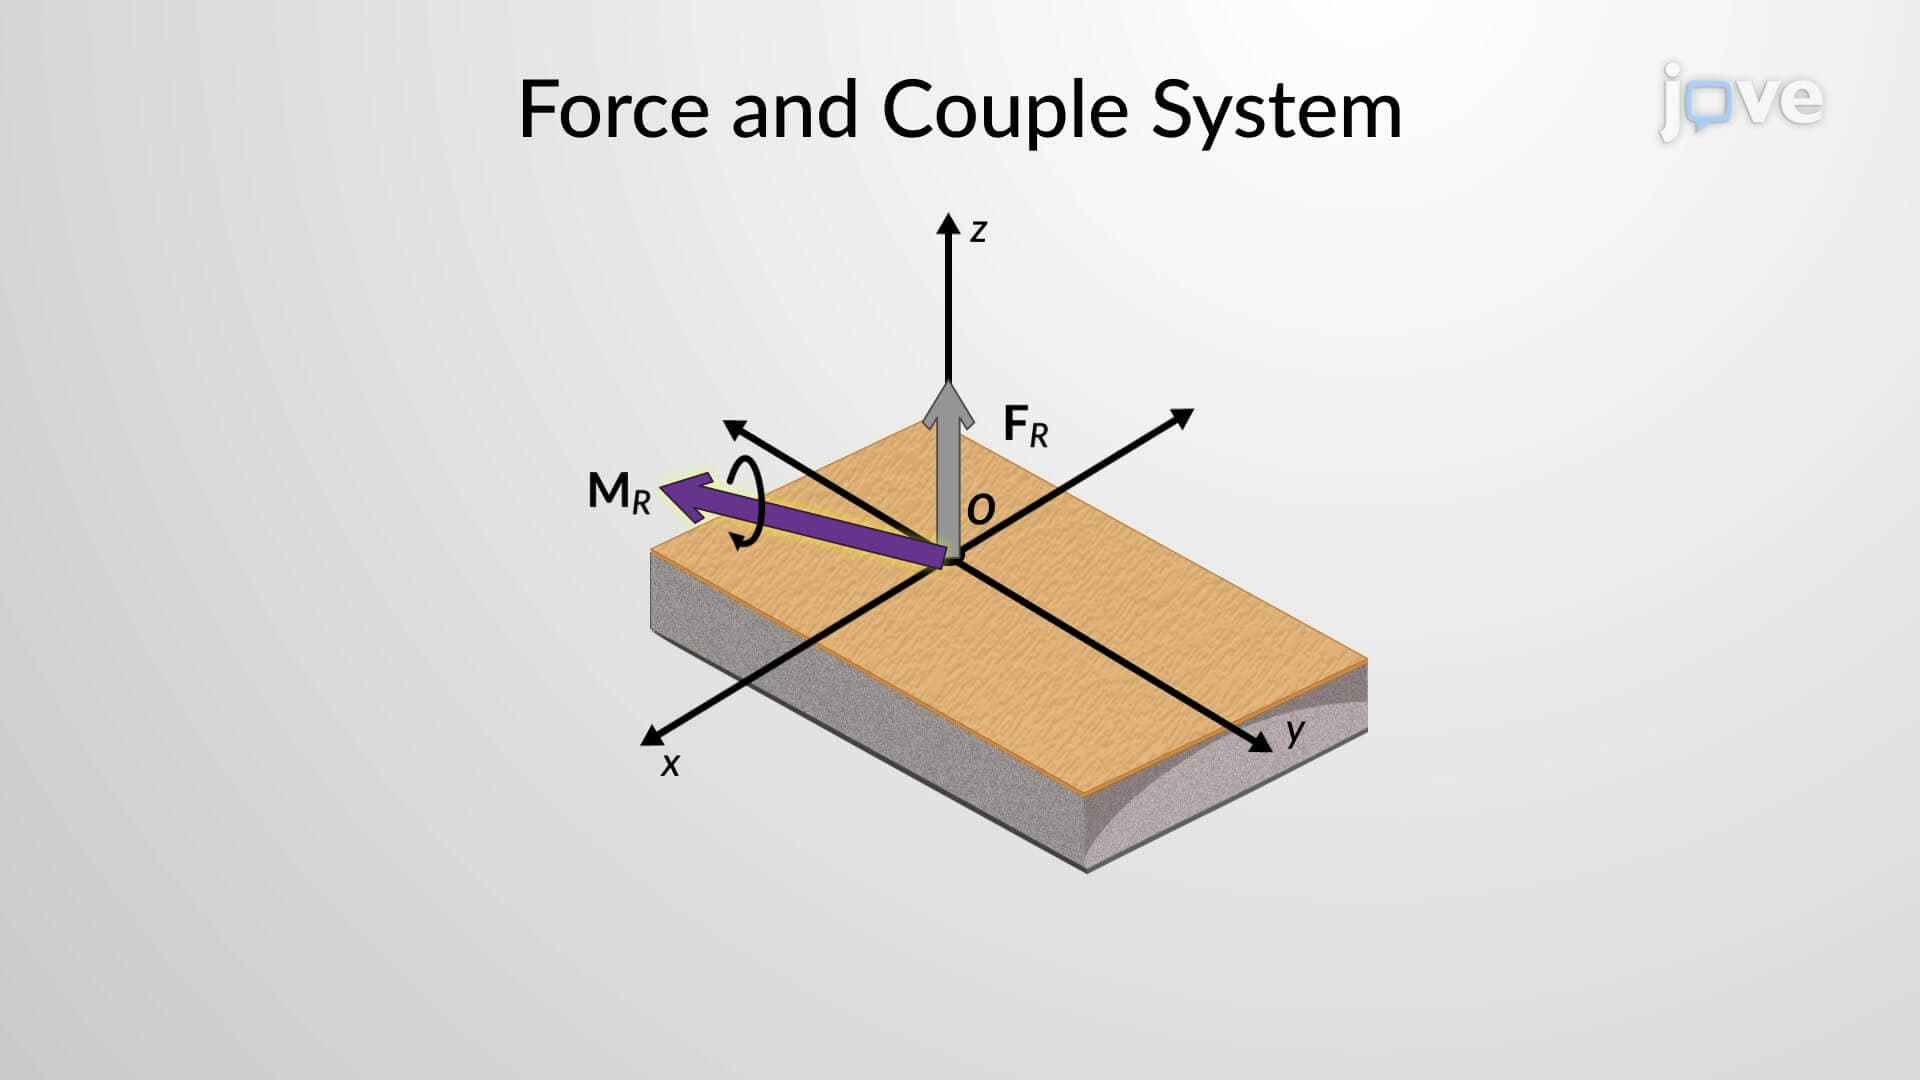
Simplification of a Force and Couple System: II
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...