Related Experiment Video
Updated: Jan 7, 2026


Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
Continuous sliding mode disturbance rejection control for flexible joint robots with input saturation
Xiaoduo Zhang1, Huiming Wang1, Junxiao Wang2
1Chongqing Key Laboratory of Complex Systems and Autonomous Control, and Key Laboratory of Big Data Intelligent Computing, Chongqing University of Posts and Telecommunications, Chongqing, China.

Abstract:
In this paper, a robust disturbance rejection control scheme is proposed for the trajectory tracking of flexible joint robots (FJRs) affected by multi-source disturbances and input saturation. The unknown time-varying disturbances, which are categorized into matched and mismatched, generally encompass uncertainties in internal parameters, coupling effects, unmodeled dynamics, and changing external environments. To address these disturbances, the mismatched disturbances are transformed into matched disturbances through the flatness method, eliminating the computational cost of estimating mismatched disturbances. Meanwhile, a generalized proportional integral observer (GPIO) is adopted to estimate the unmeasurable states and disturbances. In addition, to deal with input saturation, an anti-windup compensation auxiliary system is constructed. Finally, an output feedback control framework based on continuous sliding mode control (CSMC) is further designed. The proposed control approach facilitates asymptotic convergence of the tracking error and mitigates the chattering effect inherent in traditional sliding mode control (SMC), thereby enhancing both control and dynamic performance while satisfying input constraints. A detailed stability analysis of the closed-loop system is also presented. The feasibility and effectiveness of this approach are validated through comparison with a traditional disturbance rejection control scheme.
More Related Videos


Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:05
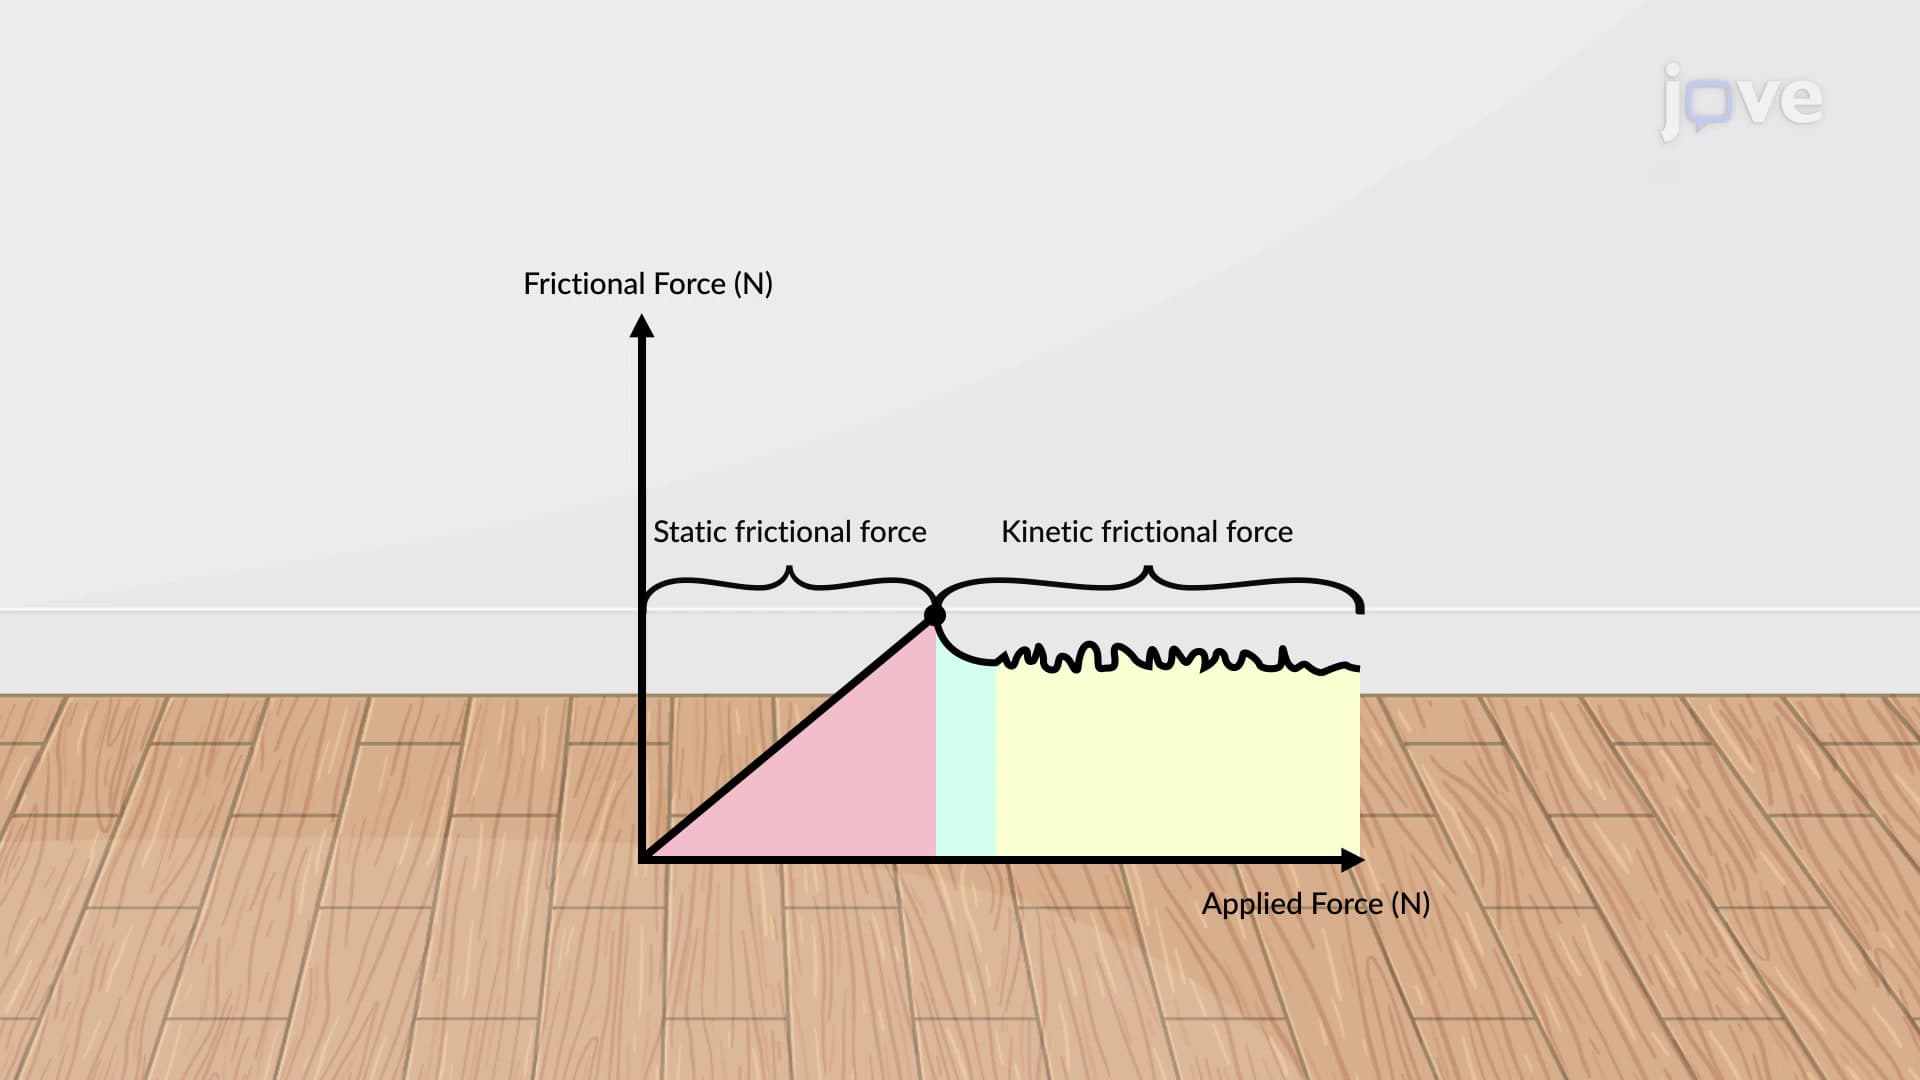
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...