Related Experiment Video
Updated: Jan 13, 2026


Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Do you trust what an automated vehicle shows you? The effects of presenting dynamic system certainty information on
Micah Wilson George1, Zachary Hass2, Brandon J Pitts1
1Edwardson School of Industrial Engineering, Purdue University, West Lafayette, IN, USA.

Abstract:
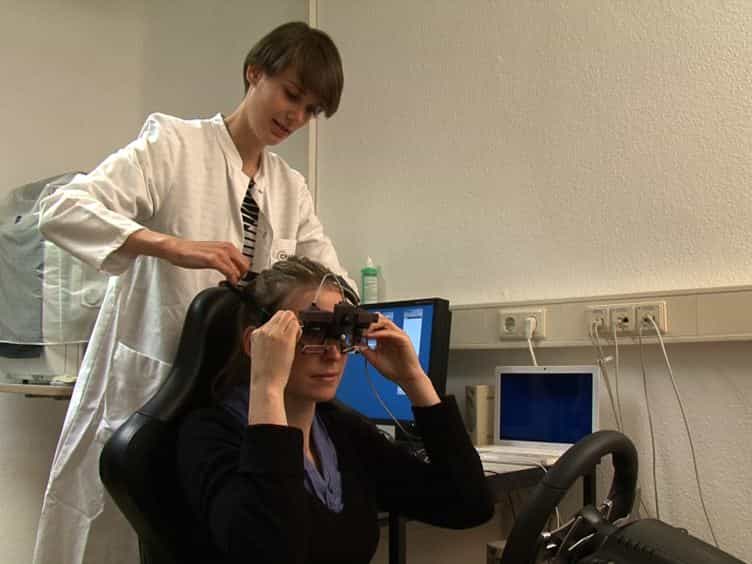
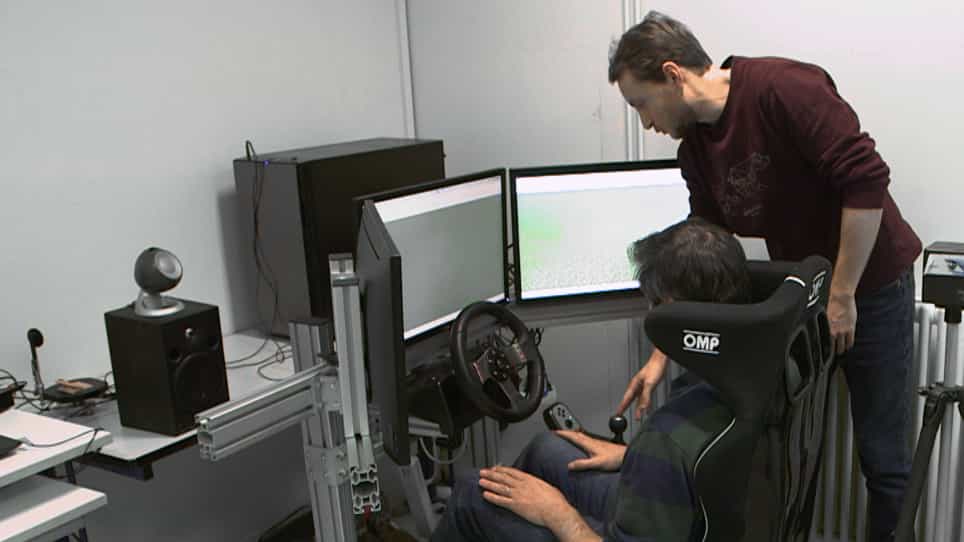
As automated vehicle (AV) systems become increasingly more intelligent and self-aware of their capabilities, understanding drivers' interactions with AVs is paramount for successful integration of these vehicles into the broader transportation landscape. One area that needs more attention is understanding the effects of displaying AV self-assessed system certainty - regarding its navigability around roadway obstacles - on drivers' trust, decision-making, and behavioral responses. To contribute to the existing body of work, the current study evaluated a set of dynamic and continuous human-machine interfaces (HMIs) that present 2-dimensional AV system certainty information to drivers. A simulated driving study was conducted wherein participants were exposed to four different linear and curvilinear system certainty patterns (Linear Up, Linear Down, Convex, and Concave) on an HMI that represented an AV's confidence in its ability to safely avoid a construction zone ahead in its lane. Using this information, drivers decided whether or not (and when) to take over from the vehicle. The AV's true reliability and system certainty were not directly proportional to one-another. Trust, workload, takeover decisions and performance, eye movement behavior, and heart rate measures were captured during the study to understand drivers' responses to the vehicle certainty information. Overall, system certainty information had a significant effect on drivers' takeover response times and eye gaze behavior but did not affect their trust nor workload. In 24 % of all cases, participants either voluntarily took control of the AV when it was reliable or did not take over when the AV was unreliable. Trust was higher for participants who did not take over. The results of this work can be used to inform the design of in-vehicle interfaces in future autonomous vehicles, aiming to enhance decision-making and safety during driving.
More Related Videos
Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:10
Control Systems
At the heart...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:10
Propagation of Uncertainty from Systematic Error