Related Experiment Video
Updated: Jan 28, 2026
A Pipeline for 3D Multimodality Image Integration and Computer-assisted Planning in Epilepsy Surgery
Published on: May 20, 2016
An Improved Red-Billed Blue Magpie Optimization Algorithm for 3D UAV Path Planning in Complex Terrain
Yong Xu1, Ning Xue1, Yi Zhang1
1College of Electrical and Computer Science, Jilin Jianzhu University, Changchun 130119, China.

Abstract:
This paper presents the Circle-Mapping Transition and Weighted Red-Billed Blue Magpie Optimizer (CTWRBMO), designed to address significant challenges in 3D path planning for drones. Although the original Red-Billed Blue Magpie Optimizer (RBMO) algorithm features a simple structure, few parameters, and strong local search capability, making it well-suited for UAV path optimization, it suffers from insufficient population diversity, limited global search ability, and a tendency to fall into local optima in complex high-dimensional scenarios. To overcome these limitations, four enhancement strategies are introduced. Firstly, the Circle chaotic mapping strategy leverages the randomness and ergodicity of chaotic sequences to generate an initial population that is uniformly distributed. This enhancement improves population diversity from the beginning and provides a solid foundation for global optimization. Secondly, the ε parameter is dynamically adjusted to prioritize local refinement during the early stages of optimization. This adjustment enables rapid convergence toward potentially optimal areas. This parameter increases to enhance global search capabilities as the algorithm progresses, thereby broadening the optimization space and achieving a dynamic equilibrium. Additionally, a nonlinear dynamic weighting factor (wd) is incorporated into the position update formula. The algorithm's ability to escape local optima is significantly improved by dynamically altering the weight ratio between historical optimal positions and the current position. Furthermore, an elite perturbation mechanism based on individual neighborhoods is implemented to generate candidate solutions using local information. This mechanism enhances the algorithm's local exploration capabilities and improves the stability of preserving optimal solutions, supported by a greedy criterion for optimal retention. Experimental results show that the CTWRBMO algorithm significantly outperforms comparison algorithms in terms of optimization accuracy and convergence speed, demonstrating exceptional global optimization capabilities. Additional applications in UAV 3D path planning simulations evaluated paths based on length, threat avoidance efficiency, and smoothness. The results indicate that paths planned using CTWRBMO are shorter, safer, and smoother compared to those generated by the Harrier Hawks Optimization (HHO), African Vulture Optimization Algorithm (AVOA), Artificial Bee Colony (ABC) Algorithm, and the traditional Magpie Algorithm, effectively meeting practical engineering requirements for UAV 3D path planning.
Related Concept Videos
 01:21
Path Between Thermodynamics States
 01:22
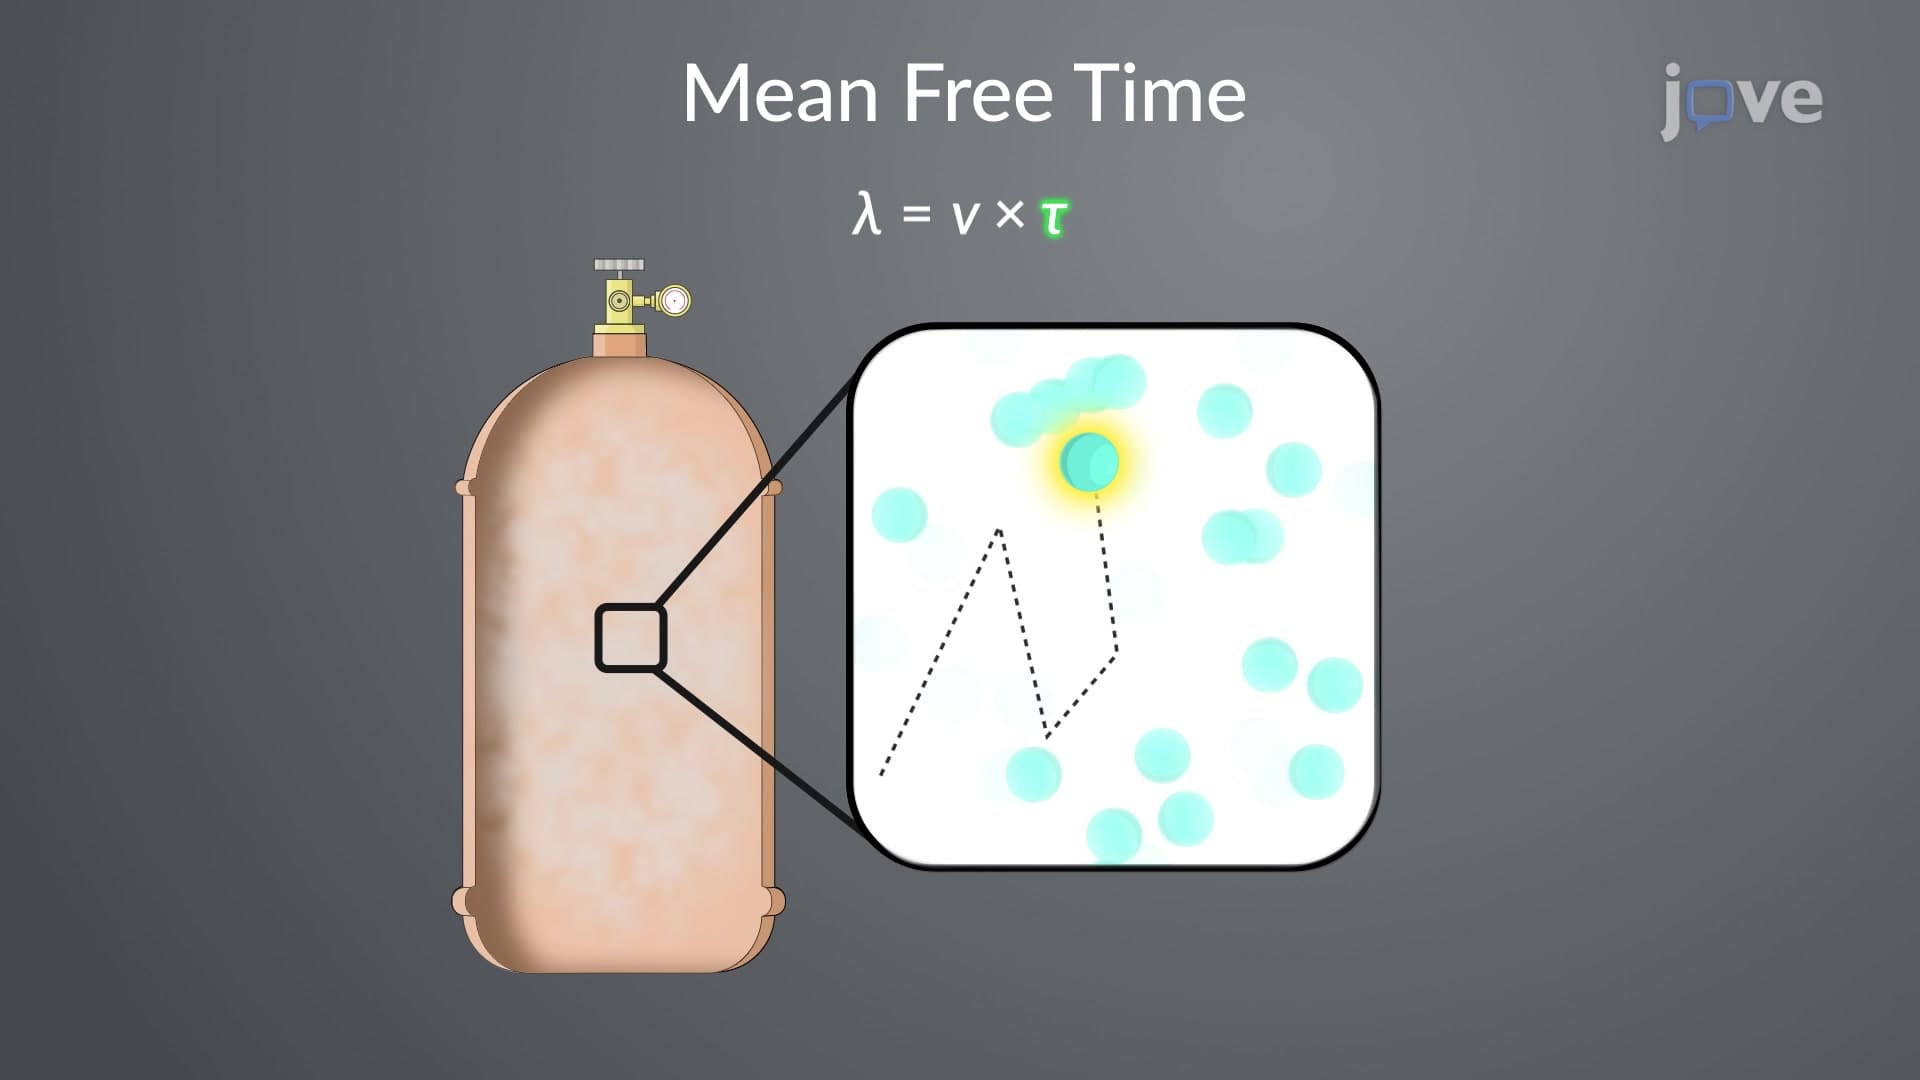
Mean free path and Mean free time
 01:10
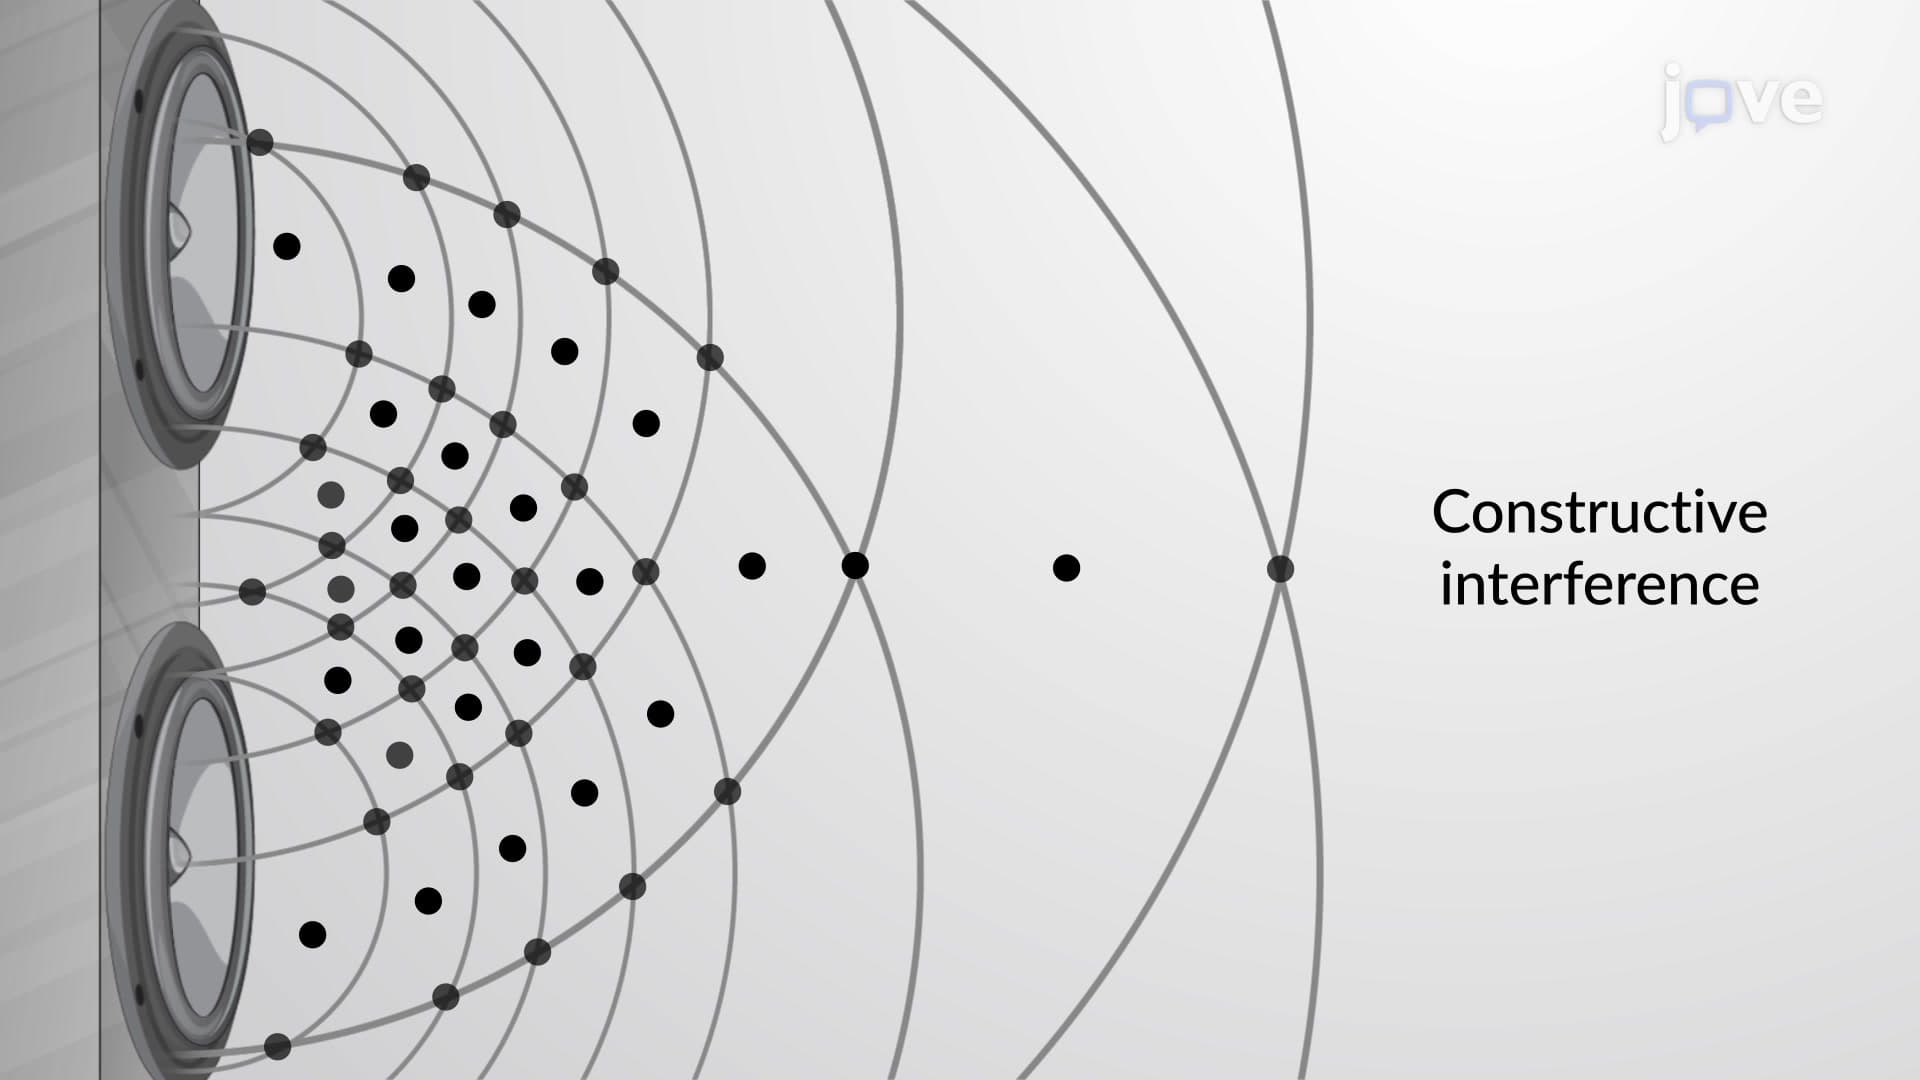
Interference: Path Lengths
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...
 03:48
Behavior of Gas Molecules: Molecular Diffusion, Mean Free Path, and Effusion
 01:12
Trial and Error and Algorithm
 01:23
Sampling Plans
Random sampling is a method where each member of the population has an equal chance of being selected for the sample. It involves selecting individuals randomly, often using random number generators or lottery-type methods. For example, when analyzing the properties of a...