Related Experiment Video
Updated: Feb 5, 2026

Machine Learning Algorithms for Early Detection of Bone Metastases in an Experimental Rat Model
Published on: August 16, 2020
Path planning for UAVs in complex terrain based on the PGD model: Algorithmic improvements combining feature
Liangshuai Liu1, Xiaofeng Li1, Lingming Meng1
1State Grid Hebei Electric Power Research Institute, Shijiazhuang, Hebei, China.

Abstract:
This paper proposes the PGD model for UAV path planning in complex terrain, addressing key challenges such as high-dimensional state processing, blind path exploration, and poor cross-scene adaptability. The PGD model integrates Transformer, GAN, and DDPG, forming a "compression-generation-optimization" closed-loop system. The Transformer module compresses high-dimensional terrain data, alleviating training bottlenecks, while the GAN module generates high-quality candidate paths, reducing ineffective exploration. DDPG then optimizes the path planning strategy efficiently. Experimental results demonstrate the superior performance of PGD on the UAVDT (suburban) and AirSim (canyon) datasets. In terms of path length (Pl), PGD achieves 20.0m/22.0m, compared to baseline models such as PPO-DRL (23.8m) and Soft Actor-Critic (24.0m). PGD also outperforms in collision rate (Cr) with 2.5%/3.0% and computational efficiency (Tc) with 13.5s/16.0s, respectively. The PGD model shows significant improvements in path planning efficiency and adaptability, particularly in high-complexity terrains. Compared to traditional models, PGD's multi-module synergy enhances feature correlation and physical path constraints, offering a novel framework for intelligent planning in complex environments. Future work will focus on enhancing model adaptability to extreme weather and multi-agent collaborative scenarios.
Related Concept Videos
 01:22
Mean free path and Mean free time
 01:21
Path Between Thermodynamics States
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:23
Reinforcement
Positive reinforcement occurs when a behavior is followed by the presentation of a rewarding stimulus, increasing the frequency of that behavior. For example:
 01:10
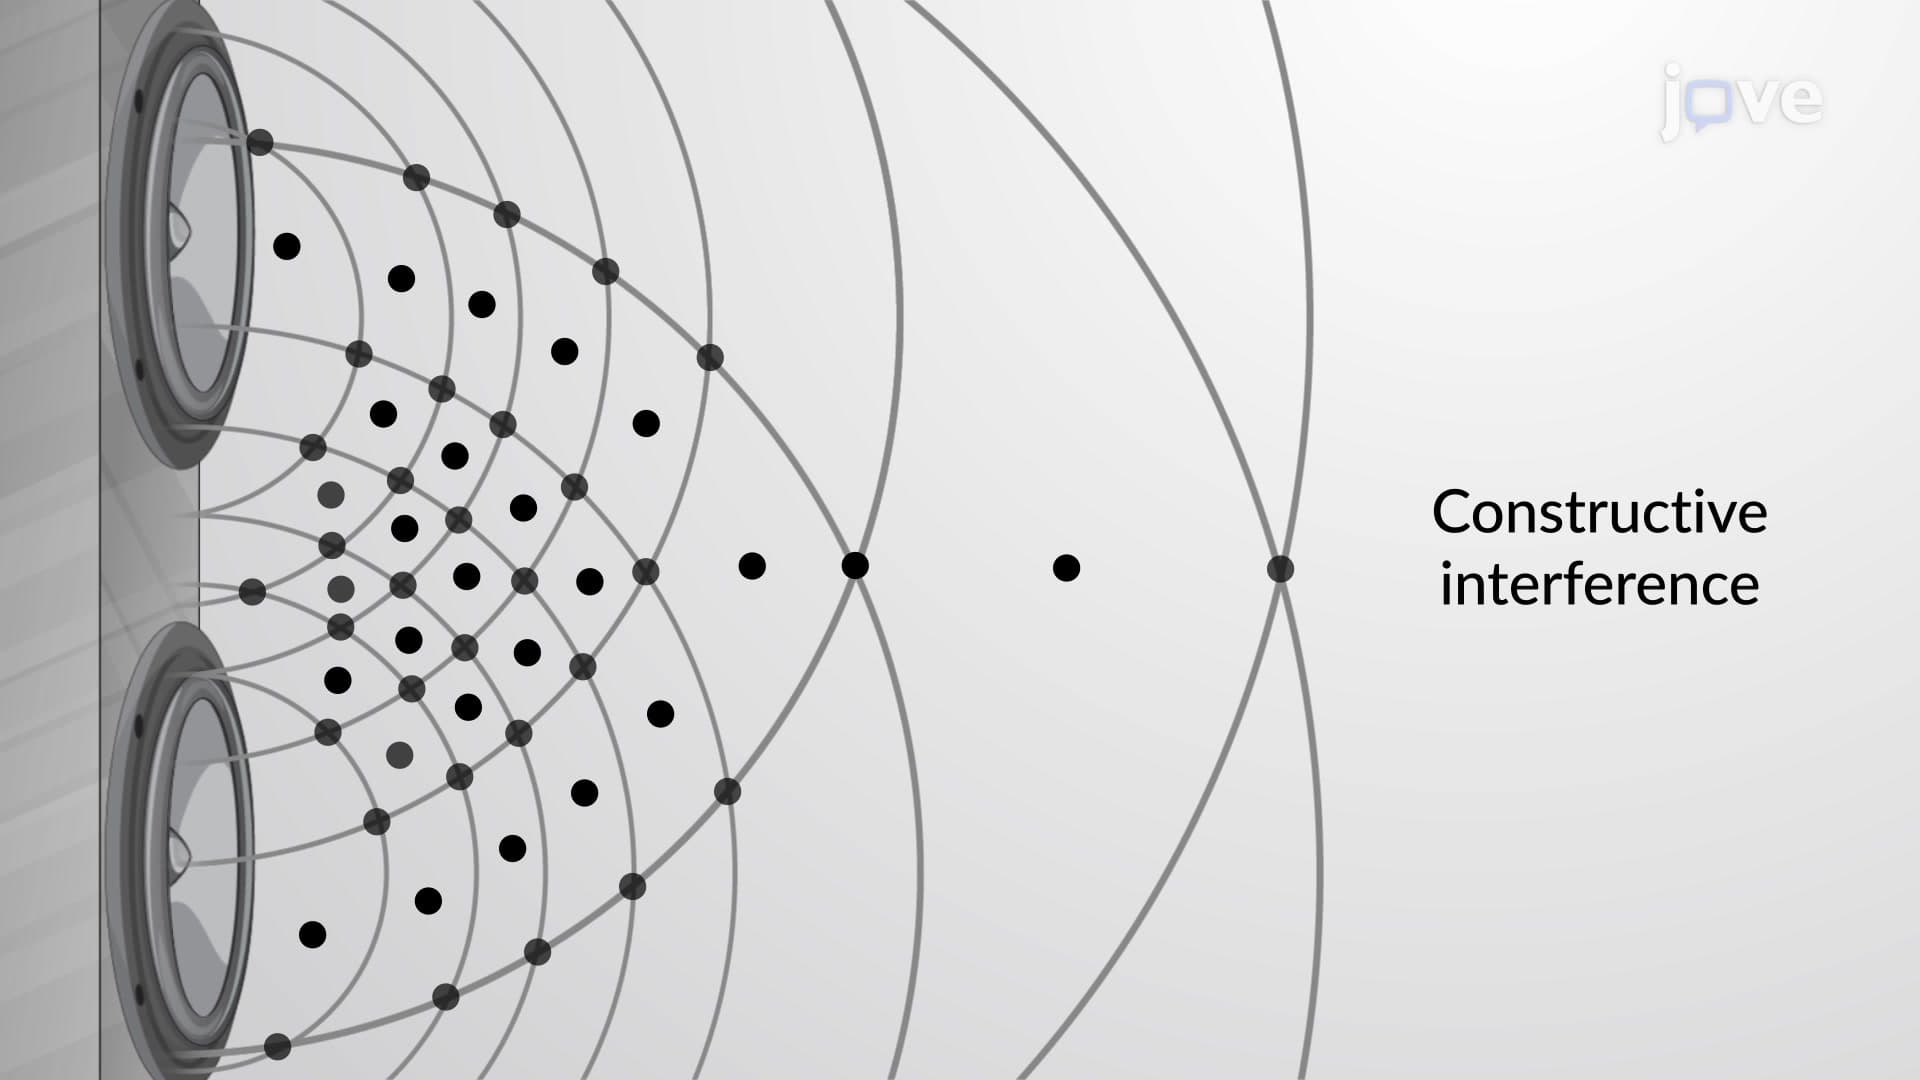
Interference: Path Lengths
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...
 01:27
Corrosion of Reinforcement
However, over time and under certain conditions like carbonation, chloride ingress, and cracking this protective state can be compromised. Steel has areas with...