Related Experiment Video
Updated: Feb 14, 2026


Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
A Bioinspired Gear-Rolling Knee Exoskeleton for Enhanced Human-Exoskeleton Kinematic Compatibility

Objective:
This paper aims to reduce human-exoskeleton knee joint misalignment arising from the nonuniform and subject-specific motion of the tibiofemoral joint, thereby improving kinematic compatibility between the user and the exoskeleton.
Methods:
A bioinspired gear-based knee exoskeleton is proposed, featuring a planetary gear mechanism that approximates the physiological rolling behavior of the human knee and a three-stage gear compensatory transmission that accommodates residual sliding-induced mismatch. A virtual human-exoskeleton interaction model based on sliding misalignment metric was developed to quantify kinematic misalignment and guide gear-parameter optimization. The proposed design was evaluated through numerical simulations, prototype implementation, human-subject experiments, and bench tests to characterize kinematic consistency and drive performance.
Results:
Relative to a single-axis knee joint, the proposed mechanism reduced knee joint misalignment by approximately 70%. Torque transmission tests conducted on a mechanically decoupled platform showed close agreement between commanded and measured output torques, with peak deviations of approximately 8%-15% during extension and 5%-13% during flexion. Back-drivability characterization further indicated low passive resistance, with back-driving torque accounting for less than 5% of the rated assistive torque.
Conclusion:
The proposed gear-based knee joint enables anatomical motion approximation and internal misalignment accommodation while maintaining reliable torque transmission within a deterministic kinematic structure.
Significance:
This work provides a generalizable mechanical and modeling framework for addressing knee joint misalignment in wearable exoskeletons and supports the development of systems with improved human-robot kinematic compatibility.
More Related Videos
 06:44
Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
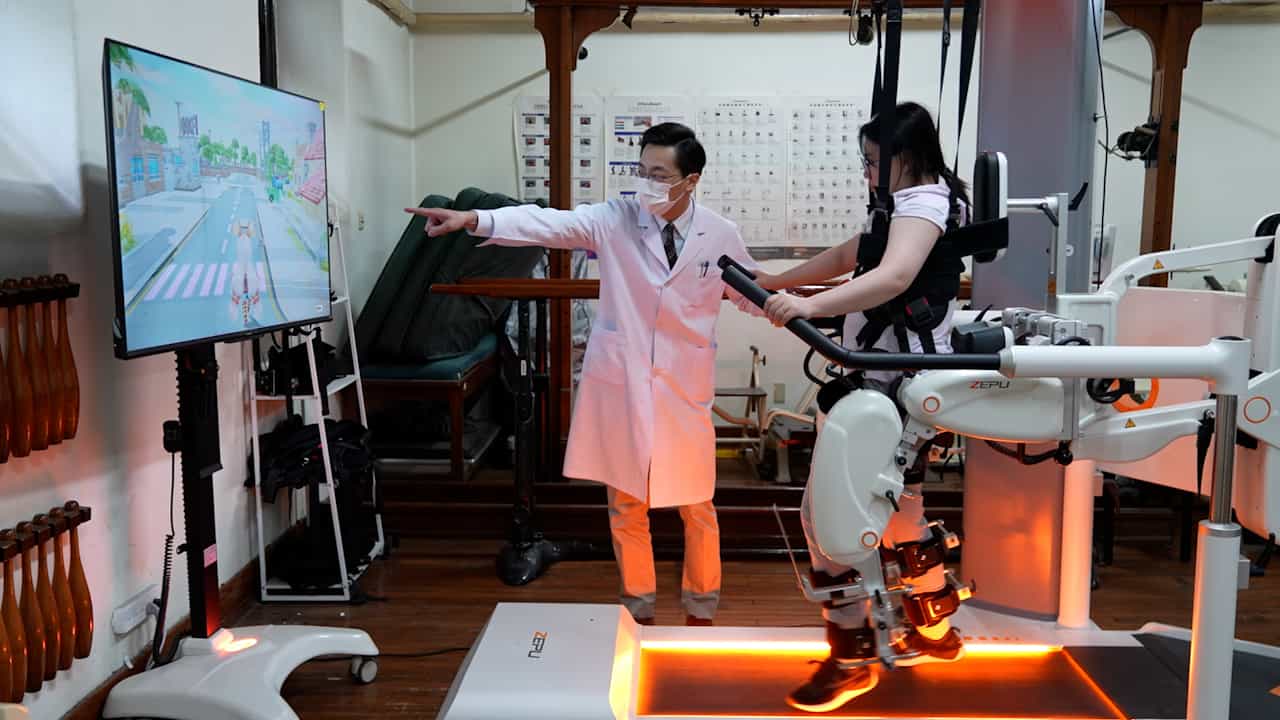 06:00
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025
Related Concept Videos
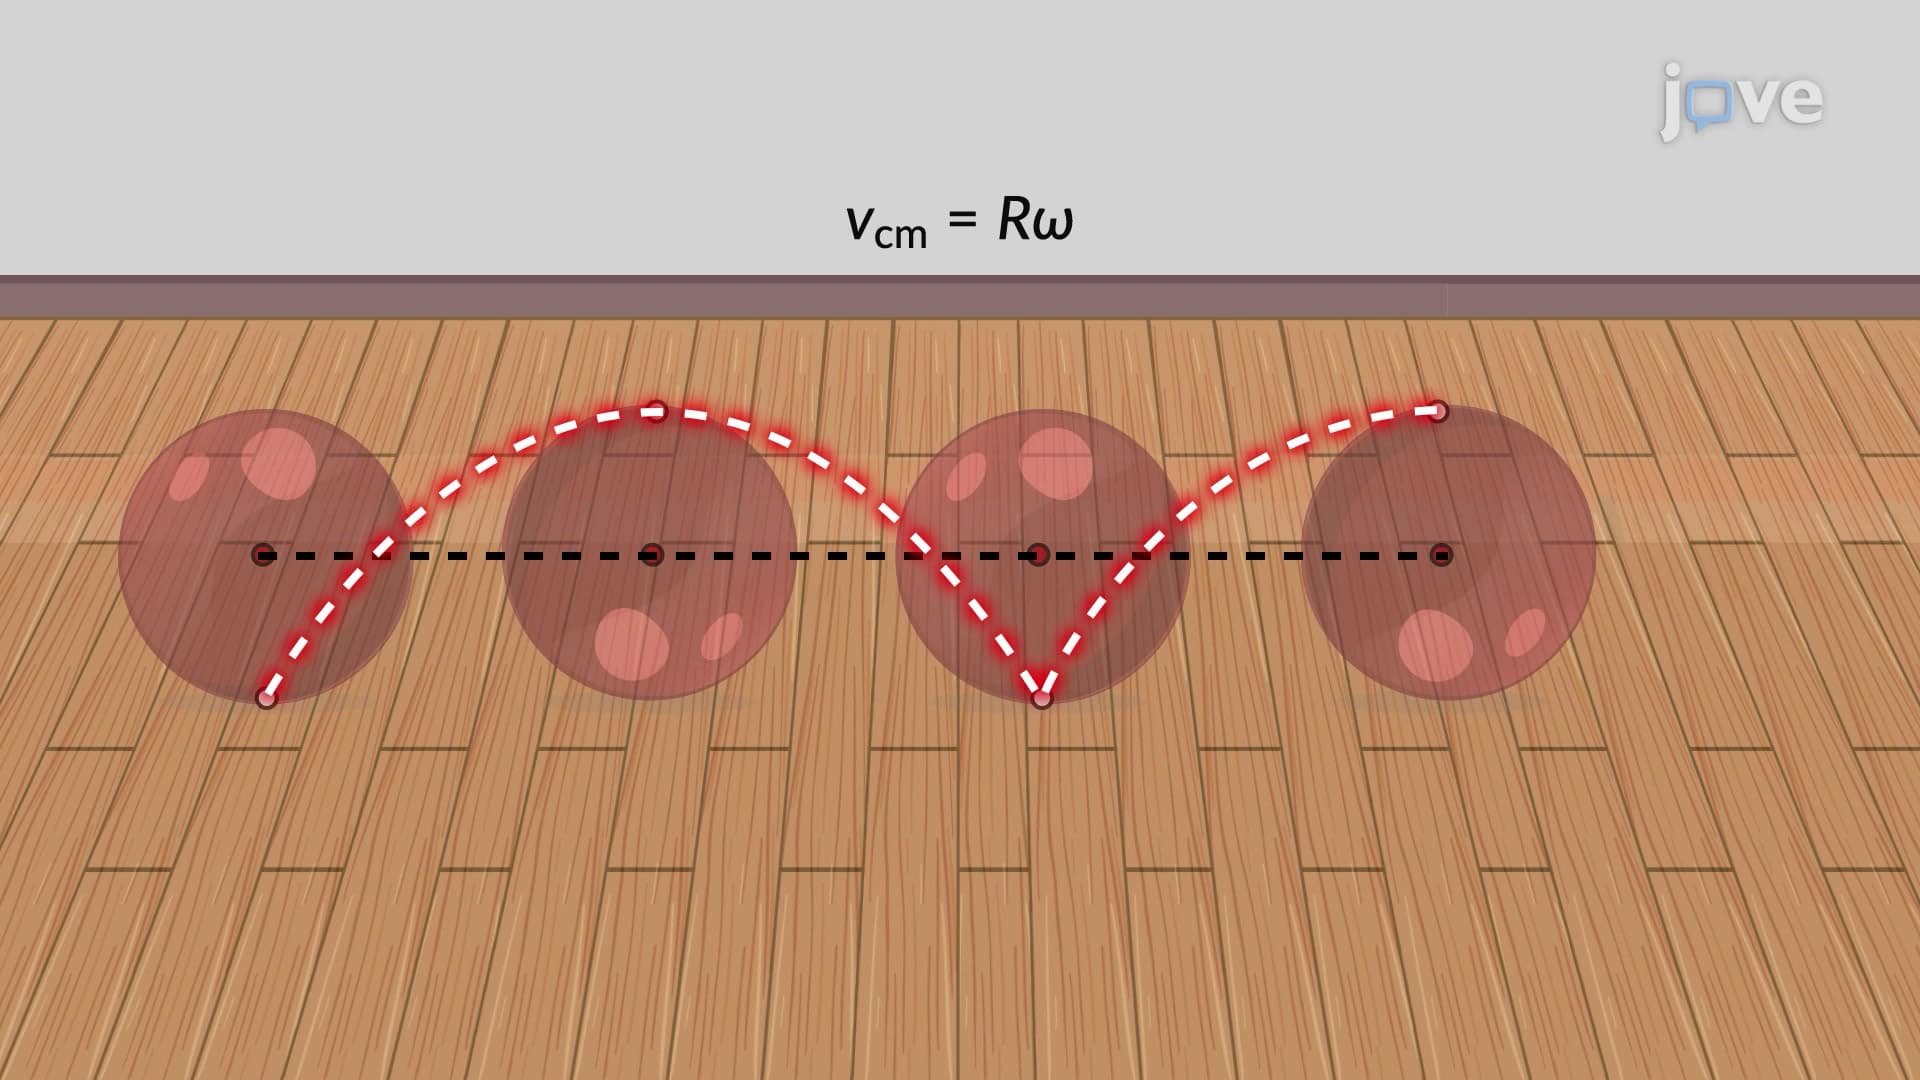 01:09
Rolling Without Slipping
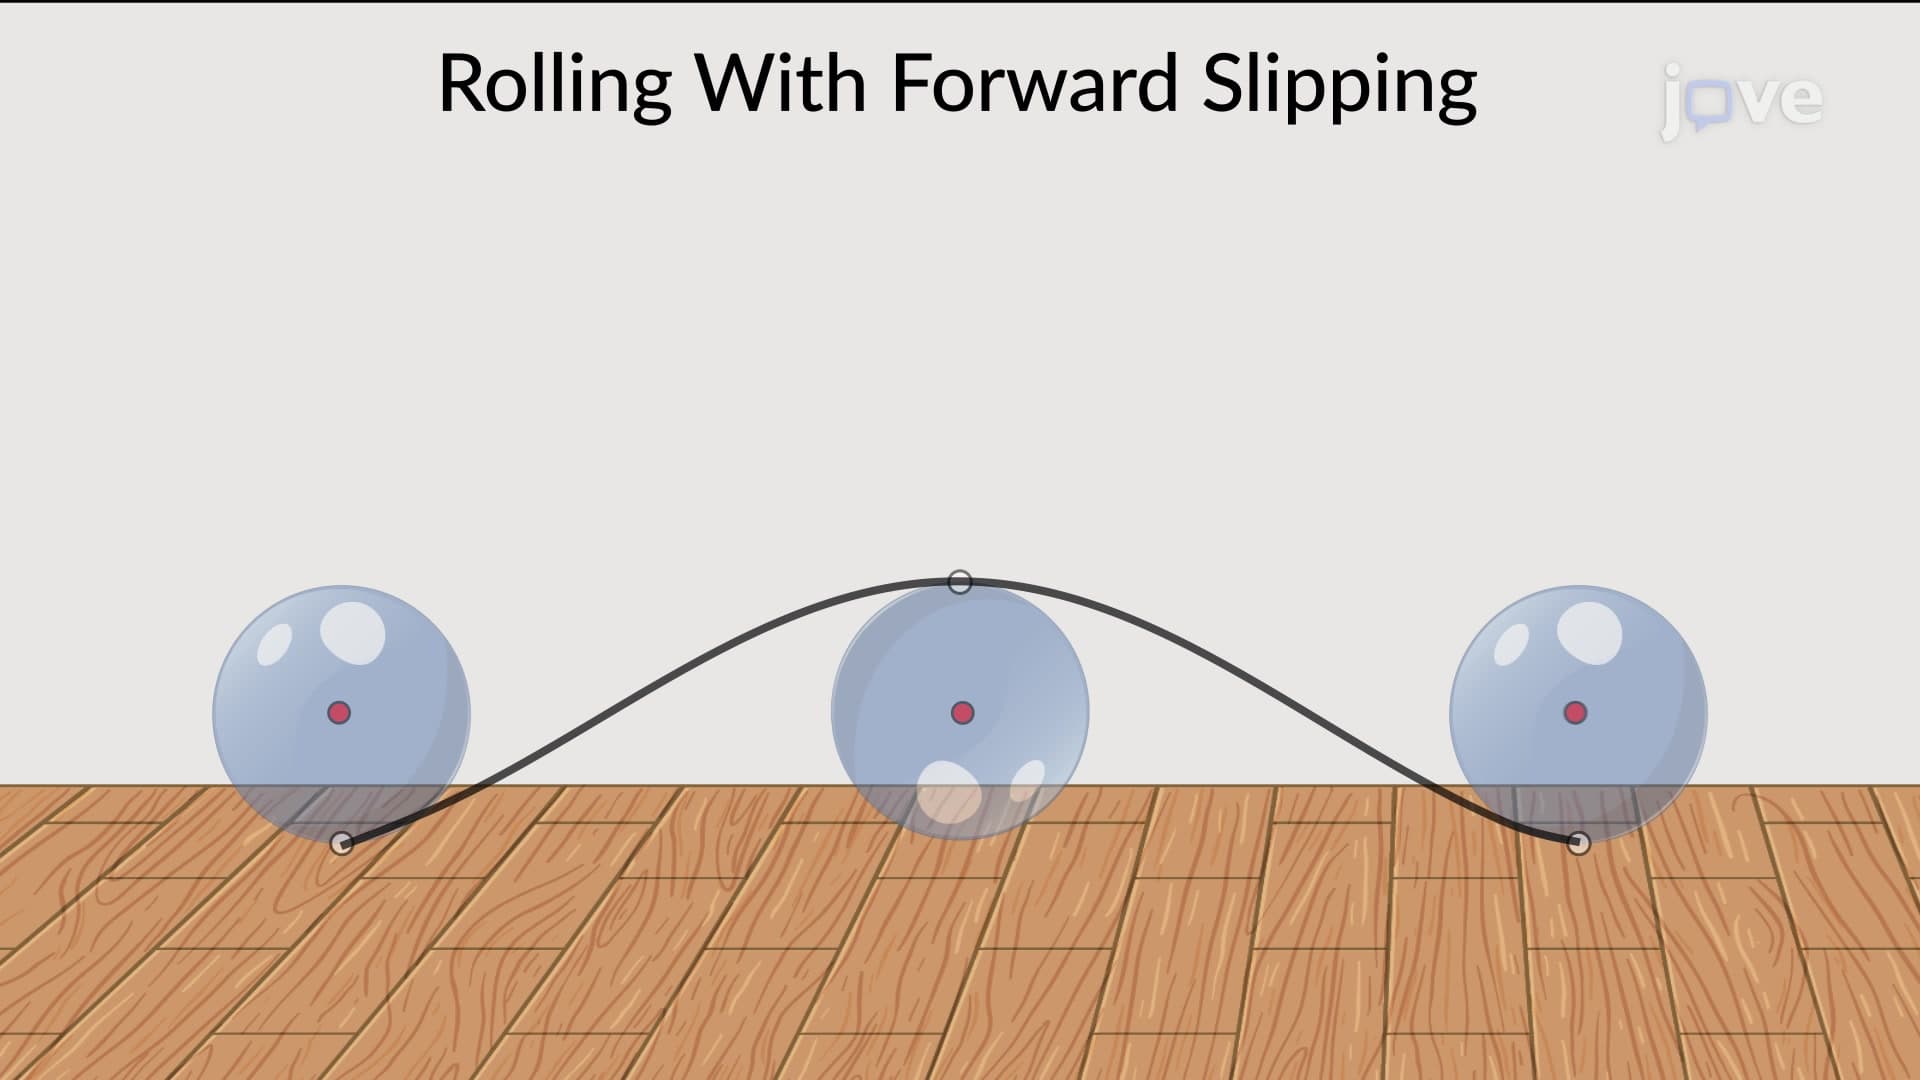 01:14
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
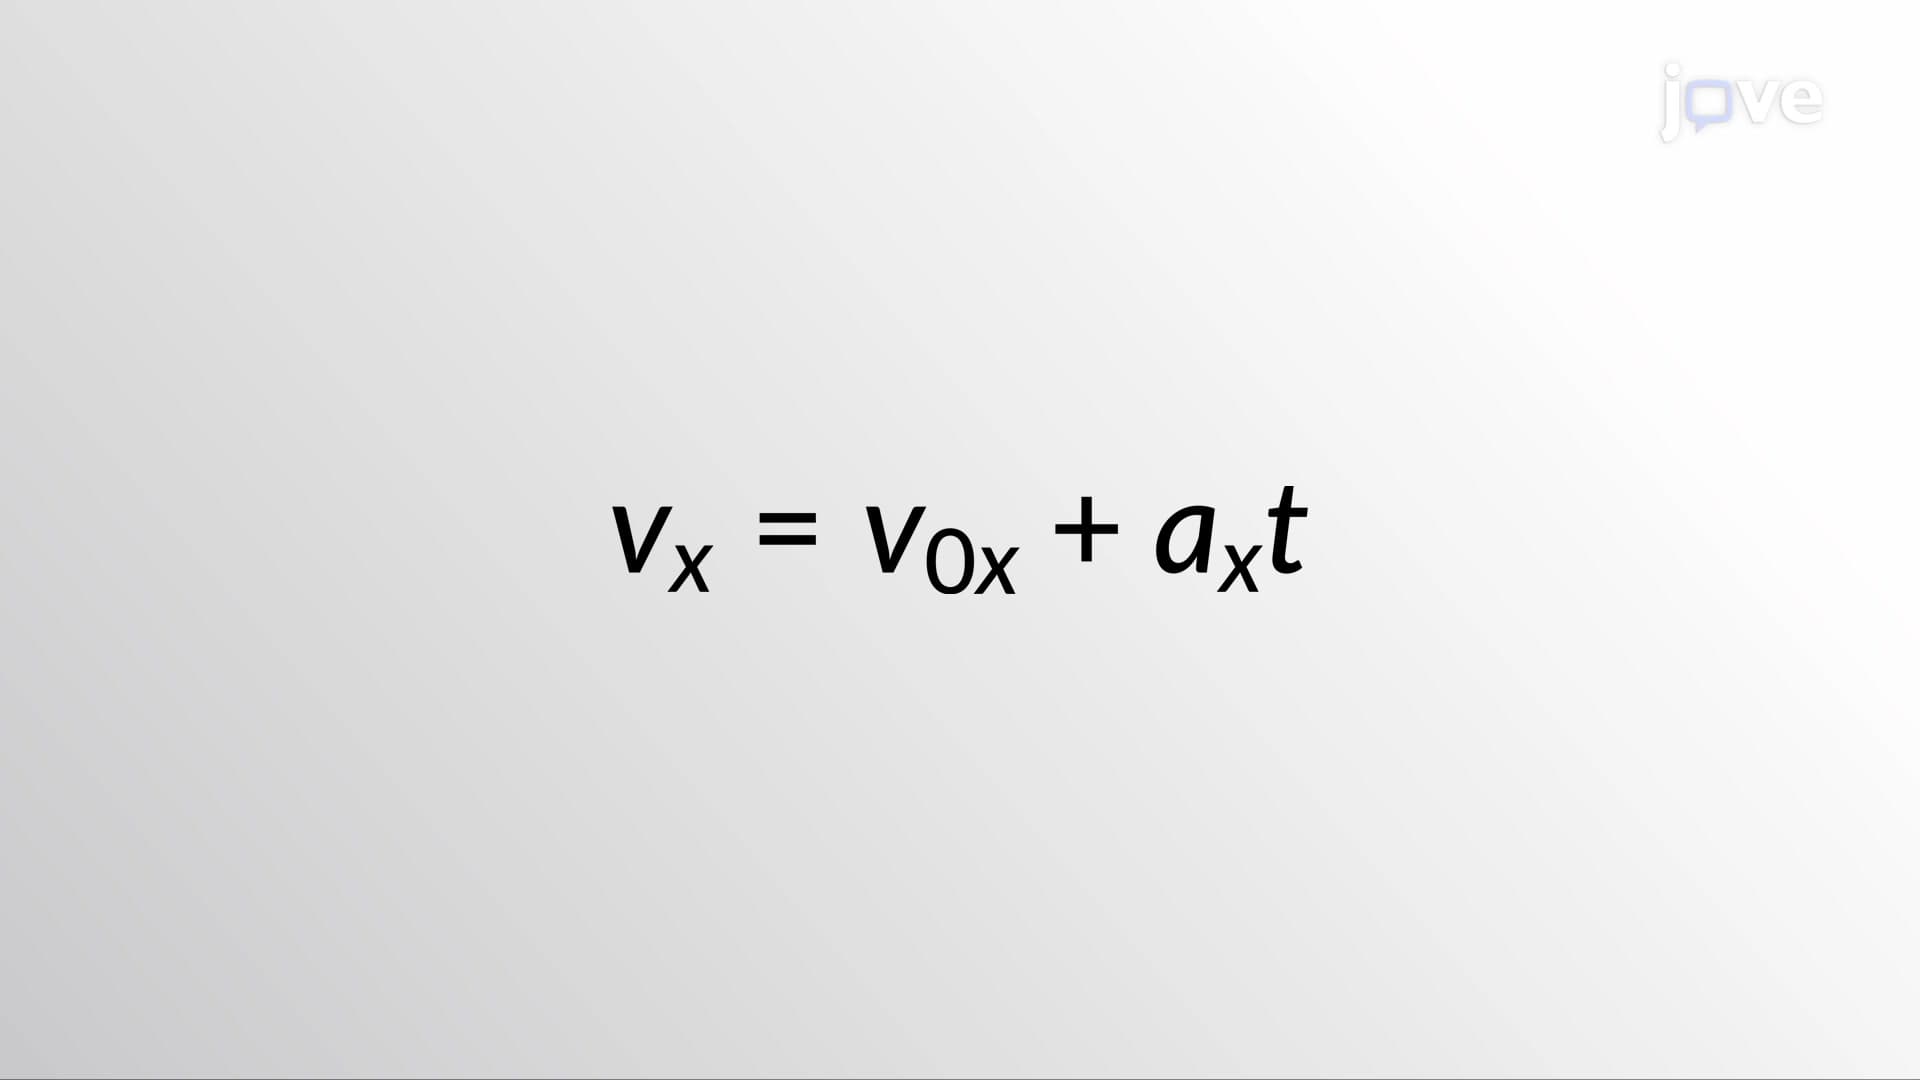 01:26
Kinematic Equations - I
 01:21
Rolling Resistance
For instance, imagine a hard cylinder rolling on a comparatively soft surface. The cylinder's weight compresses the surface beneath it. As the cylinder moves, the material in front of it slows down due to...
 01:23
Knee Joint
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...