Predefined-time Lyapunov function-based sliding mode control for spacecraft rendezvous and docking
Related Experiment Video
Updated: Feb 14, 2026
Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
Zhiwen Fan1, Xiaojuan Song2, Shufeng Lu1
1School of Mechanics and Aeronautics, Inner Mongolia University of Technology, Hohhot 010051, China.

Abstract:
This study focuses on the predefined-time control problem for spacecraft rendezvous and docking (R&D), with particular attention to the effects of external disturbances, actuator faults, and actuator saturation. First, the relative motion model incorporates gravity gradient torque and perturbative forces induced by the J2 term to enhance the practical applicability of the controller. Subsequently, a new Lyapunov function with predefined-time stability properties is proposed, and a predefined-time sliding mode controller is developed based on sliding mode control theory to ensure that the system states converge within a specified time. The proposed controller is general and can be extended to other nonlinear control problems. Additionally, a control torque redistribution scheme is designed to reduce actuator workload and energy consumption, enabling optimal control allocation even under the influence of disturbances, faults, and saturation. Finally, comparative simulations are conducted to validate the effectiveness and robustness of the proposed control strategy.
More Related Videos
 06:04
Experimental Investigation of the Hierarchical Control in DC Microgrids Using a Real-time Simulator
Published on: February 14, 2025
 10:25
Screening Traditional Chinese Medicine Compounds for Inhibiting UCHL3 Activity Based on Molecular Docking and Deubiquitinating Enzyme Probe Technology
Published on: November 22, 2024
Related Concept Videos
 01:07
What is a Mode?
There can be more than one mode in a data set if multiple values have the same highest frequency. For instance, suppose that the Statistics exam scores of 20 students are: 50; 53; 59; 59; 63; 63; 72; 72; 72; 72; 72; 76; 78; 81; 83; 84; 84; 84; 90; 93. Here, the mode is 72, as it occurs most frequently, five times.
A data set with two modes is called bimodal. For example,...
 01:21
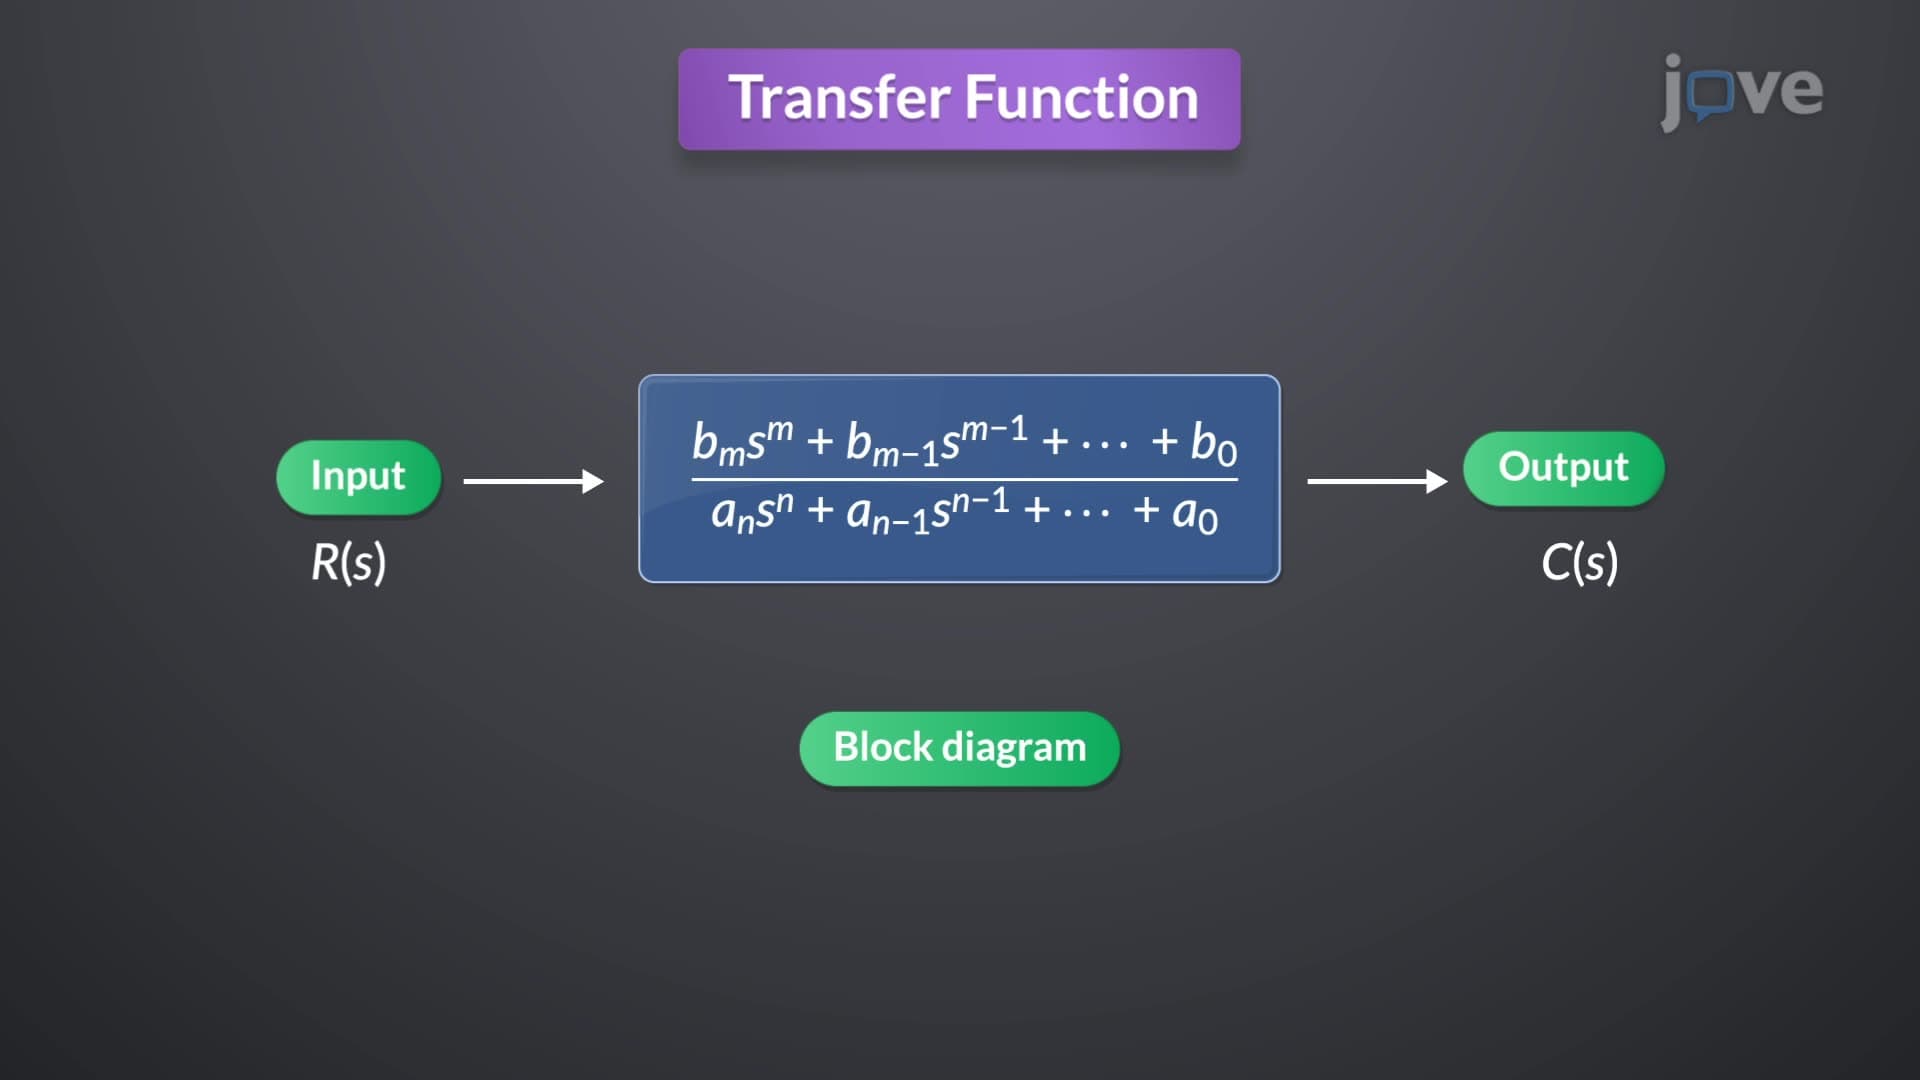
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:14
Ventilatory Modes
There are three ventilatory modes: full support, partial support, and spontaneous. These are described below.
Full Support Modes
Full support modes include controlled mechanical ventilation, continuous mandatory...
 01:30
Exponential Functions with Base e