Experimental Evaluation of Kinematic Compatibility in Three Upper Limb Exoskeleton Configurations Using Interface Force and Torque
Related Experiment Video
Updated: Feb 27, 2026
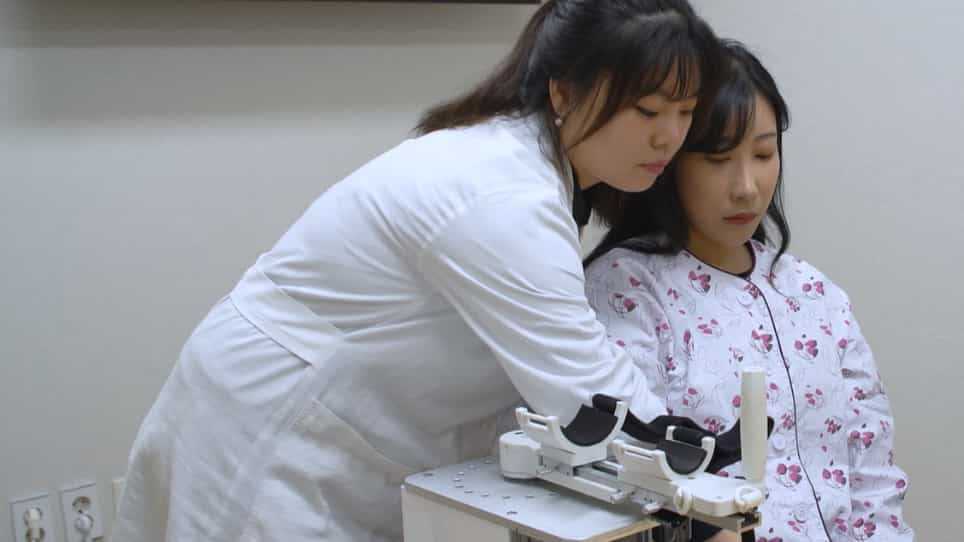
Isokinetic Robotic Device to Improve Test-Retest and Inter-Rater Reliability for Stretch Reflex Measurements in Stroke Patients with Spasticity
Published on: June 12, 2019
Hui Zeng1, Hao Liu1, Longfei Fu2
1School of Bailie Mechanical Engineering, Lanzhou City University, No. 572, Anning East Road, Anning District, Lanzhou 730070, China.

Abstract:
Upper limb rehabilitation exoskeletons form a spatial closed kinematic chain with the human arm, where inevitable joint-center and axis misalignment can generate hyperstatic interaction forces and torques. Passive degrees of freedom (DOF) are widely introduced to improve kinematic compatibility, yet different compatible configurations may exhibit distinct wearable performance. This study experimentally compares three compatible four-degree-of-freedom exoskeleton configurations derived from the synthesis of Li et al. using a single reconfigurable rehabilitation robot. The platform is assembled into each configuration through modular passive units and instrumented with two six-axis force-torque sensors at the upper-arm and forearm interfaces. Interaction forces and torques are measured in passive training mode during eating and combing trajectories. For each configuration, tests are performed with passive joints released and with passive joints locked to quantify the effect of passive motion accommodation. Directional and resultant metrics are computed using mean and peak values over movement cycles. Results show that releasing passive joints consistently reduces interaction loading, and Category 2 achieves the lowest forces and torques with the strongest peak suppression, indicating the best practical compatibility.

Related Concept Videos
 01:30
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:23
Simplification of a Force and Couple System: II
 01:15
Torque Free Motion
 01:05
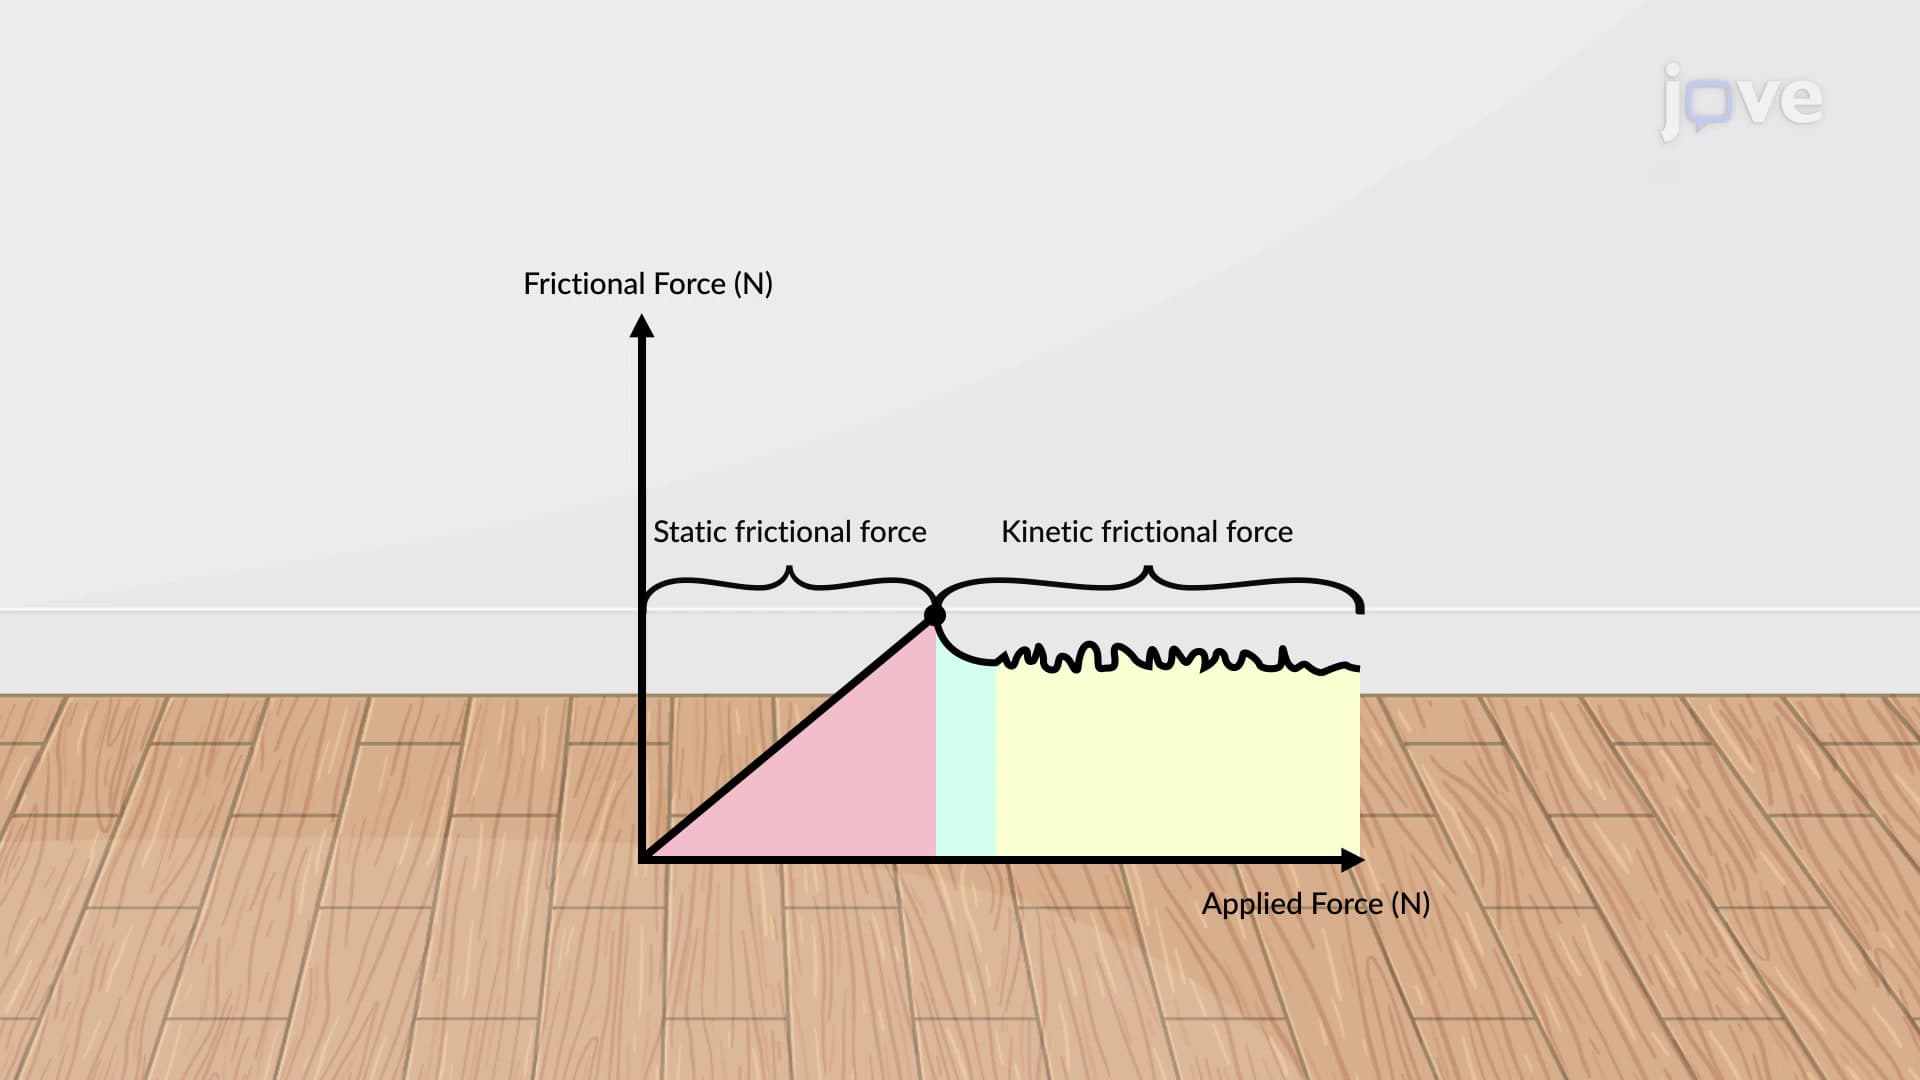
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...