Related Experiment Video
Updated: Mar 1, 2026
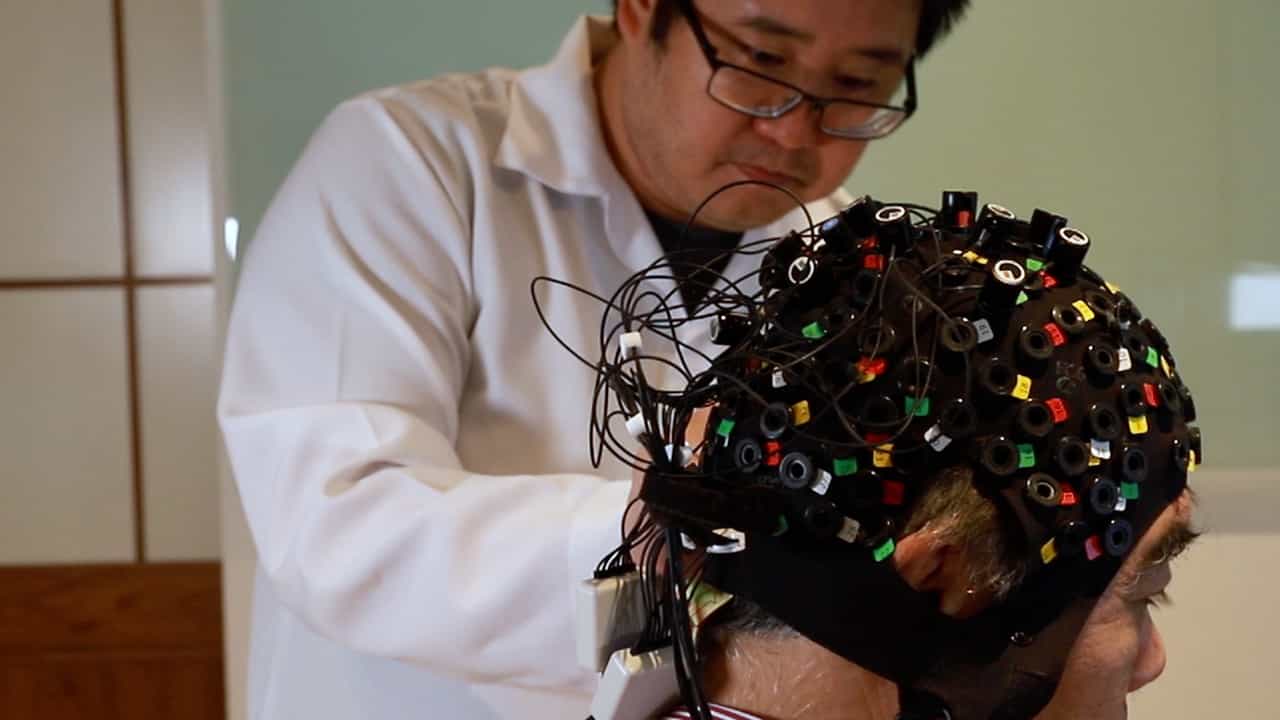
Author Spotlight: Assessing Brain Activity in Robotic-Assisted Lower Limb Rehabilitation Using fNIRS
Published on: June 7, 2024
Current progress of active compliance control strategies and applications in lower limb exoskeleton rehabilitation
Sujiao Li1, Yixin Yang1, Shuyi Cheng1
1Institute of Rehabilitation Engineering and Technology, University of Shanghai for Science and Technology, Shanghai, People's Republic of China.

Introduction:
With the increasing requirements for performance and safety of lower limb exoskeleton rehabilitation robots, researchers are exploring various active compliance control strategies to improve the compliance of control and enhance safety and effectiveness of rehabilitation training. The focus of this paper is to evaluate existing active compliance control strategies applied to lower limb exoskeleton rehabilitation robots, highlighting their principles, key technologies, and performance.
Areas Covered:
Literature searches were conducted in PubMed and Web of Science from 2000 to 2025, starting with the broad keyword 'active compliance control strategy' and narrowing down to specific aspects such as 'impedance control'. Sixty-nine articles were reviewed, and eight active compliance control strategies were divided into three categories according to their core principles: impedance control (n = 18), force, and position hybrid control (n = 27) and machine learning-based hybrid control (n = 24). Their applications in five types of lower limb exoskeleton rehabilitation robots are outlined.
Expert Opinion:
Active compliance control strategies for lower limb exoskeleton rehabilitation robots are necessary for safe human-robot interaction and assist-as-needed implementation. This paper envisions the concept of an active compliance controller that covers the entire rehabilitation cycle, ensuring that the robot is continuously aligned with the patient's rehabilitation needs.
More Related Videos
 04:49
Author Spotlight: Enhancing Post-Stroke Upper Limb Rehabilitation with Robotic Technologies for Improved Motor Recovery and Functional Outcomes
Published on: September 6, 2024
 09:46
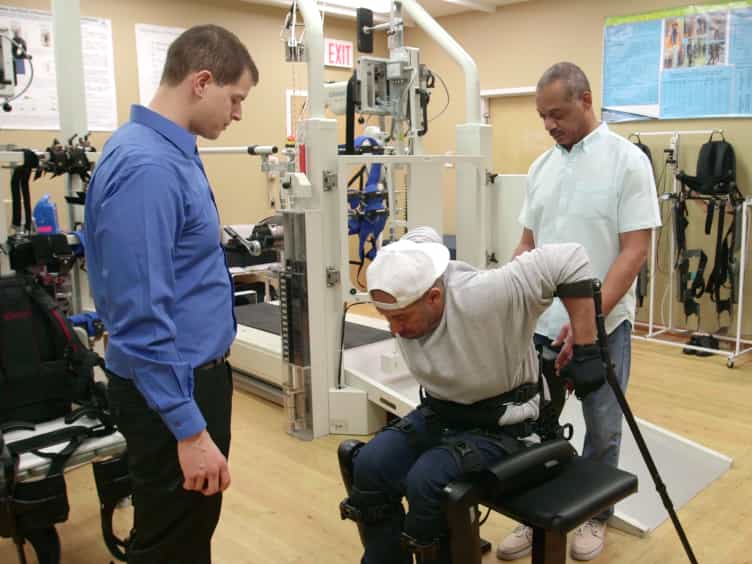
Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016