Related Experiment Video
Updated: Mar 6, 2026
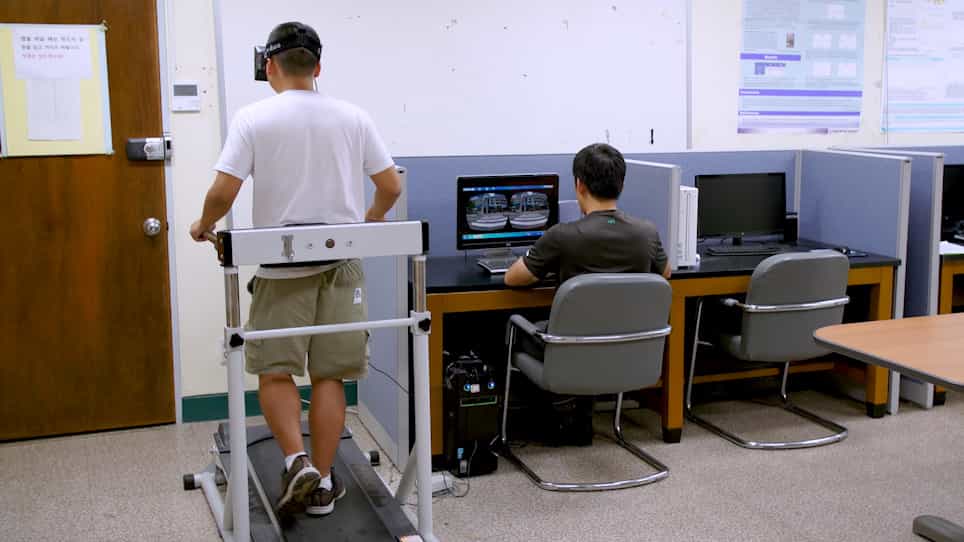

Using a Virtual Reality Walking Simulator to Investigate Pedestrian Behavior
Published on: June 9, 2020
DPIU: Dynamic Pedestrian Intention Understanding Through Cognitive Decision-Making

Abstract:
Accurate prediction of pedestrian motion is crucial for autonomous driving, particularly in path planning and collision avoidance applications. Most current methods concentrate on spatiotemporal feature parameters (e.g., velocity continuity, social force parameters, and poses) extracted from historical trajectories to model pedestrian movement. However, these methodologies fail to adequately capture pedestrian intent and do not dynamically account for behavioral heterogeneity, leading to significant discrepancies with real-world observations. To address this issue, a dynamic pedestrian intention understanding (DPIU) framework is proposed, which links future intentions to historical experiences. Grounded in cognitive decision-making mechanisms derived from human physiology, the DPIU framework is designed to predict pedestrian motion by inferring inherent movement intentions. To establish a comprehensive historical perspective, a multiscale detail feature module is employed, incorporating a time-scale-based trajectory segmentation strategy to enhance the representation of pedestrian states. Subsequently, a goal intent prediction module is introduced, employing a probabilistic model to estimate pedestrians' inclination toward the spatial scope of their intended goals. This module assesses the similarity between the current scene and historical experiences, thereby optimizing the utilization of time-fragmented information. Finally, a dynamic optimization module is developed, which superimposes intent point probabilities and applies a Bayesian-based density estimation method to ensure that the predicted outcomes closely align with real-world behaviors. Experimental evaluations on the Stanford drone drones (SDD), ETH-UCY, and ApolloScape datasets demonstrate that the proposed DPIU framework outperforms existing methods in predicting future trajectories and optimizing multimodal forecasting outcomes. The method substantially improves predictive performance in dynamic scenarios, providing a valuable tool for autonomous driving applications.
More Related Videos
Related Concept Videos
 01:20
Decision Making
Automatic decision-making is fast, intuitive, and relies on gut feelings...
 01:37
Reason and Intuition
 01:14
Decision Making: Traditional Method
First, a specific claim about the population parameter is decided based on the research question and is stated in a simple form. Further, an opposing statement to this claim is also stated. These statements can act as null and alternative hypotheses, out of which a null hypothesis would be a...
 01:09
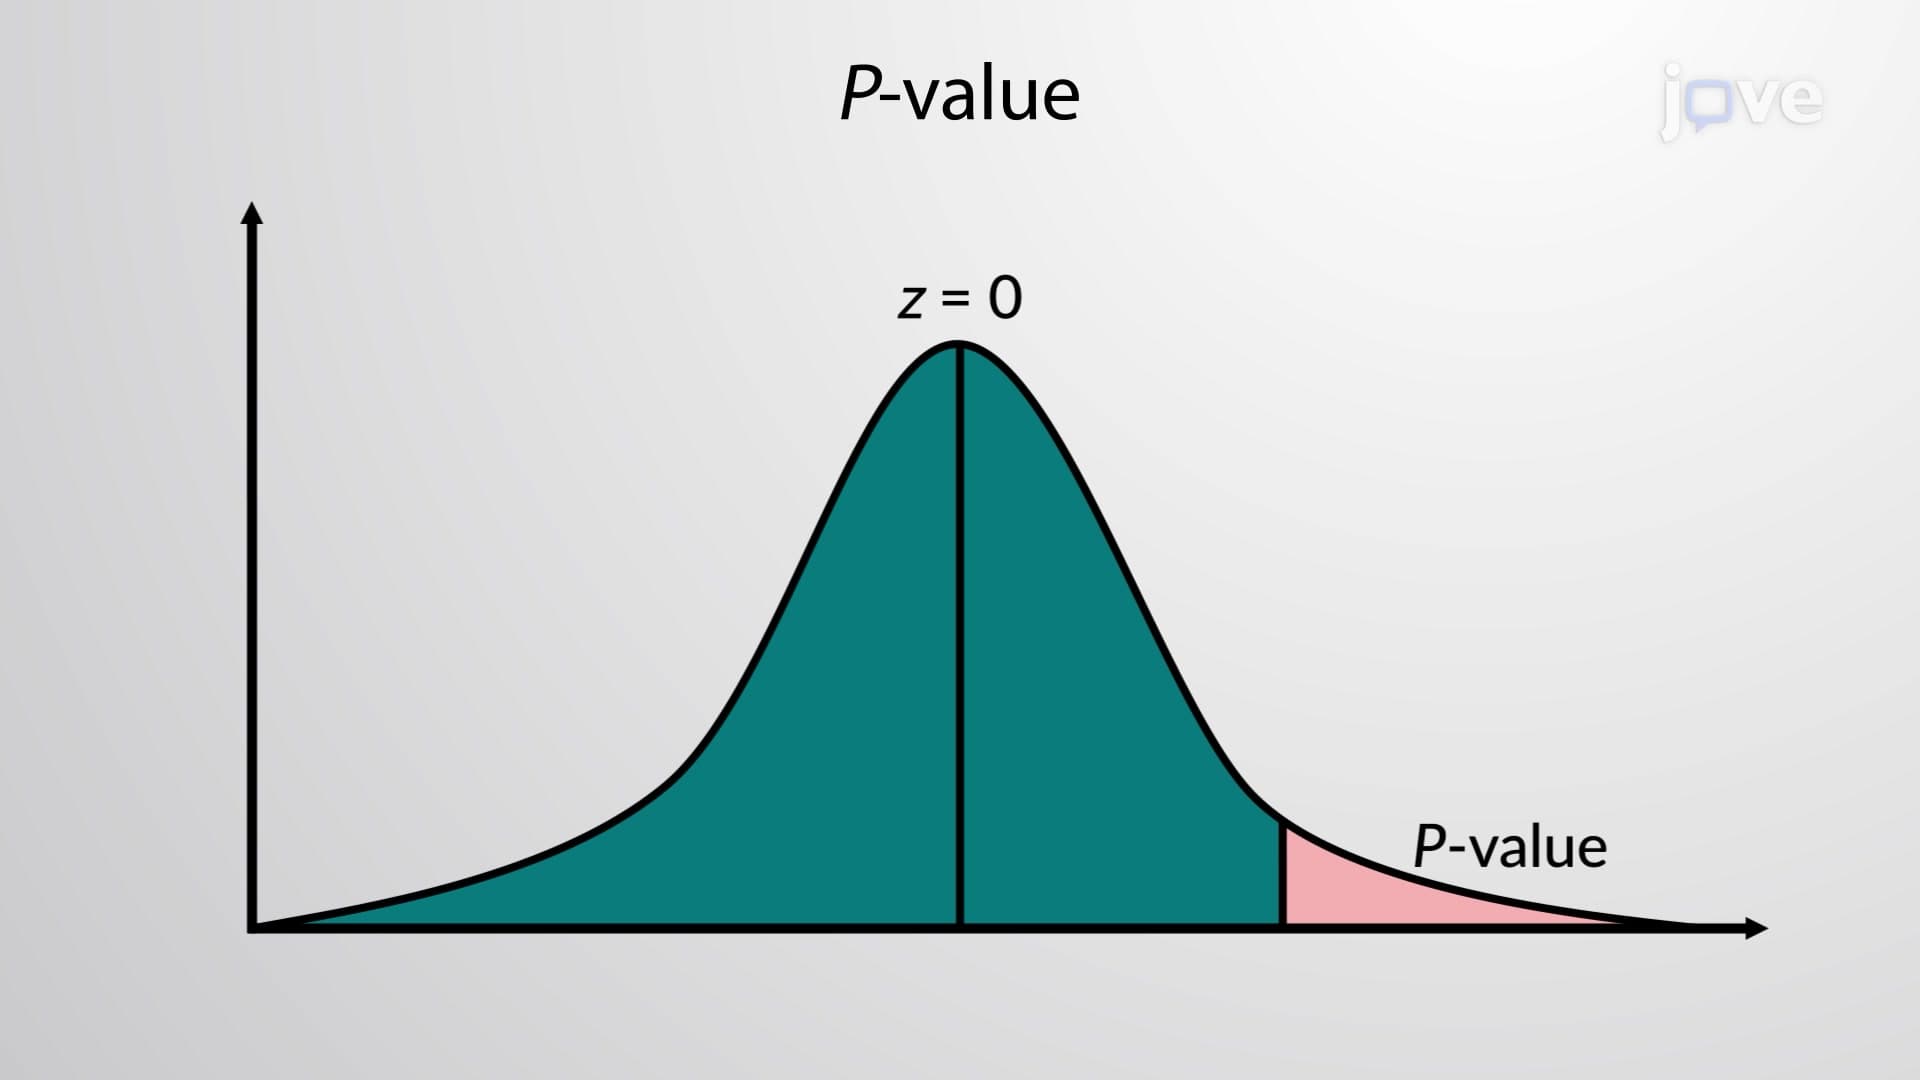
Decision Making: P-value Method
First, a specific claim about the population parameter is proposed. The claim is based on the research question and is stated in a simple form. Further, an opposing statement to the claim is also stated. These statements can act as null and alternative hypotheses: a null hypothesis would be a neutral statement while the alternative hypothesis can...
 01:20
Introduction to Cognitive Psychology
This field emerged in the mid-20th century, following a period dominated by behaviorism, which...
 01:17
Cognitivism
Previously dominated by behaviorism, which prioritized observable behaviors and largely ignored mental processes, psychology transformed in the 1950s. Cognitive psychologists argue that understanding how we think and process...