

Force sensorless interaction wrench estimation for neural-learning impedance control of a flying parallel robot with
Minglei Zhu1, Yuhui Guo2, Dawei Gong3,4
1Institute of Smart City and Intelligent Transportation, Southwest Jiaotong University, Chengdu, China.

Abstract:
This paper proposes a sensorless adaptive neural-learning impedance controller for a flying parallel robot (FPR) to enable compliant physical interaction while explicitly accommodating actuator saturation. The dynamic model of the multi-UAV heterogeneous cooperative FPR is first established, and an external wrench observer is developed to estimate the contact-induced torque. To address system uncertainties and achieve robust disturbance rejection, a Lyapunov-based radial basis function neural network (RBFNN) impedance controller with force-tracking capability is designed. An auxiliary compensation system is further incorporated to alleviate the adverse effects of actuator input saturation. The closed-loop stability of the overall FPR system under the proposed control law is rigorously guaranteed. ADAMS-Simulink co-simulation results demonstrate the effectiveness of the approach, confirming its ability to maintain stable and compliant interaction across diverse contact conditions.


Related Concept Videos
 00:57
Power Expended by a Constant Force
 01:22
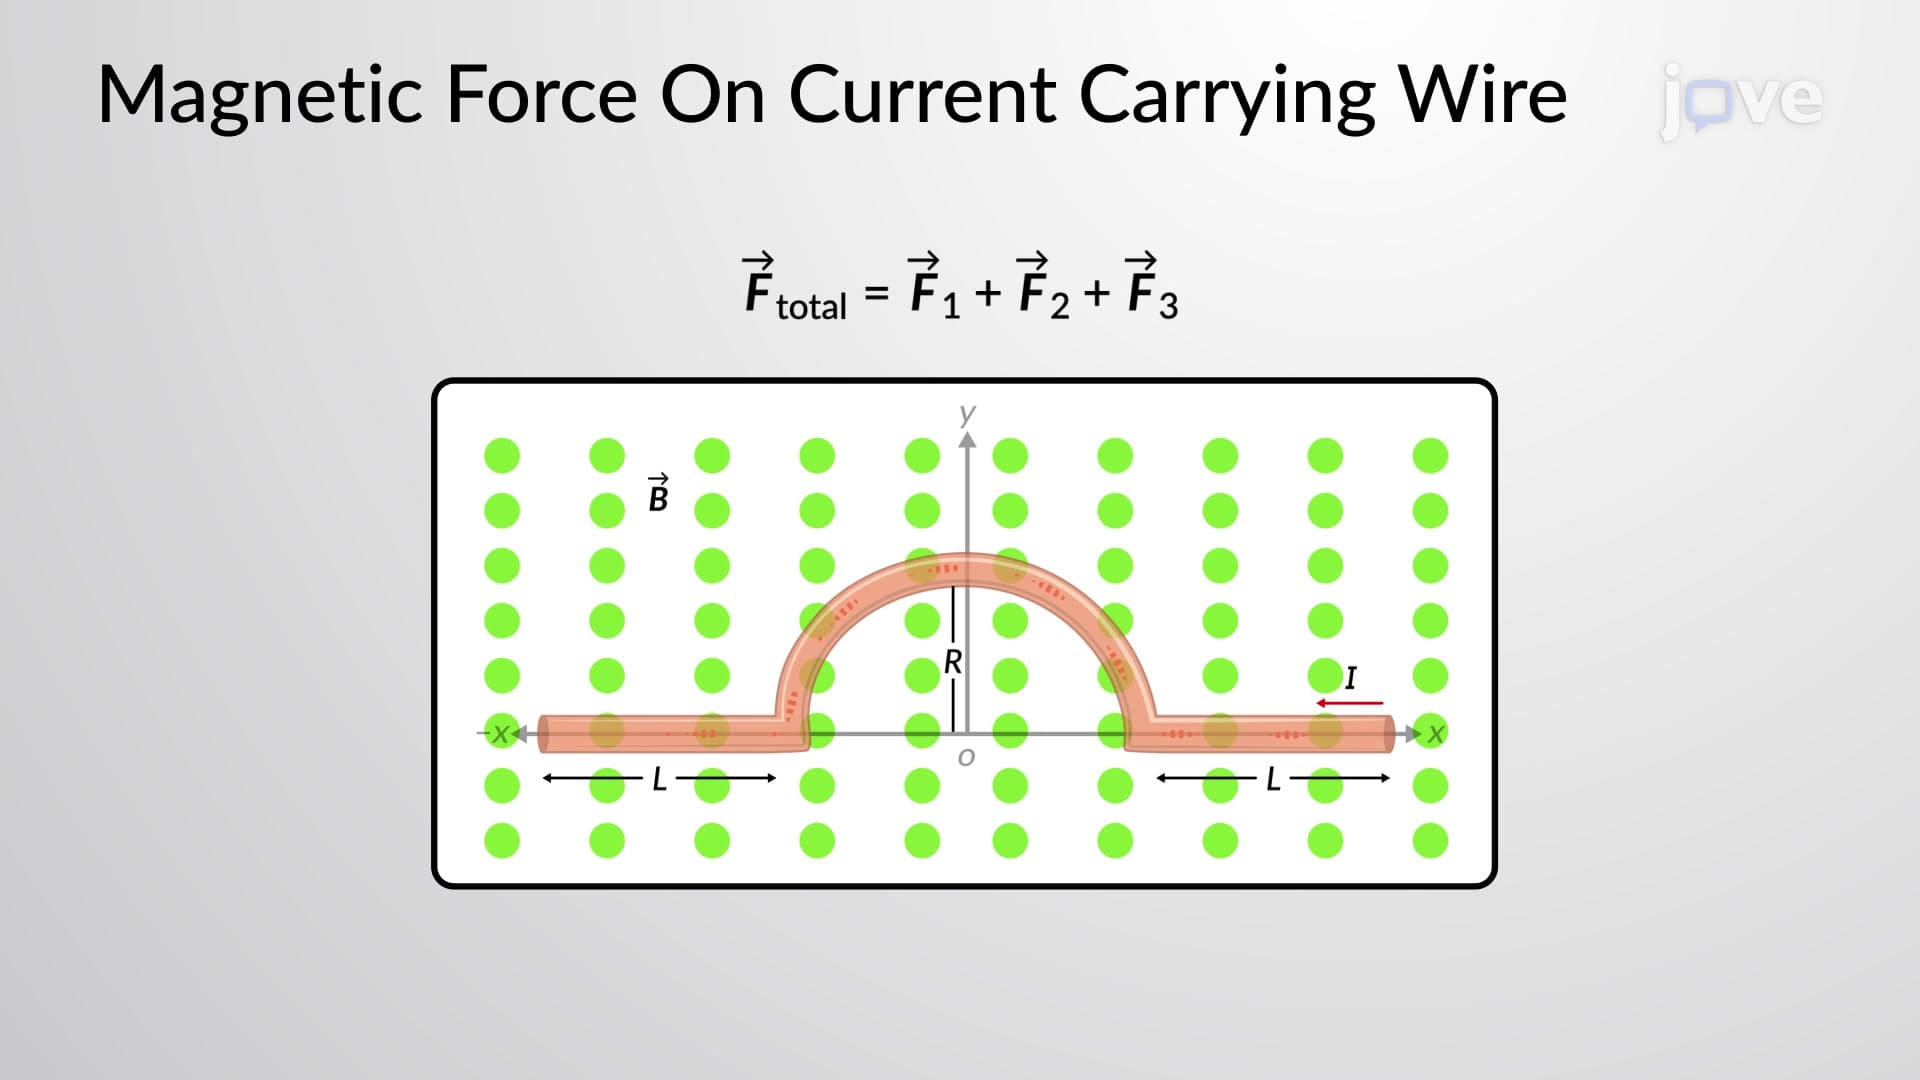
Magnetic Force On Current-Carrying Wires: Example
 01:14
Design Example: Frog Muscle Response
When the switch connecting the RL circuit is closed, a brief muscle contraction is observed. This is because, at a steady state, the inductor acts like a short...
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:17
Design Example: Underdamped Parallel RLC Circuit
Starting with a fixed...