Related Experiment Video
Updated: Mar 15, 2026

Simultaneous Measurement of Turbulence and Particle Kinematics Using Flow Imaging Techniques
Published on: March 12, 2019
Real-Time Pose Measurement Framework of Wind Tunnel Aircraft Models Based on a Monocular Time-of-Flight Camera
Jianqiang Huang1, Cui Liang1, Shuai Zhao1
1College of Optical Science and Engineering, Zhejiang University, Hangzhou 310027, China.

Abstract:
Precise and real-time acquisition of aircraft model attitude is fundamental for aerodynamic analysis in wind tunnel experiments, yet achieving high-precision non-contact measurement remains a significant challenge. To address this, this paper proposes a pose measurement framework based on a monocular Time-of-Flight (ToF) camera that fuses keyframe global registration with non-keyframe local registration. First, a novel hand-crafted local feature based on three-plane encoded height and density is introduced. When combined with the Two-stage Consensus Filtering RANSAC (TCF-RANSAC) algorithm, this feature achieves robust global registration of keyframes, providing reliable initial pose estimates for the system. Subsequently, leveraging the continuity constraint of model motion, fast incremental local registration of non-keyframes is performed using the Generalized Iterative Closest Point (GICP) algorithm, which avoids falling into local optima while significantly improving computational efficiency. Evaluation results on simulated datasets with synthetic noise and a real experimental platform demonstrate that the method achieves a single-axis rotation angle error of less than 0.03∘ while processing at over 40 FPS, satisfying real-time measurement requirements. Comparative evaluations against multiple existing registration methods indicate that the proposed framework achieves superior accuracy and robustness, reducing rotation angle errors by 9% to 39% compared to mainstream global registration methods under single-view ToF sensing conditions. Furthermore, this study quantifies the error distribution characteristics of monocular ToF-based pose estimation, revealing an "axis-sensitivity" phenomenon where the rotation error around the optical axis is significantly lower (e.g., 0.02∘, 0.03∘) than that around the orthogonal axes (e.g., 0.38∘, 0.26∘). These findings provide practical guidance for camera placement and system design in high-precision aerodynamic measurement scenarios.
Related Concept Videos
 01:29
Application of Linearization and Approximation
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:24
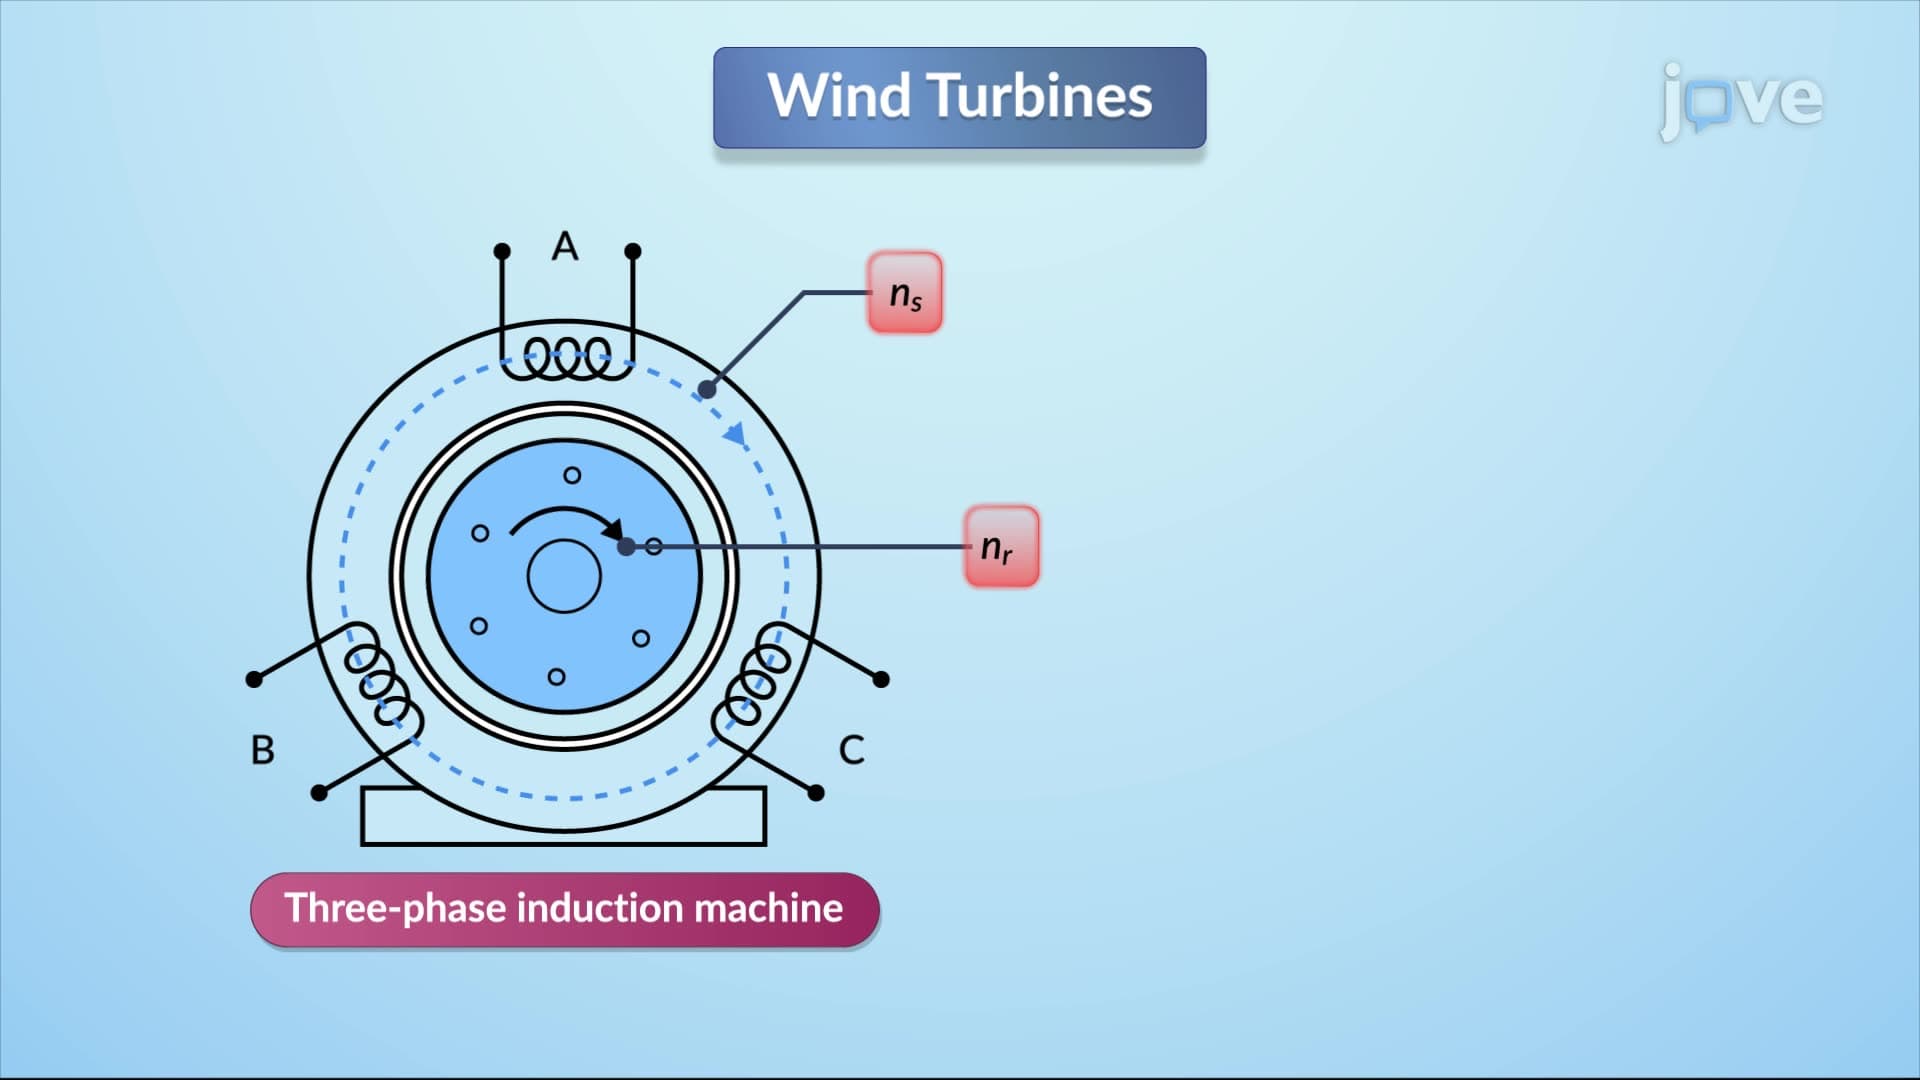
Wind Turbine Machine Models
Induction machines interact through the rotating magnetic field generated by the stator and the rotor. The key parameter is slip, which is the difference between synchronous speed and rotor speed relative to synchronous speed. Slip is...