Effects of fatigue on the activation characteristics and synergistic patterns of lower limb muscles during running
Related Experiment Video
Updated: Mar 24, 2026
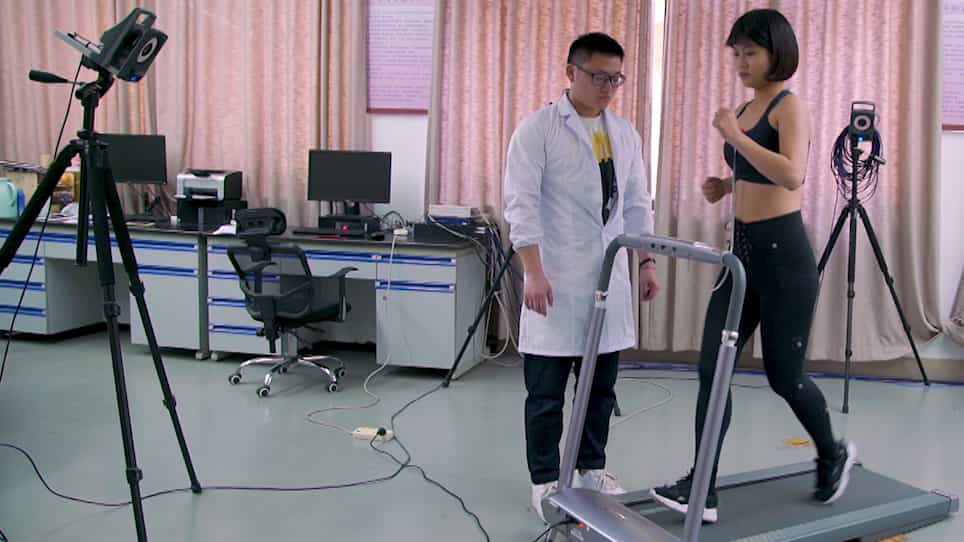
Comparative Analysis of Lower Limb Kinematics between the Initial and Terminal Phase of 5km Treadmill Running
Published on: July 17, 2020
1Department of Track and Field, Institute of Physical Education and Training, Capital University of Physical Education and Sports, Beijing, China.

Objective:
This study aimed to investigate the effects of fatigue on the control mechanism of the lower limb neuromuscular system during running.
Methods:
The study participants were 25 male running enthusiasts (age: 20.9 ± 1.6 years; height: 174.8 ± 4.5 cm; body mass: 70.3 ± 5.2 kg) with more than 3 years of running experience. Surface electromyography (sEMG), motion capture, and heart rate monitoring technologies were used to obtain data for analysis in three dimensions: muscle activation, joint co-activation, and muscle synergy. The participants began running at 8 km/h, with the speed increased by 1 km/h every 2 min until their heart rate reached 75% of the estimated maximum heart rate (MHR), after which an individualized constant-speed phase was performed. Peak fatigue state was determined by two criteria: heart rate reaching 90% of MHR and a Borg scale score of ≥17. Data were compared before and after fatigue. Muscle synergies were extracted using non-negative matrix factorization (NNMF), and the number of modules was determined when the variance accounted for (VAF) first reached 95%.
Results:
The results showed that muscle activation exhibited phase-specific changes after fatigue: During the stance phase, the root mean square (RMS) values of the quadriceps femoris (QF) and gluteus maximus (GM) increased significantly (p < 0.05). During the swing phase, the RMS value of the tibialis anterior (TA) increased significantly while that of the GM decreased significantly (p < 0.05). The joint co-activation ratio (CAR) increased significantly only at the ankle joint during the swing phase (p < 0.05). There was no significant difference in the number of muscle synergy modules (p > 0.05). However, the activation timing of the early stance module was significantly advanced (p < 0.05), and the muscle weights within the modules also changed; for example, the weights of the vastus lateralis (VL) and lateral head of the gastrocnemius (GL) decreased, while the weight of the TA increased (p < 0.05).
Conclusion:
Our results indicate that under running-induced fatigue, the lower limb neuromuscular system maintains motor output based on the principle of "stability first" through three approaches: "selective compensation" to activate muscles, "rigidity enhancement" to stabilize distal joints, and "timing adjustment" to optimize synergy modules. The findings may contribute to training optimization and help reduce the likelihood of potential injuries.
More Related Videos
 06:35
Using Gold-standard Gait Analysis Methods to Assess Experience Effects on Lower-limb Mechanics During Moderate High-heeled Jogging and Running
Published on: September 14, 2017
 06:00
Determining The Electromyographic Fatigue Threshold Following a Single Visit Exercise Test
Published on: July 27, 2015
