Disturbance compensation based on harmonic injection switching for unknown time-delay systems
Related Experiment Video
Updated: Mar 30, 2026
Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
Xinyu Wen1, Jia Guo1, Shengquan Li2
1School of Intelligent Manufacturing Engineering, Institute of Intelligent Low-Altitude Systems, Shanxi University of Electronic Science and Technology, Linfen, Shanxi, China; Taiyuan University of Science and Technology, Taiyuan, Shanxi, China.

Abstract:
Disturbance rejection under unknown input time-delay remains a challenging problem in control systems. This paper investigates a novel strategy for systems with both unknown input delay and periodic disturbances to achieve asymptotic compensation. First, a characteristic observer is designed to estimate the key parameters related to delay time and disturbance frequency. It is worth noting that the proposed disturbance compensation method does not rely on precise key parameter values. To address this, switching criteria are specially constructed to help determine whether the estimated values enter a reasonable region. Next, reliable delay characteristics can be used to reconstruct and predict disturbances. Compared with existing approximation approaches, the proposed prediction and compensation method requires neither a known upper bound of the delay nor an accurate delay estimate, while enabling quantitative stability analysis. Finally, a numerical example is provided to demonstrate the effectiveness of the proposed disturbance rejection method.
More Related Videos
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
 07:42
Rapid Repetition Rate Fluctuation Measurement of Soliton Crystals in a Microresonator
Published on: December 15, 2021
Related Concept Videos
 01:10
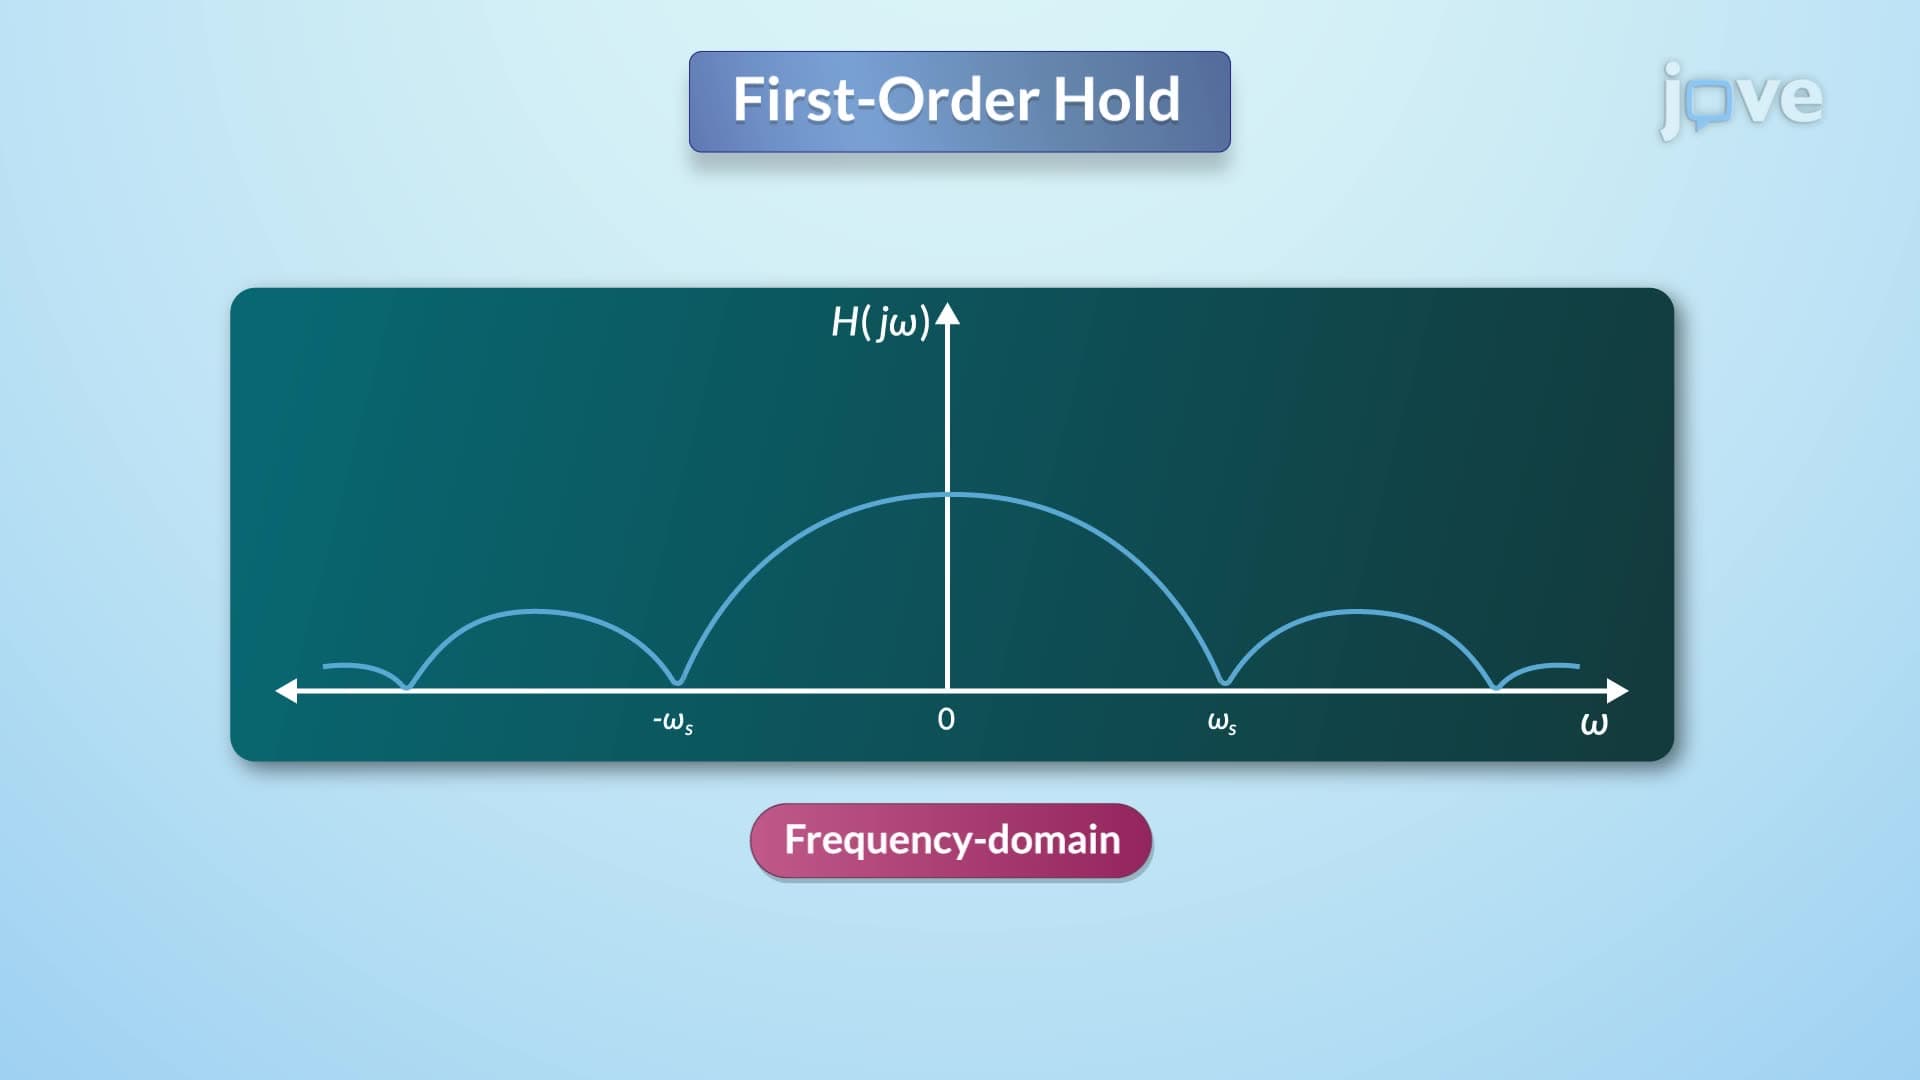
Reconstruction of Signal using Interpolation
 01:18
Second Order systems II
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:14
Parallel RLC Circuits
A simplified parallel RLC circuit model with a DC input source generating a step response is employed in this context. When the switch is turned on, Kirchhoff's current law is applied, leading to a second-order differential equation.
 01:10
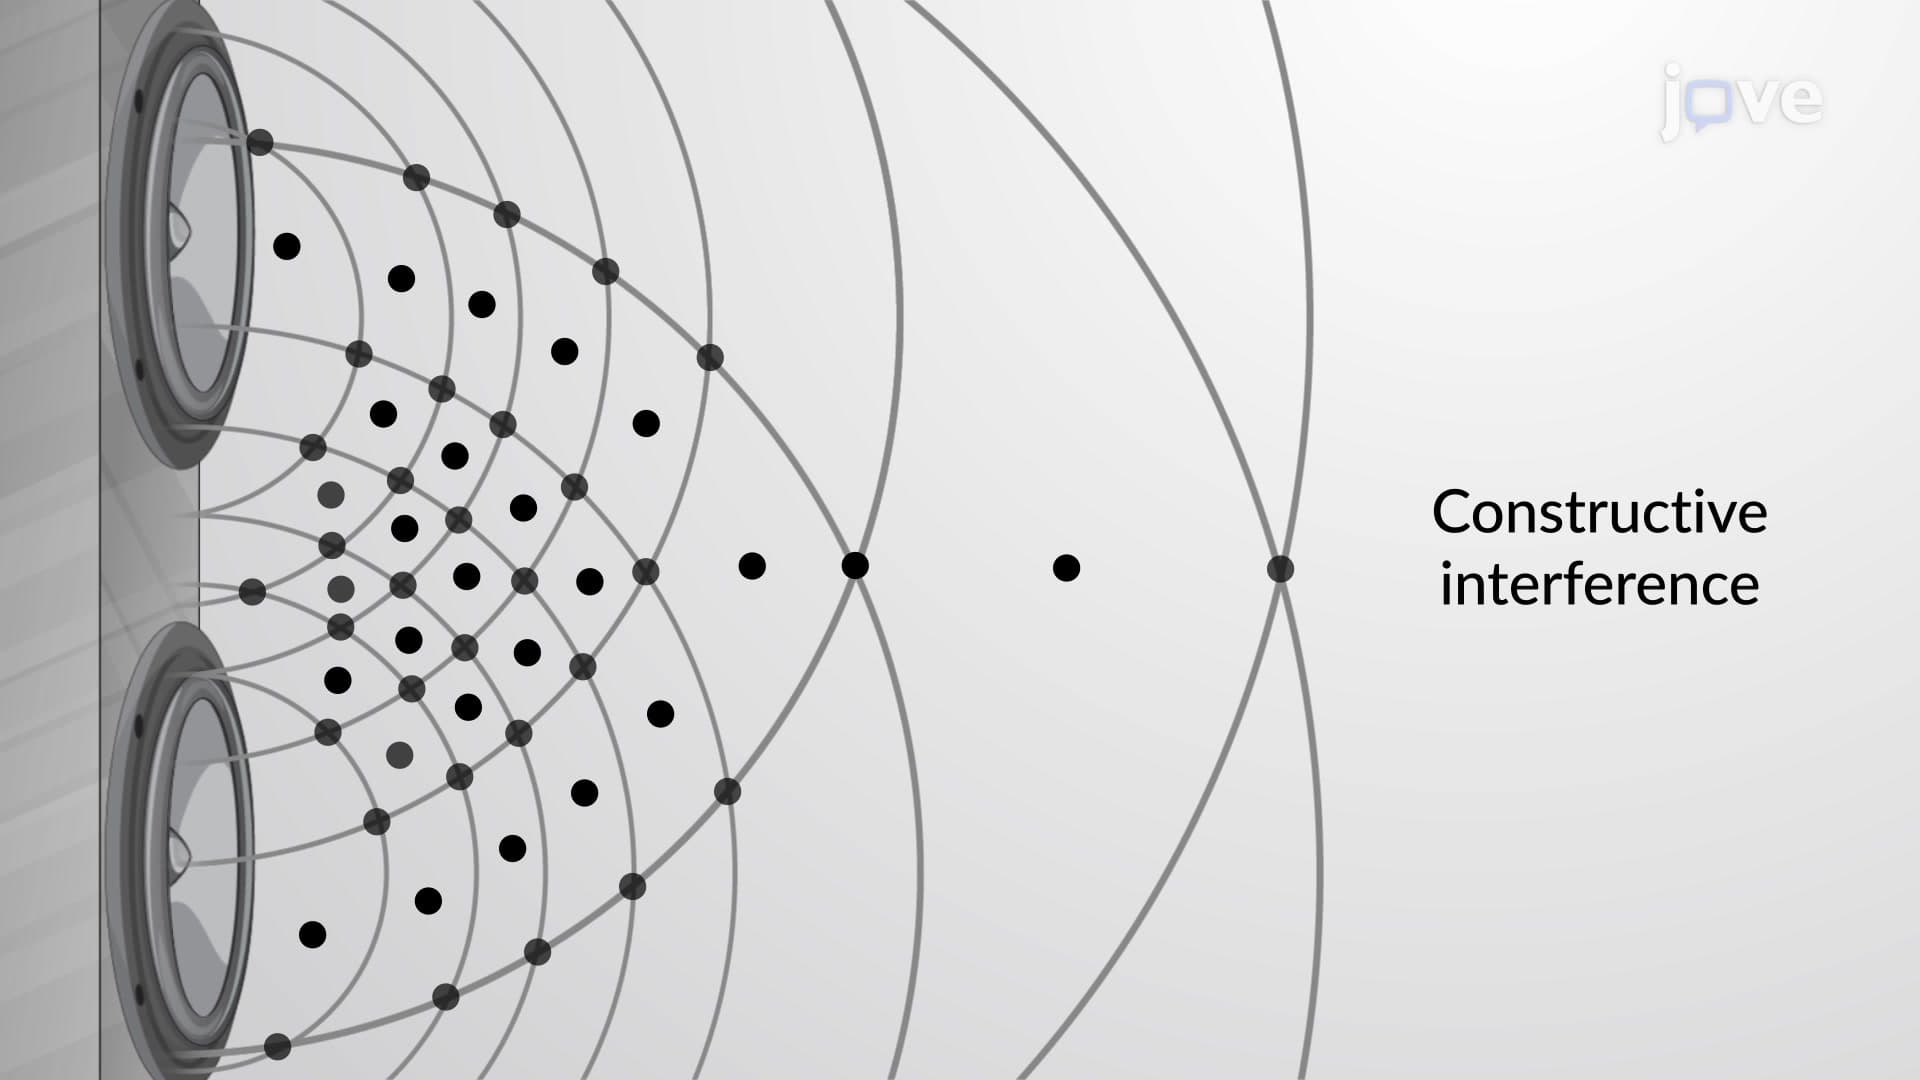
Interference: Path Lengths
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by: