Related Experiment Video
Updated: Apr 3, 2026
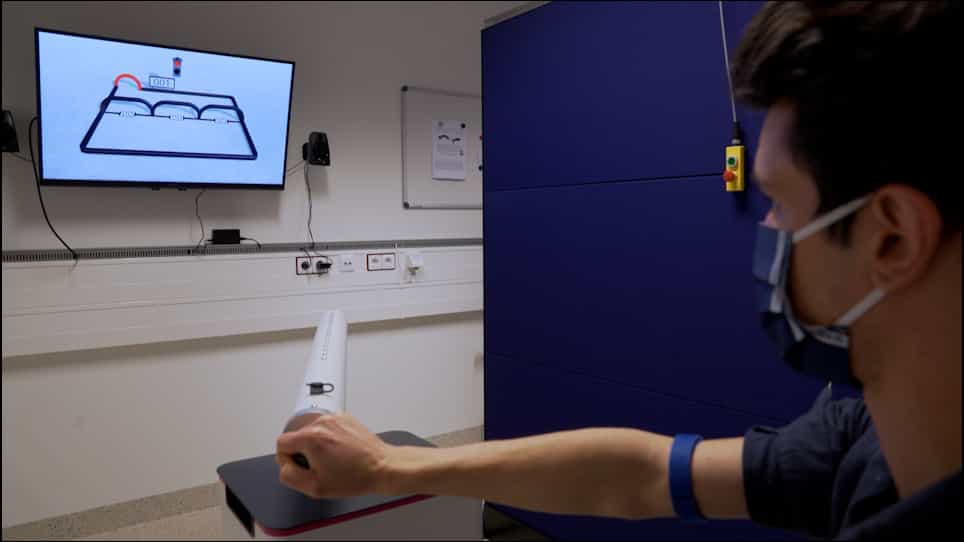

Investigating Pain-Related Avoidance Behavior using a Robotic Arm-Reaching Paradigm
Published on: October 3, 2020
A Pain Memory "Trace": Cumulative Pain Perception and Damping During Fight-or-Flight Response Modeled with a
Wolfgang Fink1, Robert B Raffa2,3
1Visual and Autonomous Exploration Systems Research Laboratory, University of Arizona, Tucson, AZ, USA.

Introduction:
Unlike a single acute pain (such as a single animal bite), cumulative pain arises from multiple sources or occurrences of pain stimuli (eg, multiple animal bites). We earlier introduced a mathematical framework of a coupled feedback control loop using Lotka-Volterra dynamics to model the choreographed interaction between "ascending" and "descending" pain-processing pathways. This model is based on the premise that these pathways, rather than acting independently, should act in a coordinated, coupled, well-controlled feedback loop.
Methods:
In this work, we apply Lotka-Volterra dynamics - coupled first-order nonlinear differential equations used to describe the dynamics of biological systems in which two or more components interact - to examine the effect and magnitude of modulatory feedback (ie, "damping") on the response function (ie, pain perception) to the incidence of cumulative pain.
Results:
Simulations demonstrate that our approach can model individual consecutive pain signals (i) if the inter-pain-signal time is larger than a certain threshold, (ii) if the magnitude of immediate consecutive pain signals differs, or (iii) if during superposition of (partially) concurrent pain signals the magnitude of the resulting superimposed pain signal changes during an ongoing pain signal event.
Discussion:
Our results suggest that pain perception declines after an initial stimulus, but does not immediately return to zero (or baseline); instead, it settles at a lower plateau level that persists essentially for the duration of the stimulus input. With each subsequent pain stimulus, the effect on the plateau level is cumulative, amounting essentially to a pain memory "trace". Therefore, in addition to a measure of the damage of an individual event (eg, a claw swipe), a herein newly-described measure of the cumulative damage is also monitored (eg, multiple claw strikes). This would provide two critical types of information helpful to make a decision to either fight or flee.
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:44
Nociception
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:20
Pain
 01:19
Root-Locus Method
This system can be represented by a block...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...