Related Experiment Video
Updated: Apr 4, 2026


Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
A user behavior inertia based spatio temporal next POI recommendation model
Kaiqi Zhang1, Dianhui Chu2, Zhiying Tu2
1School of Computer Science and Technology, Harbin Institute of Technology, Weihai, 264209, China. zhang_kaiqi2024@126.com.

Abstract:
The next POI (point-of-interest) recommendation problem is very challenging. It requires not only considering the previous state, location, and user context information, but also analyzing the user behavior. The personalization and uncertainty of user behavior are key issues affecting the accuracy of POI recommendation. Despite this, practice has shown that user behavior is driven by purpose and has certain inherent patterns, which we call behavior inertia. It has a subconscious guiding effect on user decision making. Of course, The effect of this influence will be affected by various factors in real-world scenarios, which we collectively refer to as inertia resistance. Therefore, the POI recommendation model proposed in this paper will fully consider the interaction between behavior inertia and inertia resistance to improve the recommendation accuracy. First, we classify POI according to the purpose of user behavior and construct a purpose prediction model. Second, since we consider the influence of geographic location information on user selection behavior, we construct a prediction model based on POI spatial attributes to calculate the probability of POI check-in under a certain purpose. Meanwhile, to further analyze the influence of behavior inertia on user behavior, we established a prediction model based on user behavior inertia. This model integrates multiple resistance factors such as time, number of POI check-ins, and number of POI categories to explore the influence of behavior inertia on users comprehensively. Finally, the above two models are combined to calculate the probability of a user visiting the POI at the next moment and generate a recommendation list. In order to verify the effectiveness of our method, we conducted extensive experiments on two real-world datasets. The experimental results show that compared to the baseline method, our method improves recall and MAP performance by up to 15% and 20%, respectively.
Related Concept Videos
 01:24
Inertia Tensor
The diagonal components of the inertia tensor matrix represent the moments of inertia concerning the principal axes of the object. These primary axes are defined as the axes where the object experiences the least...
 01:08
Outliers and Influential Points
 01:03
Prediction Intervals
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:07
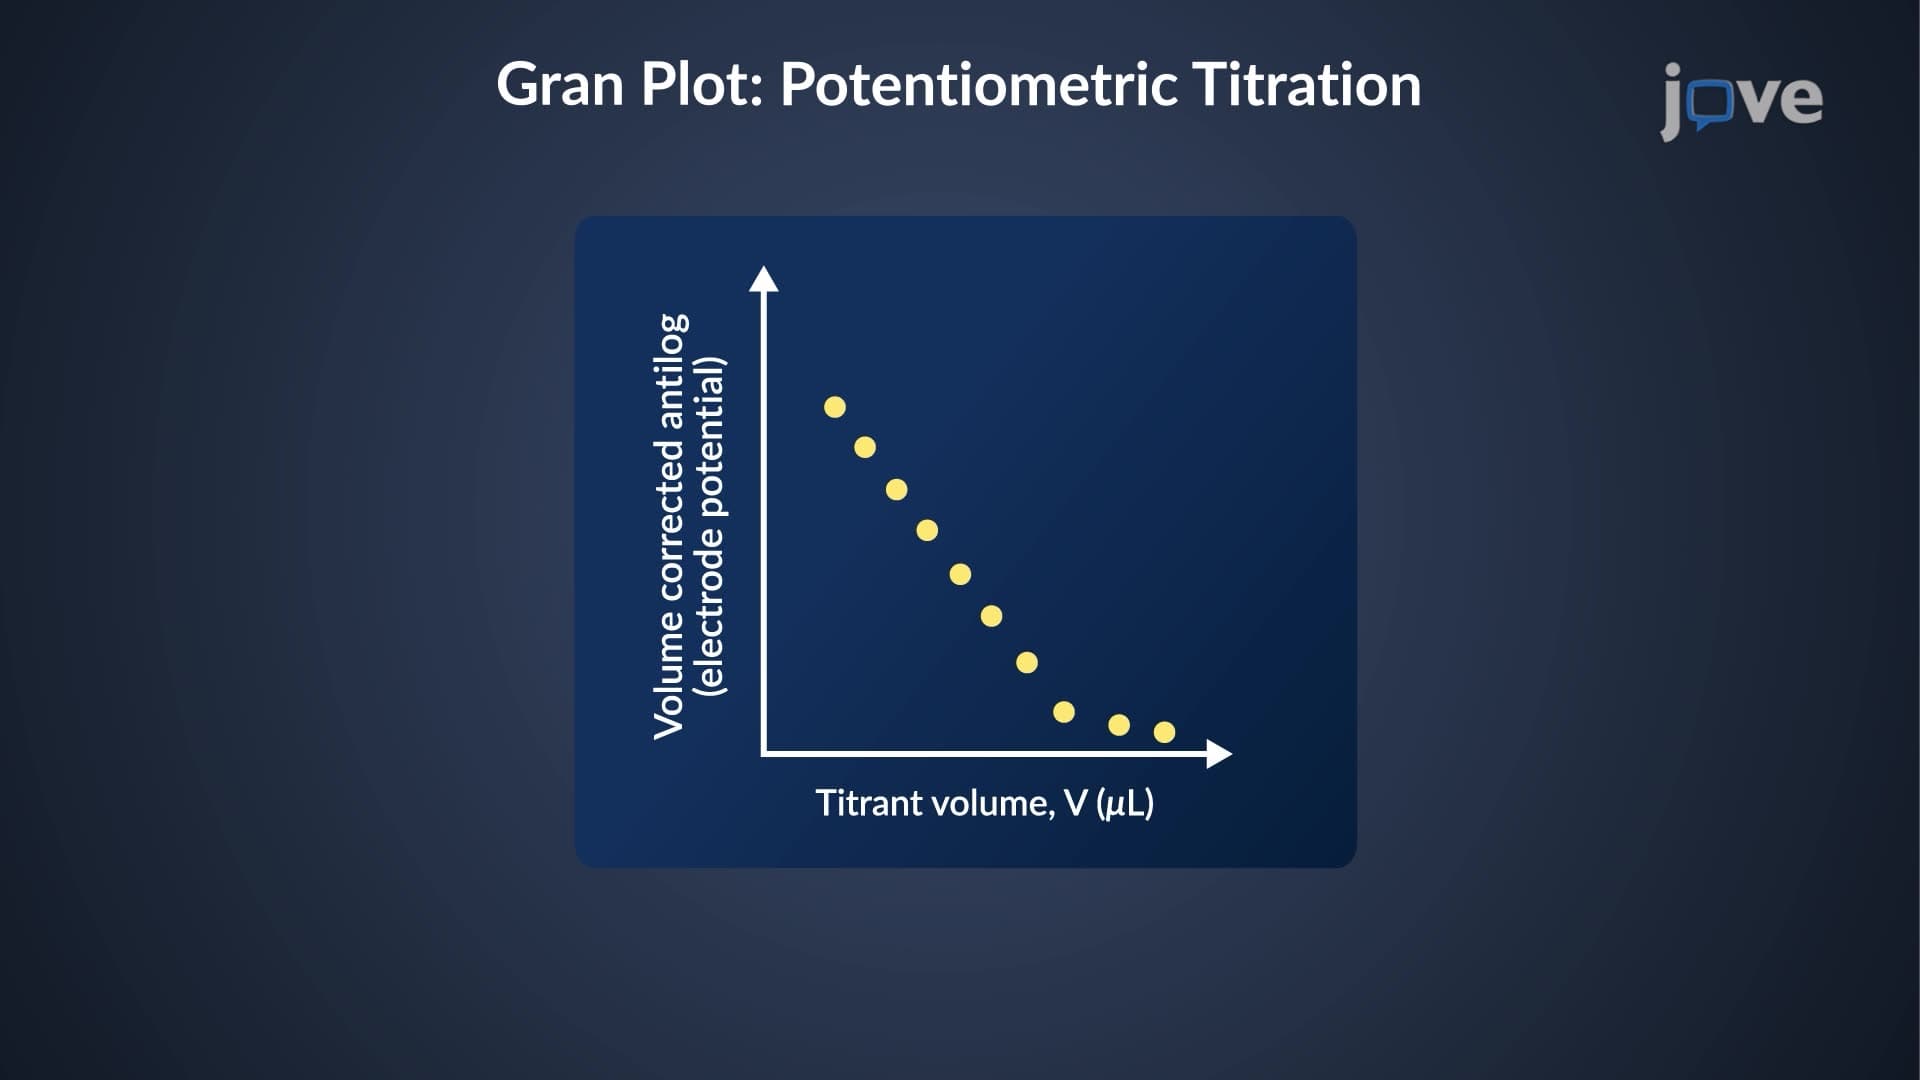
End Point Prediction: Gran Plot
For potentiometric titration, the Gran plot is created by plotting...
 01:10
Relative Motion Analysis - Acceleration