Related Experiment Video
Updated: Apr 13, 2026
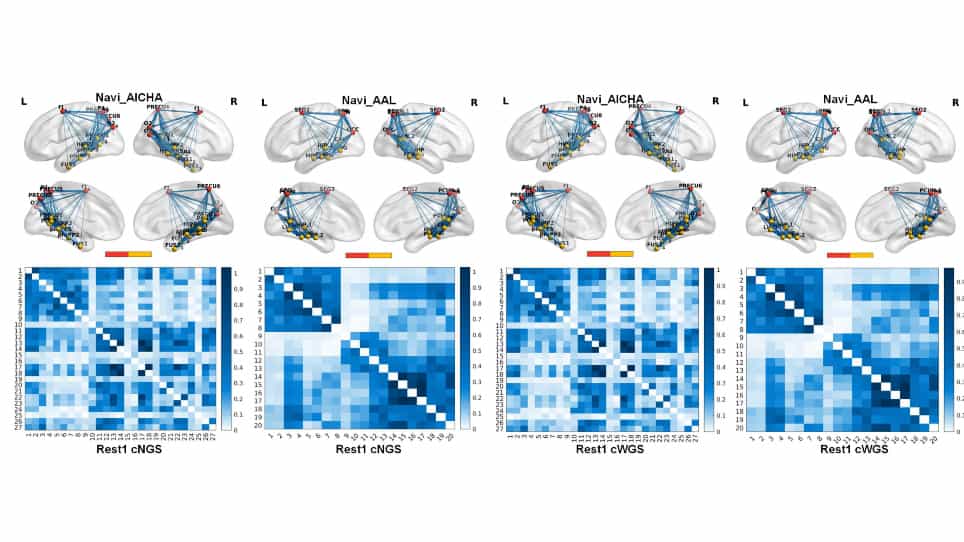
Modeling the Functional Network for Spatial Navigation in the Human Brain
Published on: October 13, 2023
Dual object graph and bisimulation metric for object-goal navigation in unfamiliar environment
Yiyue Meng1, Chi Guo2, Aolin Li3
1GNSS Research Center, Wuhan University, Wuhan, 430079, China; Electronic Information School, Wuhan University, Wuhan, 430079, China.

Abstract:
Object-goal navigation aims to guide an agent to find a specific target object in an unfamiliar environment based on first-person visual observations. It requires the agent to learn informative visual representations and robust navigation policy. To promote these two components, we propose two complementary techniques, dual object graph (DOG) and bisimulation metric (BM). DOG integrates current and historical object relationships, including category proximity and spatial correlation. It constructs a current object graph (COG) to model real-time object relationships and maintains a historical object graph (HOG) to preserve long-term object relationships. DOG improves visual representation learning. Both DOG and BM aim to improve robust navigation policy, enabling the agent to escape from deadlock states, such as looping or getting stuck. Specifically, BM is a self-supervised reinforcement learning (RL) technique that groups behaviorally similar observations in representation space. In the process, BM learns robust latent representations that capture only the task-relevant information from observations against distractions such as variations in background or viewpoint, thus providing guidance for effective navigation policy. Experiments in the AI2-Thor and RoboThor environment demonstrate that our method significantly improves the effectiveness and efficiency of navigation in unfamiliar environments, and real-world deployment further validates its transferability.
More Related Videos

Related Concept Videos
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:05
Collisions in Multiple Dimensions: Introduction
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:10
Design Example: Measuring Distance Between Two Points with Obstructions