Related Experiment Video
Updated: Apr 25, 2026

Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
Composite super-twisting control of an underactuated crane with partial-state measurements under parameter
Muhammad Auwal Shehu1, Ahmad Bala Alhassan1, Zaharuddin Mohamed2
1Department of Robotics and Mechatronics, School of Engineering and Digital Sciences (SEDS), Nazarbayev University, 53 Kabanbay Batyr Avenue, Astana, 010000, Kazakhstan.

Abstract:
This work proposes a composite adaptive-gain sliding mode observer-based super-twisting control with integral sliding mode control (ASMO-STC-ISMC) strategy for sway damping and motion control of a crane system with only partial state availability. The technique integrates an adaptive-gain sliding mode observer (ASMO) with a robust state estimation scheme to accurately reconstruct unmeasured states and enable effective control synthesis. The proposed scheme is validated under various operational conditions and comparative benchmarks conducted with various case studies involving both experimental and simulation investigations. Moreover, control application experiments on a lab-scale crane confirm the superior robustness and adaptability of the proposed method compared to conventional sliding mode control (SMC) methods, model-free proportional derivative SMC (PDSMC) and prescribed performance control-based SMC (PPC-SMC). Experimental results demonstrate that the ASMO-STC-ISMC achieves a settling time of 3.4 s, representing a 47.7% reduction relative to the PDSMC method and superior convergence over the PPC-SMC benchmark. Furthermore, under ±50% cable length variations, the system maintains a maximum payload sway below 2.3∘, while friction compensation eliminates steady-state positioning errors, confirming the strategy's effectiveness for high-precision industrial crane applications.


Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:13
Angle of Twist: Problem Solving
 01:14
Stability of structures
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
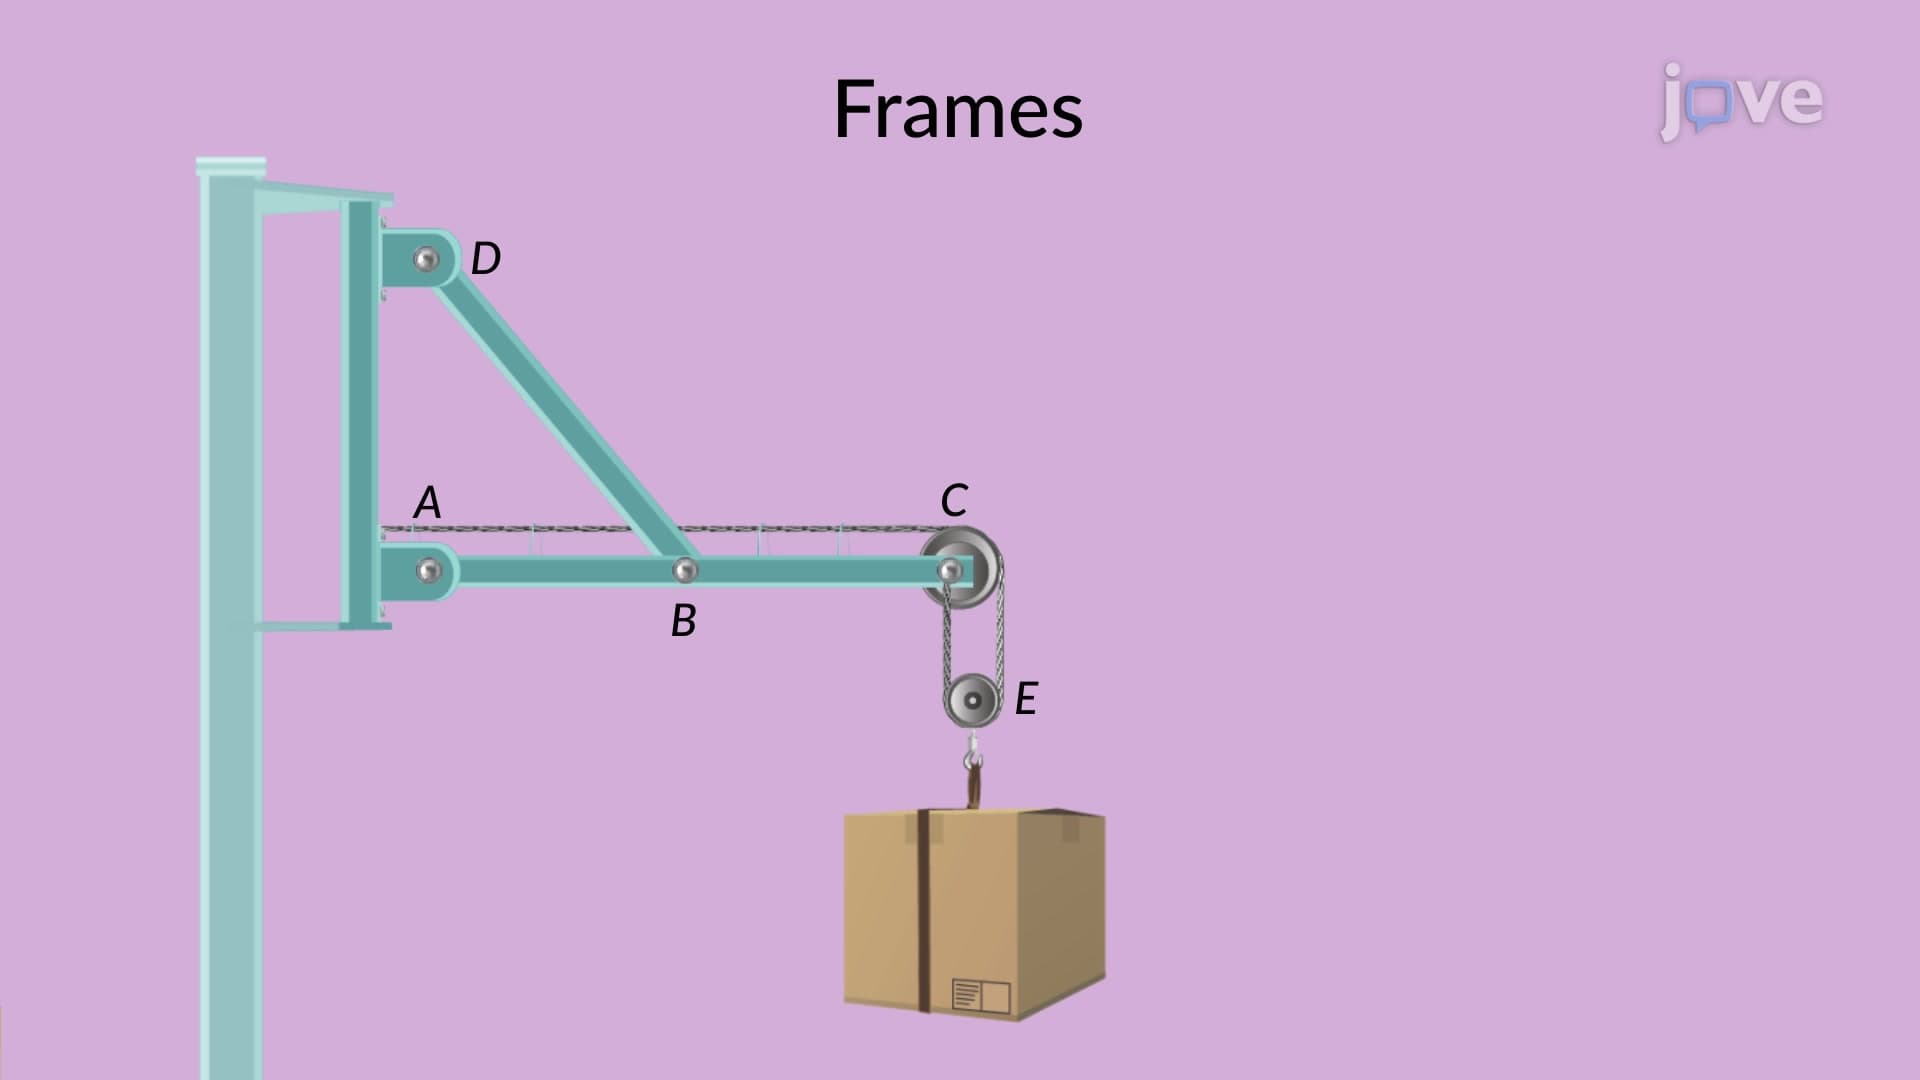
Frames: Problem Solving I