Related Experiment Video
Updated: Apr 25, 2026
Three-dimensional Particle Tracking Velocimetry for Turbulence Applications: Case of a Jet Flow
Published on: February 27, 2016
Physics-constrained mixture density networks for the inverse problem of Risley prism beam steering

Abstract:
Risley prism scanners require fast inverse mapping from screen coordinates to prism angles, yet the mapping is non-unique and unstable under non-paraxial, thick-prism conditions. This paper presents a physics-constrained mixture density network for the inverse problem of Risley prism beam steering, enabling direct prediction of both prism rotation angles from screen coordinates without paraxial assumptions or auxiliary exit-ray sensing. The model learns a multi-modal von Mises mixture and embeds a high-precision forward ray model in the loss, followed by one-step GN/LM refinement. Simulations demonstrate that, over the main region of the screen, the method achieves >94% correct-solution identification, micrometer-level reprojection RMSE, and millisecond-level inference with improved boundary and moderate-noise robustness. These results support the feasibility of the proposed method for real-time, high-precision pointing control in rotating double-prism systems.
Related Concept Videos
 01:15
Prismatic Beams: Problem Solving
The design begins with analyzing the beam as a free body to identify moments and force balances, thereby determining support reactions. Next, the...
 01:23
Design of Prismatic Beams for Bending
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:14
Shearing Stresses in a Beam: Problem Solving
 01:18
Newtonian Fluid: Problem Solving
A velocity gradient forms within the fluid when a Newtonian fluid is placed between two parallel plates, with...
 00:49
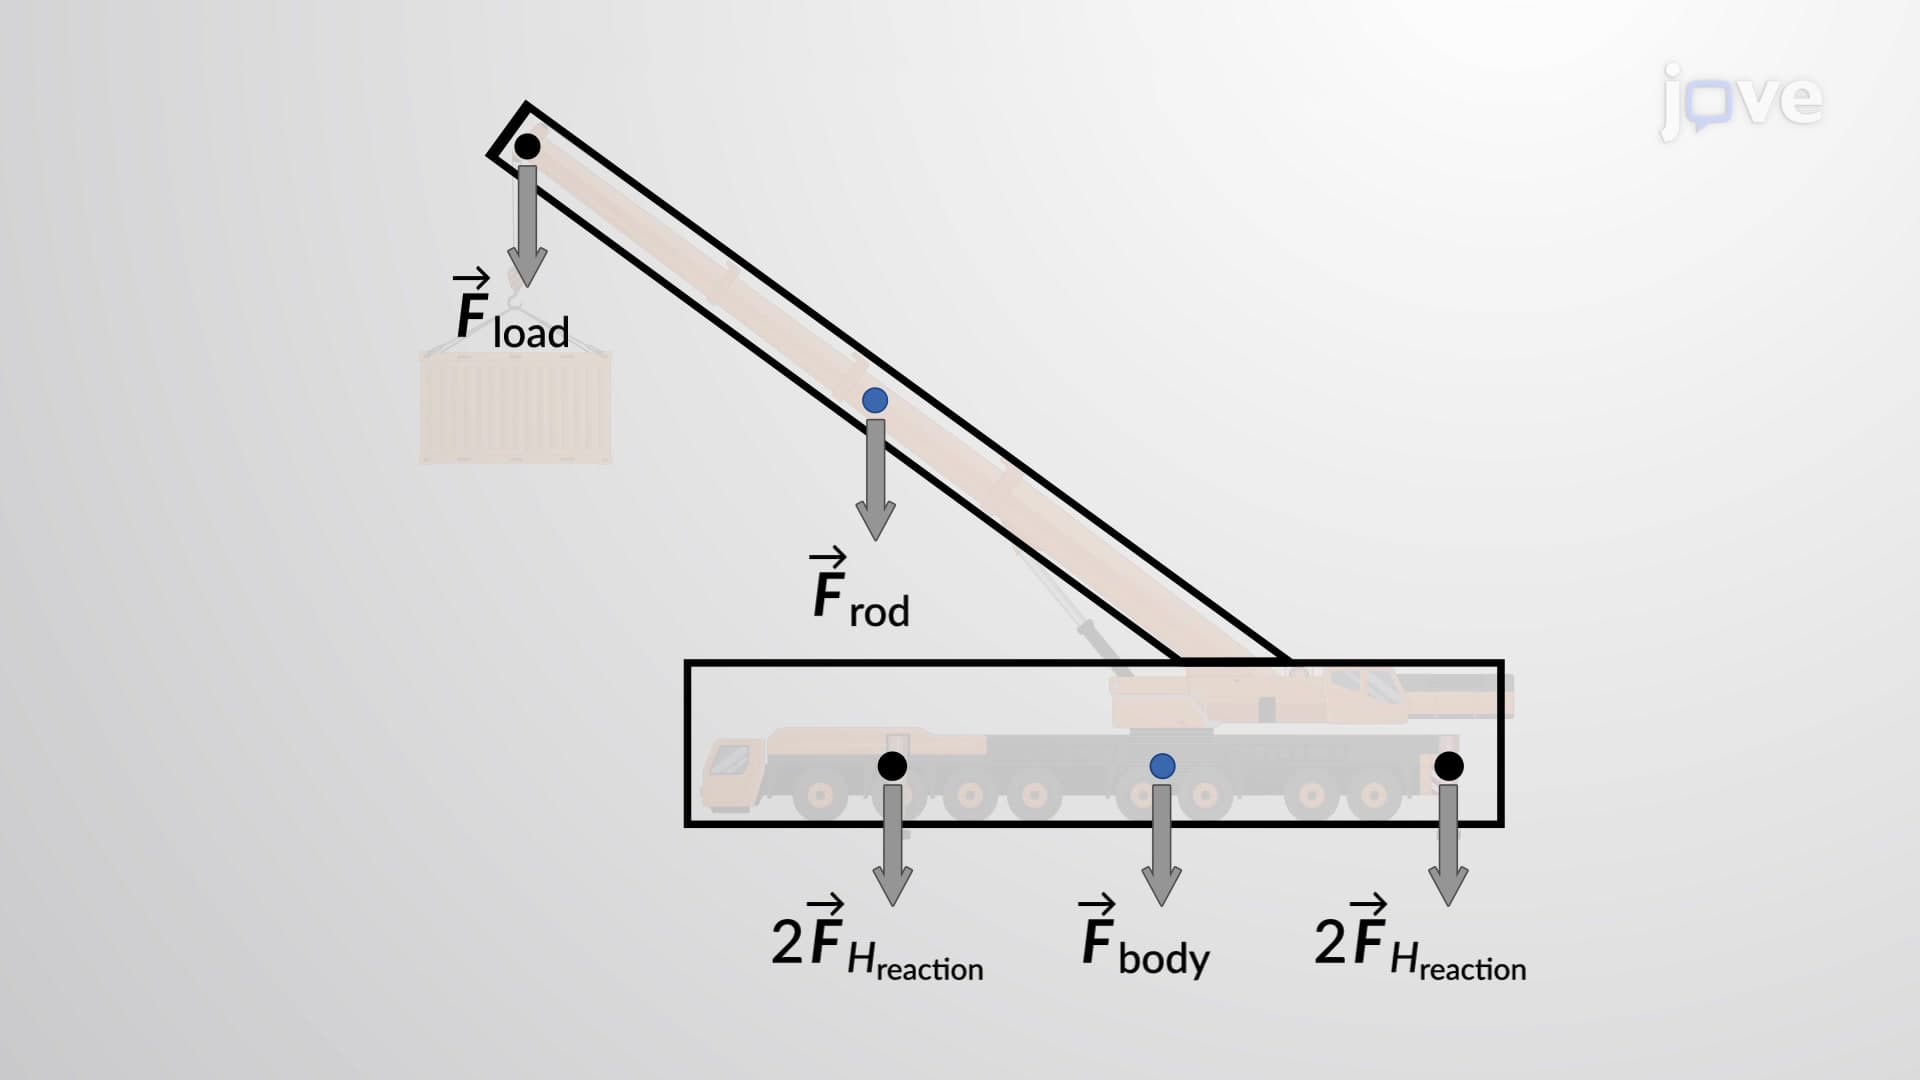
Rigid Body Equilibrium Problems - I