Related Experiment Video
Updated: May 6, 2026
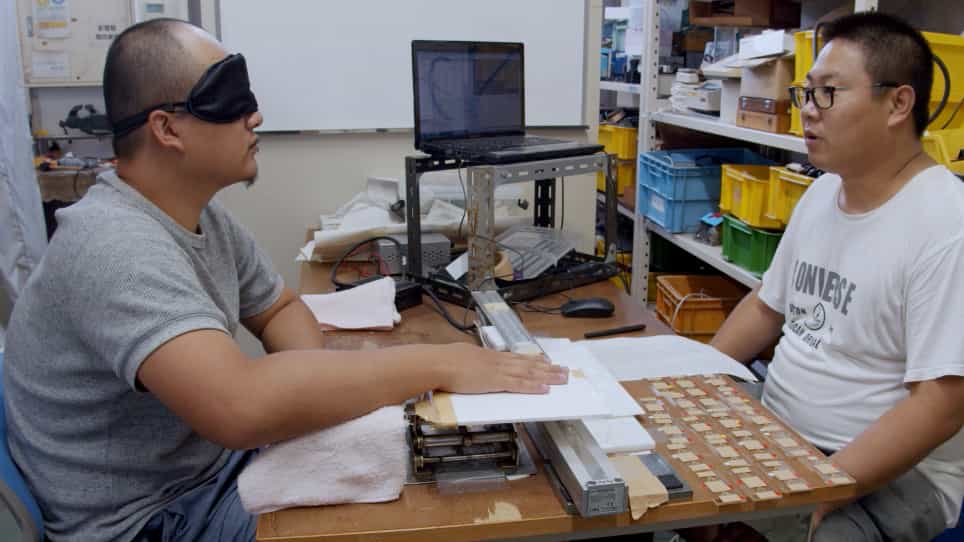

Tactile Semiautomatic Passive-Finger Angle Stimulator TSPAS
Published on: July 30, 2020
Single human fingertip mechanoreceptive afferents simultaneously encode multidimensional aspects of touch
Victoria Ashley Lang1, Helena Backlund Wasling1, Rochelle Ackerley1,2
1Department of Physiology, Institute of Neuroscience and Physiology, University of Gothenburg, Göteborg, Sweden.

Abstract:
Touch using the hands is essential for recognising surface features and manipulating objects, where different aspects are encoded by four main types of low-threshold mechanoreceptors (LTMs) in glabrous skin. Although factors such as movement, vibration and pressure are often studied individually, touch requires their integration to produce complex sensations. We investigated these processes jointly by recording single-unit activity via microneurography from human LTM afferents in the median nerve as periodic gratings slid across their receptive fields, varying the normal force and sliding velocity per trial. Mixed-effects models revealed that fast-adapting type 1 (FA-1) afferent firing was influenced by all three stimulus dimensions - force, velocity and spatial period. Slowly adapting type 1 (SA-1) afferent firing was driven primarily by force and, to a lesser extent, velocity. These findings support the view that FA-1 afferents encode stimulus intensity in an approximately linear manner, while SA-1 afferents function mainly as force detectors, demonstrating that mechanoreceptive afferents provide a complementary and multidimensional representation of the stimulus features during sliding contact. This distributed encoding expands the notion that LTMs are dedicated to single stimulus features, suggesting that tactile information is represented across LTM populations where each class contributes differently weighted inputs to capture skin-object interactions. KEY POINTS: Mechanoreceptors in the skin are divided into different classes that respond well to various aspects of touch, such as pressure and vibration. We recorded directly from low-threshold mechanoreceptors in human peripheral nerves while different dynamic stimuli were moved across their receptive fields, changing the velocity, force and spatial period. Computational modelling of fingertip mechanoreceptor responses showed multiplexity in their encoding strategy, yielding partial convergence in feature representation across afferent classes. The study expands our knowledge on how touch is encoded, where information is represented across mechanoreceptor populations and each class contributes differently weighted inputs to capture skin-object interactions.
More Related Videos
Related Concept Videos
 01:33
Somatosensation
 01:16
Sensory Functions of the Skin
There are two main categories of receptors on the skin: capsulated and non-capsulated. The non-capsulated ones are mainly the pain receptors. The capsulated ones can be further categorized based on the...
 01:26
Introduction to Special Senses
 01:11
Sensory Perception: Organization of the Somatosensory System
The receptor level:
The receptor level is the first stage of sensation. It involves the detection of a stimulus by specialized sensory receptors. The stimulus must arrive within the receptor's receptive field. Next, the receptor converts the energy of the...
 01:27
Tactile and Chemical Senses
 01:28
Major Somatic Sensory Pathways