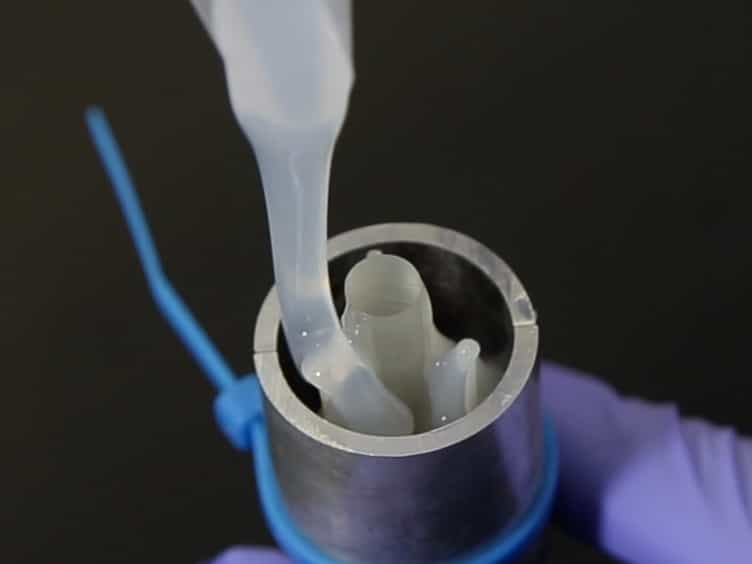
A compliant granular jamming gripper for improved robot-assisted surgical instrument handling
Related Experiment Video
Updated: Nov 1, 2026
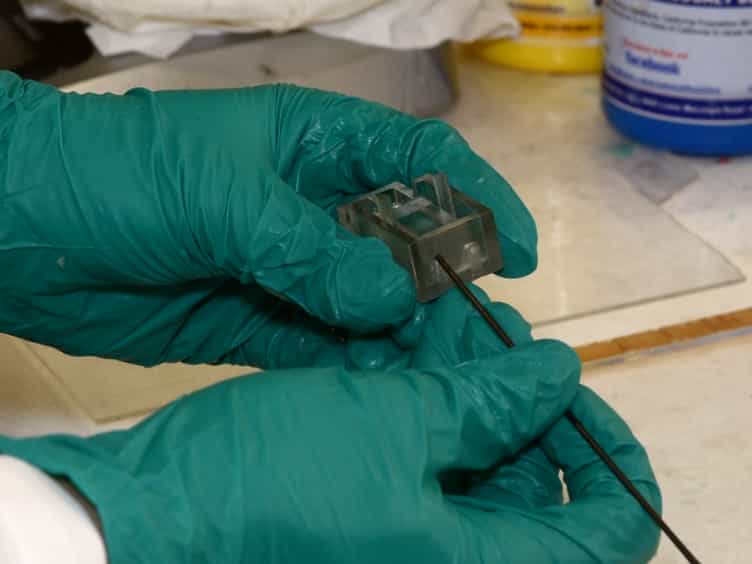
Rod-based Fabrication of Customizable Soft Robotic Pneumatic Gripper Devices for Delicate Tissue Manipulation
Published on: August 2, 2016
Sonja Lubitz1, Peter P Pott2, Max B Schäfer3
1Institute of Medical Device Technology, University of Stuttgart, Pfaffenwaldring 9, 70569, Stuttgart, Germany. papers@imt.uni-stuttgart.de.

Purpose:
Granular jamming grippers (GJGs) offer high geometric adaptability and intrinsic safety for robot-assisted surgical instrument handling but struggle with thin, planar instruments. This study investigates whether external pinching through a passive and partly compliant force-leveraging linkage can enhance grasping performance while maintaining a compact and simple design.
Methods:
The SCIP-GRIP, a novel GJG with an integrated Scott-Russell linkage to convert vertical down force into horizontal pinching, was developed. The performances of three gripper versions with varying pinching heights were compared to that of a non-pinching GJG across three instrument types: scalpel (flat), forceps (vertical surfaces), and scissors (undercuts). Both, holding forces and pickup success rates were evaluated using a Universal Testing Machine. Holding forces were measured 12 times per case, while success rates were assessed over 50 trials each.
Results:
Pinching improves performance across all instruments, with the largest gains observed for scissors, achieving holding forces above 10 N. For forceps and scalpels, only the lowest pinching height yields significant improvements. Success rates for scissors and forceps remain at 100 %, while scalpel success improves from 4 % to 18 % only at low pinching height. Higher pinching heights fail consistently. Performance strongly depends on pinching height, with increased height reducing effectiveness.
Conclusion:
The SCIP-GRIP demonstrates that a passive Scott-Russell linkage can enhance GJG performance while preserving simplicity and safety but pinching below 3 mm is necessary. The design achieves comparable performance to active systems at lower complexity, though further improvements are needed to reliably grasp flat geometries.