Related Experiment Video
Updated: May 15, 2026

Early Metamorphic Insertion Technology for Insect Flight Behavior Monitoring
Published on: July 12, 2014
Approximate Optimal Control for Morphing Aircraft via Attention Meta-Learning and Continual Learning

Abstract:
This study presents an innovative approximate optimal controller for variable-span morphing aircraft (MA), where the mapping relationship between aerodynamic parameters and deformation parameters is unknown. The foundation of our approach relies on two core observations: unknown dynamic models for MA have a common representation across different morphing scenarios, while the specific morphing condition lies in a collection of adaptive linear parameters. Guided by this dual-layer decomposition, a novel meta-learning (MetaL) training structure with an adversarial optimization framework is leveraged to extract common invariant features from offline flight data. At the same time, we incorporate the squeeze-and-excitation (SE) network, a novel architectural unit, into the MetaL training process, aiming to enhance the network's representational capability through dynamic recalibration of channel features. Regarding the new deformation situations encountered during the online process, online data are collected to update the common features via a continual learning method, and a concurrent learning (ConcL)-based methodology is introduced to update the linear coefficients. Utilizing the identified dynamical model, a model-based reinforcement learning (RL) framework is formulated to address optimal control problems of MA. By employing nonsmooth Lyapunov stability analysis, it is demonstrated that continuously updating the weights allows the implemented control strategies to converge to a neighborhood of the optimal strategies. Furthermore, numerical simulations are performed to validate the effectiveness of the proposed methodology.
Related Concept Videos
 01:29
Application of Linearization and Approximation
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:12
Observational Learning
 01:10
Control Systems
At the heart...
 01:23
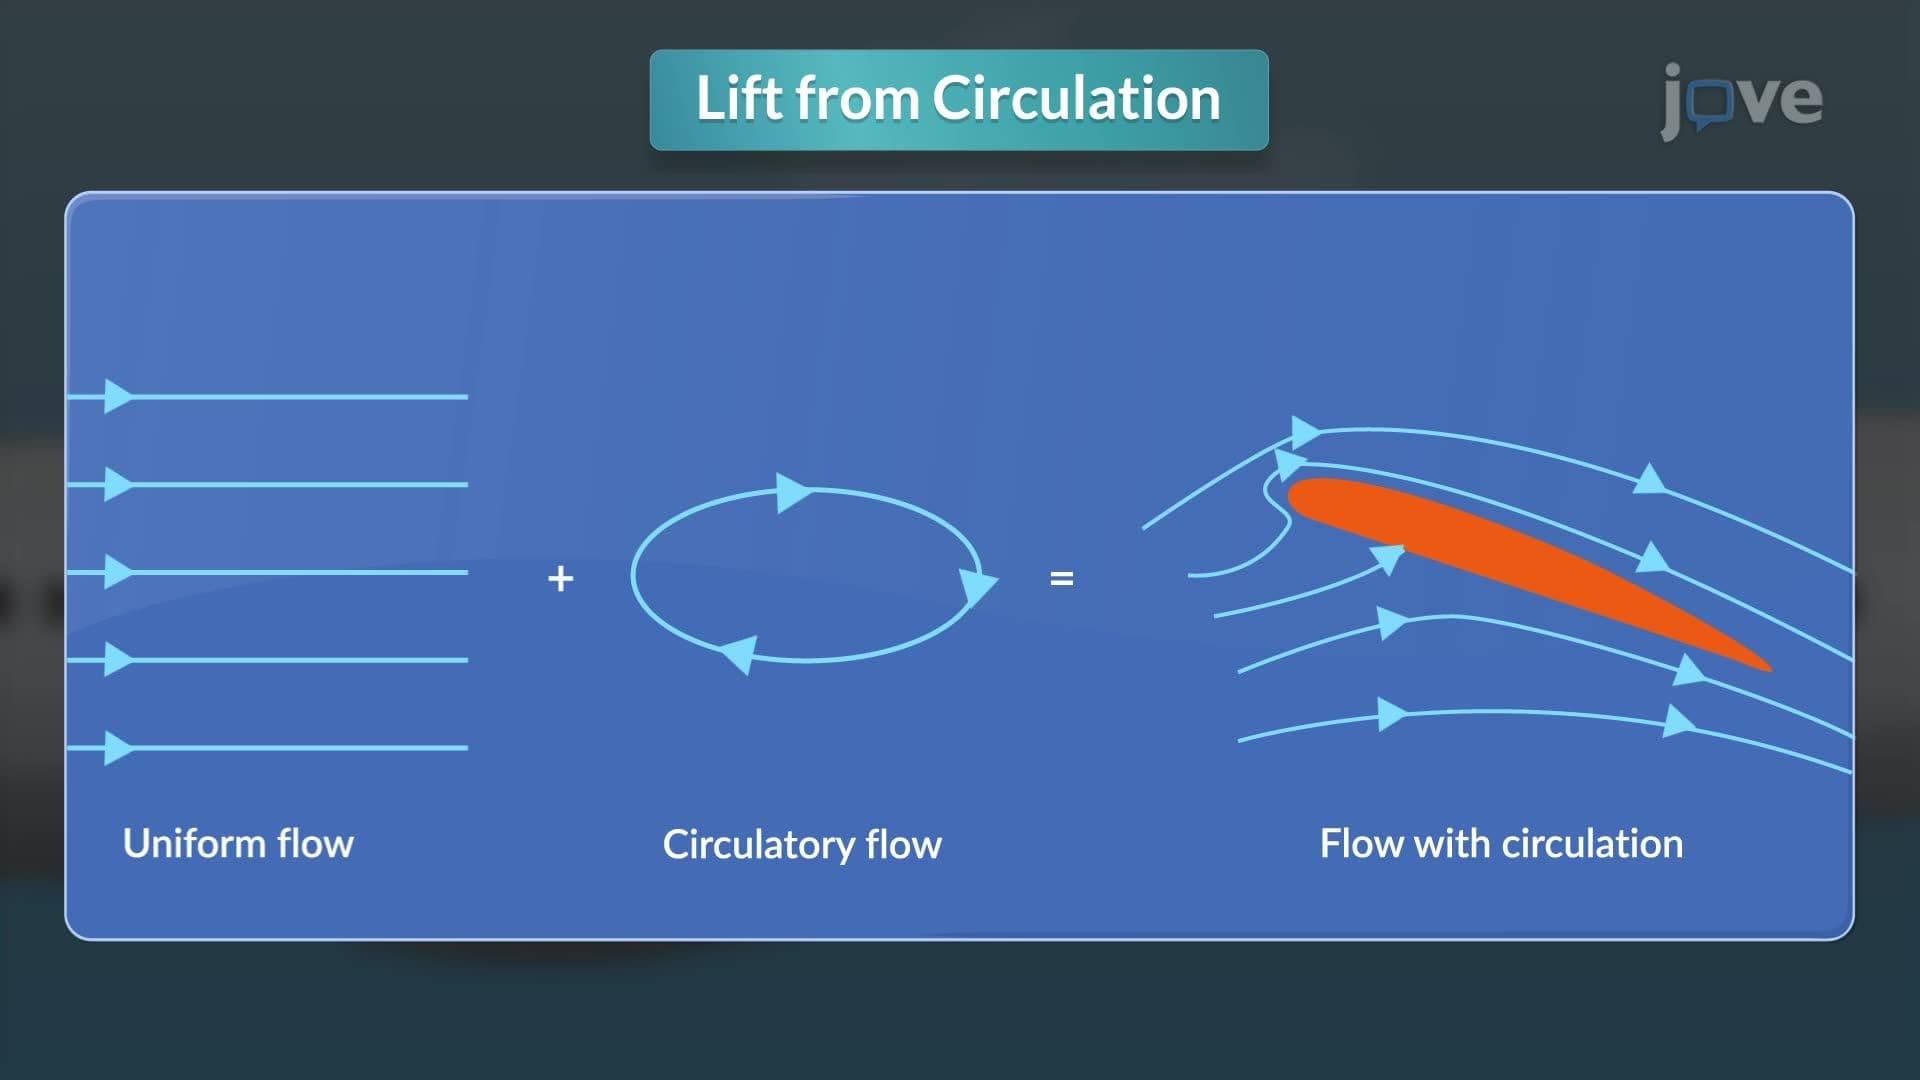
Lift
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...