Related Experiment Video
Updated: May 17, 2026
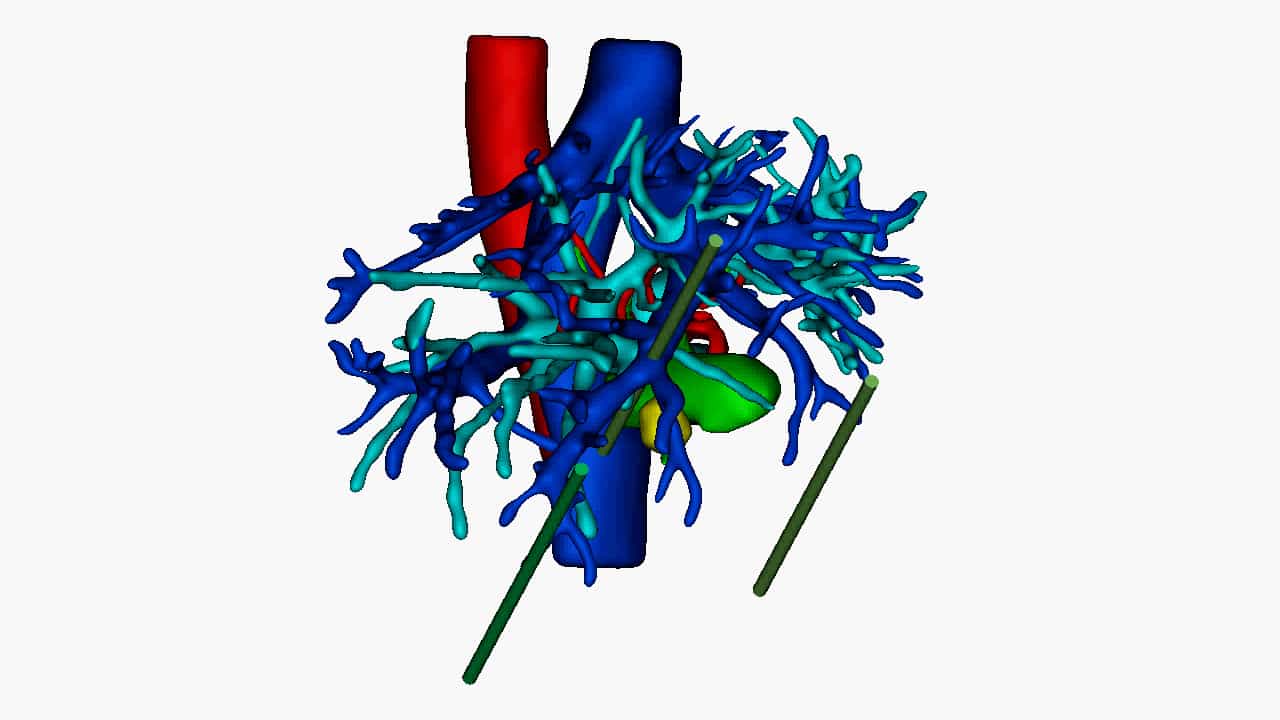

Three-dimensional Location Approach with Silk Thread Guided Laparoscopic Segmentectomy for Liver Tumor
Published on: May 23, 2025
Laparoscopic liver point cloud registration via hyperbolic-topology interaction
Yixuan Wang1,2, Yue Dai1,2, Xiangyue Yang2,3
1College of Information Science and Engineering, Northeastern University, Shenyang, China.

Purpose:
In laparoscopic liver resection, precise registration between preoperative 3D models and intraoperative laparoscopic point clouds remains challenging due to liver deformation, respiratory motion, and limited visibility. This study aims to develop a robust registration method achieving stable alignment under low-overlap and non-rigid conditions.
Methods:
We propose a novel framework centered on a Hyperbolic-Topology Interaction Module. The module maps rotation-invariant features extracted by the backbone into hyperbolic space, leveraging its negative curvature to amplify subtle geometric differences, while simultaneously constructing a topological graph that propagates spatial relationships to enhance feature consistency. Finally, based on the refined features, a coarse-to-fine matching strategy combined with a hypothesis generation mechanism establishes robust correspondence estimation.
Results:
Evaluation of our method with comparative methods on both simulated and real datasets shows that our method achieves state-of-the-art results. On the public DePOLL dataset, our method achieved the lowest surface target registration error (TRE) of 6.2 mm and the lowest internal TRE of 7.0 mm. Additional non-rigid experiments further validate the strong generalization capability of the proposed features under varying deformation conditions.
Conclusion:
The proposed method effectively combines local geometric discrimination with global topological reasoning, achieving notable gains in accuracy, robustness, and efficiency. It delivers reliable rigid initialization for augmented reality (AR)-guided resection navigation and establishes a solid foundation for subsequent non-rigid estimation, demonstrating strong potential for clinical use.
More Related Videos
 10:25
Technical Approach for Infrared Tracking for Soft Tissue Navigation with a Holographic Head-Mounted Display and Preclinical Validation
Published on: September 2, 2025
 06:45
A Mouse Model of the Associating Liver Partition and Portal Vein Ligation for Staged Hepatectomy Procedure Aided by Microscopy
Published on: January 19, 2024