Related Experiment Video
Updated: May 17, 2026
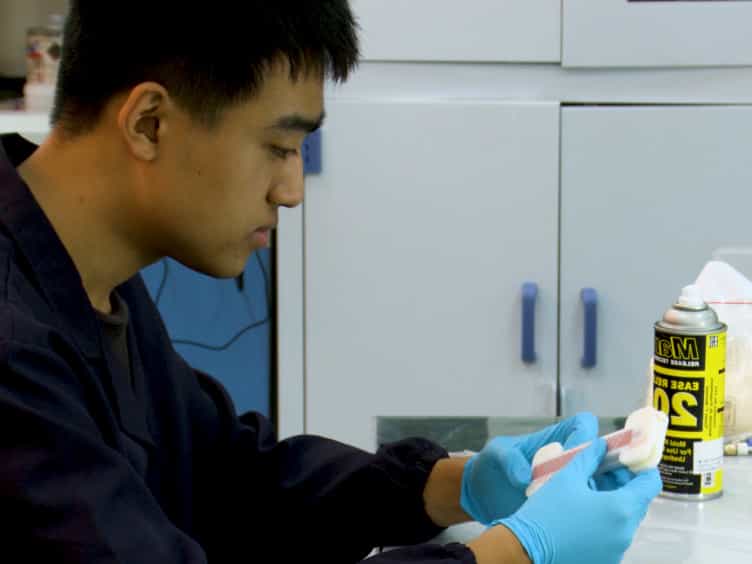

Fabrication of Soft Pneumatic Network Actuators with Oblique Chambers
Published on: August 17, 2018
Tailoring silicone mixtures for soft robotics: predictive modeling and experimental validation in pneumatic soft
Daniel Johnson1, Trevor Wayne Exley1, Marc Torres1
1Advanced Robotics Manipulators (ARM) LAb, Department of Biomedical Engineering, University of North Texas, Denton, TX, United States of America.

Abstract:
The development of soft robotics hinges on the ability to tailor material properties to meet specific application requirements. This study investigates the mechanical behavior of silicone mixtures and their application in pneumatic soft actuators. A comprehensive experimental methodology was used to evaluate 15 silicone combinations, focusing on Young's modulus, fracture stress, and fracture strain. Through an ordinary least squares regression analysis of the resulting Young's Moduli, we identified key predictors and interactions that govern material properties, achieving anR2value of 0.932 and an adjustedR2of 0.762. Stress-strain analyses revealed a broad range of achievable Young's Moduli (0.098-0.428 MPa), fracture stress (0.015-1.093 MPa), and fracture strains (0.984-5.145). To validate these findings, three pneumatic actuators were fabricated using silicone mixtures with varying strain-limiting layers. Their performance, evaluated by bending angle measurements under incremental air injection, showed significant differences, underscoring the importance of material selection in actuator design. Actuators with low modulus, high strain mixtures achieved greater bending angles, making them ideal for applications requiring high flexibility. These results establish a framework for systematically designing and optimizing silicone mixtures for soft actuators, offering insights into their mechanical behavior and practical implications in soft robotics. This work advances the field by providing a detailed understanding of material-property relationships and their role in achieving precise actuation in soft robotic systems.

