Related Experiment Video
Updated: May 19, 2026


Operation of the Collaborative Composite Manufacturing (CCM) System
Published on: October 1, 2019
Friction Modeling of Tendon-driven Continuum Robots through Linear Complementarity Problem
Jia Shen1, Brendan Browne2, Junhyoung Ha3
1George W. Woodruff School of Mechanical Engineering, Georgia Institute of Technology, Atlanta 30332 USA.

Abstract:
Tendon-driven continuum robots (TDCR) are widely used in medical interventions due to their inherent dexterity and compliance. However, precise motion planning and control of these robots remain challenging, largely because existing models do not accurately capture tendon frictional hysteresis. Predicting this friction-induced hysteresis has been recognized as an open problem due to the complex physics of tendon-disk interactions. In this letter, we propose a novel friction modeling approach for TDCR by incorporating the Capstan friction model as a set of complementarity constraints. Unlike conventional approaches that only predict the bounding effect of sliding friction, the proposed model captures the continuous change in tendon-disk friction forces and the transition between tendon sticking and sliding, thereby enabling the prediction of friction-induced hysteresis. The friction model is further formulated as the complementarity problem for convenient numerical implementation. We experimentally validated our approach on a simplified TDCR prototype and demonstrated a reduction of tip position error from 36.11 mm in conventional sliding friction models to 9.42 mm for a 402-mm-long robot. The source code is available at https://github.com/Jia0Shen/Friction-TDCR-Tension.
Related Concept Videos
 01:23
Simplification of a Force and Couple System: II
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:18
Simplification of a Force and Couple System I
 01:05
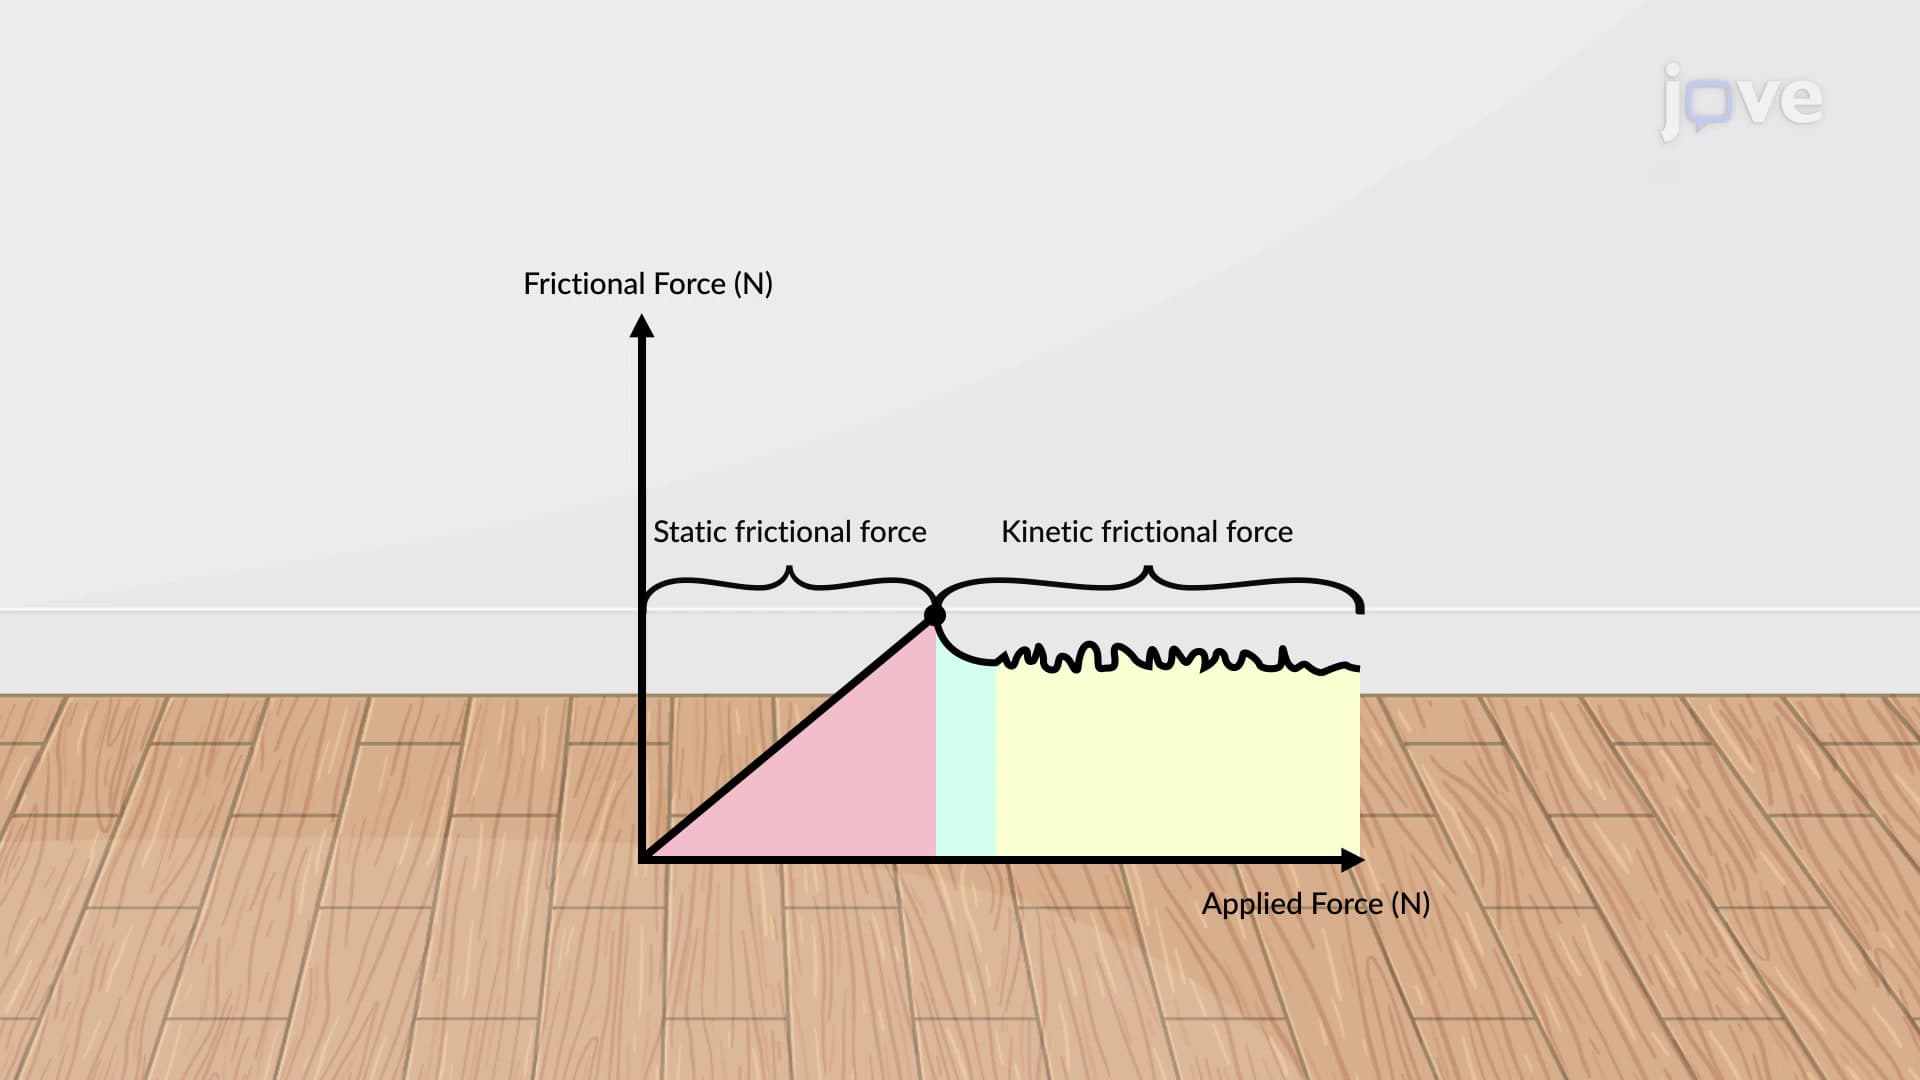
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:15
Kinematic Equations: Problem Solving