Related Experiment Video
Updated: May 28, 2026
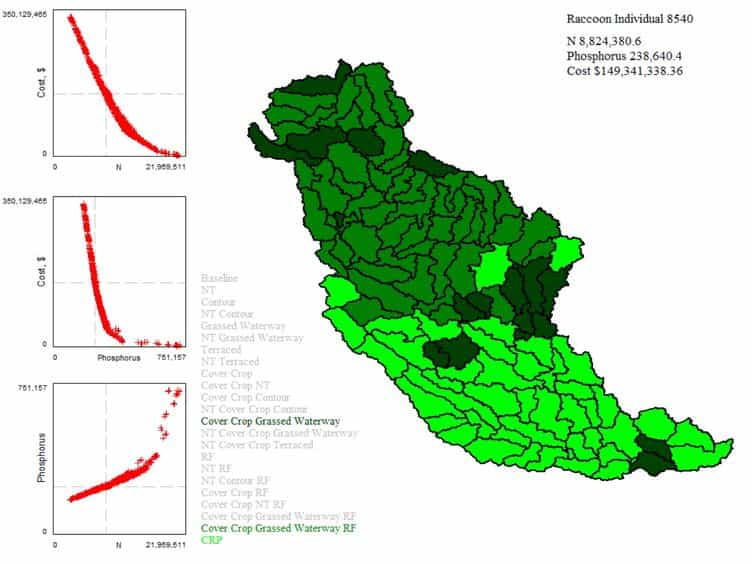

Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
Multi-strategy Sea Horse Optimization algorithm for UAV path planning
Amir Seyyedabbasi1, Bahman Arasteh2,3, Ahmet Gurhanli4
1Computer Engineering Department, Istinye University, Istanbul, Türkiye.

Abstract:
Unmanned aerial vehicle (UAV) path planning is a challenging constrained optimization problem and a key component of autonomous navigation. Traditional optimization techniques frequently encounter difficulties in handling the complex constraints of UAV path planning, and even metaheuristic algorithms may suffer from premature convergence to local optima. A modified variant of the Sea Horse Optimization algorithm (SHO), denoted as moSHO, is introduced for threat-aware UAV path planning. The proposed algorithm extends the original SHO's movement, predation, and reproduction mechanisms through three cooperative strategies. First, a fish-aggregating device (FAD) mechanism promotes behavioral diversity through adaptive, range-aware perturbations. Second, a best-worst position mutation (BWPM) operator applies fine-grained Gaussian adjustments to the best-performing individuals while simultaneously guiding the worst individuals toward the current best using a differential update with Cauchy perturbation. Third, quasi-reflection-based learning (QRBL) introduces quasi-opposite candidates to strengthen exploration and population diversity. The integration of these strategies strengthens the exploration capability without reducing exploitation, resulting in a more balanced optimization process. An evaluation of 23 benchmark functions demonstrates the robustness of moSHO. Moreover, experiments on the UAV path planning model under threat environments prove its reliability in identifying safe, feasible paths.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:29
Application of Linearization and Approximation
 01:28
Methods of Medium Optimization
 01:26
Orthogonal Trajectories
 00:48
Optimal Foraging
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...