Related Experiment Video
Updated: Jun 11, 2026
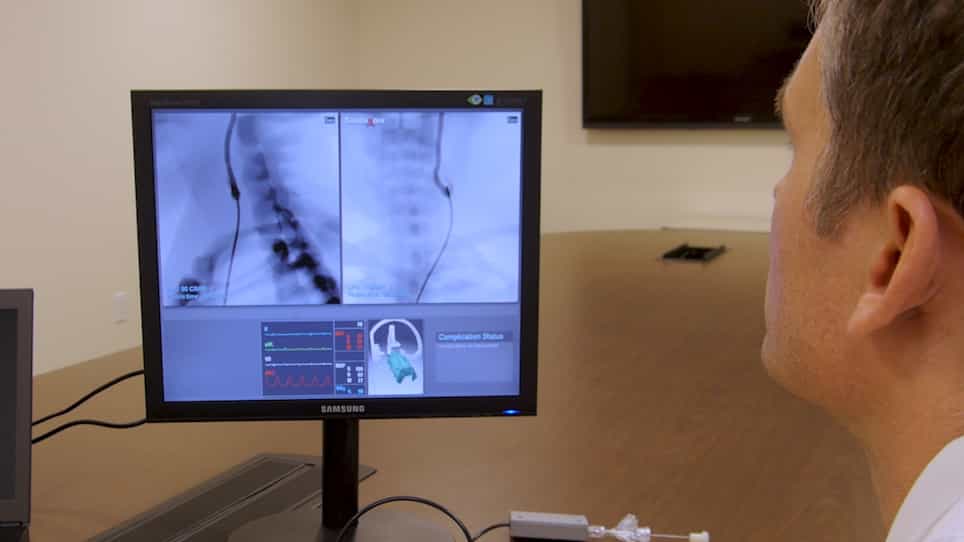

Simulator Training for Endovascular Neurosurgery
Published on: May 6, 2020
Catheter monitoring in intelligent endovascular navigation systems: interactive simulations and mixed reality for
Veronica Ruozzi1, Giovanni Battista Regazzo2, Maria Chiara Palumbo3
1Department of Electronics, Information and Bioengineering, Politecnico di Milano, Milan, Italy. veronica.ruozzi@polimi.it.

Purpose:
The aim is to develop and test a framework that integrates real-time catheter shape reconstruction, interactive simulations, and mixed reality visualization to enable accurate monitoring of catheter vessel interactions during endovascular navigation.
Methods:
A finite element model (FEM) of the venous pathway from the right femoral vein to the inferior vena cava was generated from computed tomography data and implemented into an interactive simulation. Catheter motion was imposed as boundary condition, and catheter vessel contact was modeled with a Lagrange multiplier formulation to compute vessel deformation. The framework was integrated and tested in vitro using a sensorized catheter with fiber Bragg grating and electromagnetic sensors to provide real-time 3D shape and location as it was advanced by a catheter driver through a silicone replica of the vascular anatomy. Upon registration, real-time sensor read-outs fed the simulation, and the updated catheter and vessel geometries were streamed to Hololens (HL2). The performance of the simulation and the accuracy of FEM-computed vessel wall displacement were validated vs. experimental ground truth obtained via stereo frames triangulation.
Results:
Complexity and extent of catheter vessel interaction affected FEM performance by increasing the computational cost. The simulated time exceeded the real temporal extent of the physical phenomenon by 12% during the initial navigation phase and by 45% when the catheter reached the most tortuous portion of the vessel. The HL2 rendering remained stable between 35 and 40 frames per second. Across these two phases, the median relative displacement error between FEM-computed vessel wall displacements and the ground truth remained below 1 mm and 2.33 mm, respectively.
Conclusion:
The study demonstrates the feasibility of integrating interactive biomechanical simulation with real-time sensor data to enable continuous monitoring of catheter vessel interactions, with mixed reality visualization serving as a user interface to support a more engaged and better-informed operator throughout the navigation.
More Related Videos
 09:13
Remote Magnetic Navigation for Accurate, Real-time Catheter Positioning and Ablation in Cardiac Electrophysiology Procedures
Published on: April 21, 2013
 10:25
Technical Approach for Infrared Tracking for Soft Tissue Navigation with a Holographic Head-Mounted Display and Preclinical Validation
Published on: September 2, 2025