Related Experiment Videos
Feedback controlled adaptive time-stepping for energy preserving variational integration
Dong Xu1, Heyang Feng1, Xiaoguang Hu1
1School of Automation Science and Electrical Engineering, Beihang University, No. 37 Xueyuan Road, Beijing, 100191, China.

Abstract:
High-fidelity physical simulation is a cornerstone of embodied intelligence, yet simulating high-dimensional nonlinear multi-body systems involves a fundamental trade-off between numerical stability and computational efficiency. Conventional explicit integrators suffer from energy drift in long-horizon tasks. Conversely, symplectic variational integrators (VIs) often have high computational costs due to implicit constraints. To bridge the gap, this paper reformulates the step-size adaptation as a dynamic closed-loop feedback control process instead of a rigid root-finding problem, proposing a Control-Theory-Inspired Adaptive Time-step Variational Integrator (C-ATSVI). A Lyapunov-based controller is designed to ensure asymptotic stability of the energy error, augmented by the Internal Model Principle (IMP) to eliminate steady-state residuals caused by numerical truncation. Simulations on a low-dimensional 2-DoF pendulum, a high-dimensional 7-DoF pendulum and a 7-DoF manipulator with external force are conducted. Numerical results demonstrate that C-ATSVI achieves energy fidelity comparable to adaptive schemes, while maintaining computational efficiency similar to explicit fixed-step methods. Therefore, the proposed method offers a robust solution for analyzing complex Hamiltonian dynamics.
Related Concept Videos
 01:14
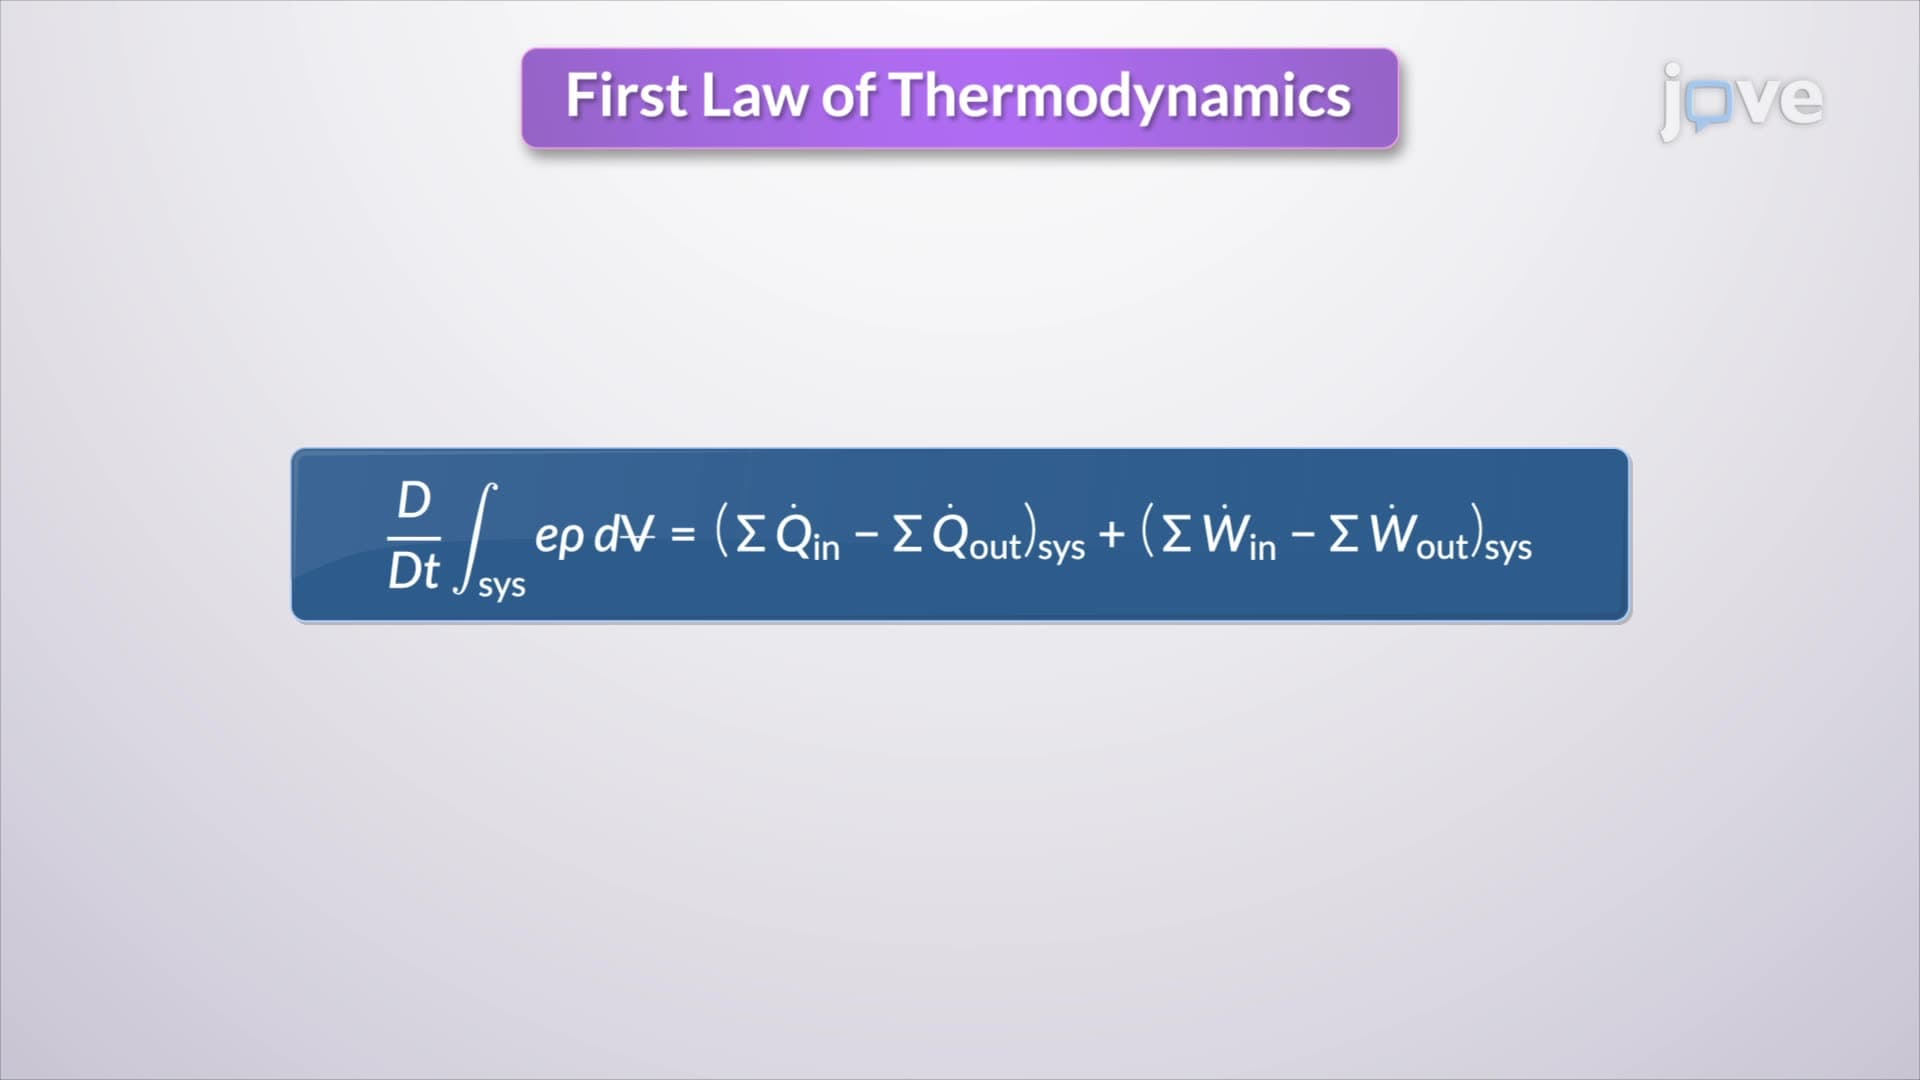
Conservation of Energy in Control Volume
For steady flow systems, the time derivative of the stored energy becomes zero since there is no energy accumulation within the control volume. This simplifies the energy equation to:
 01:10
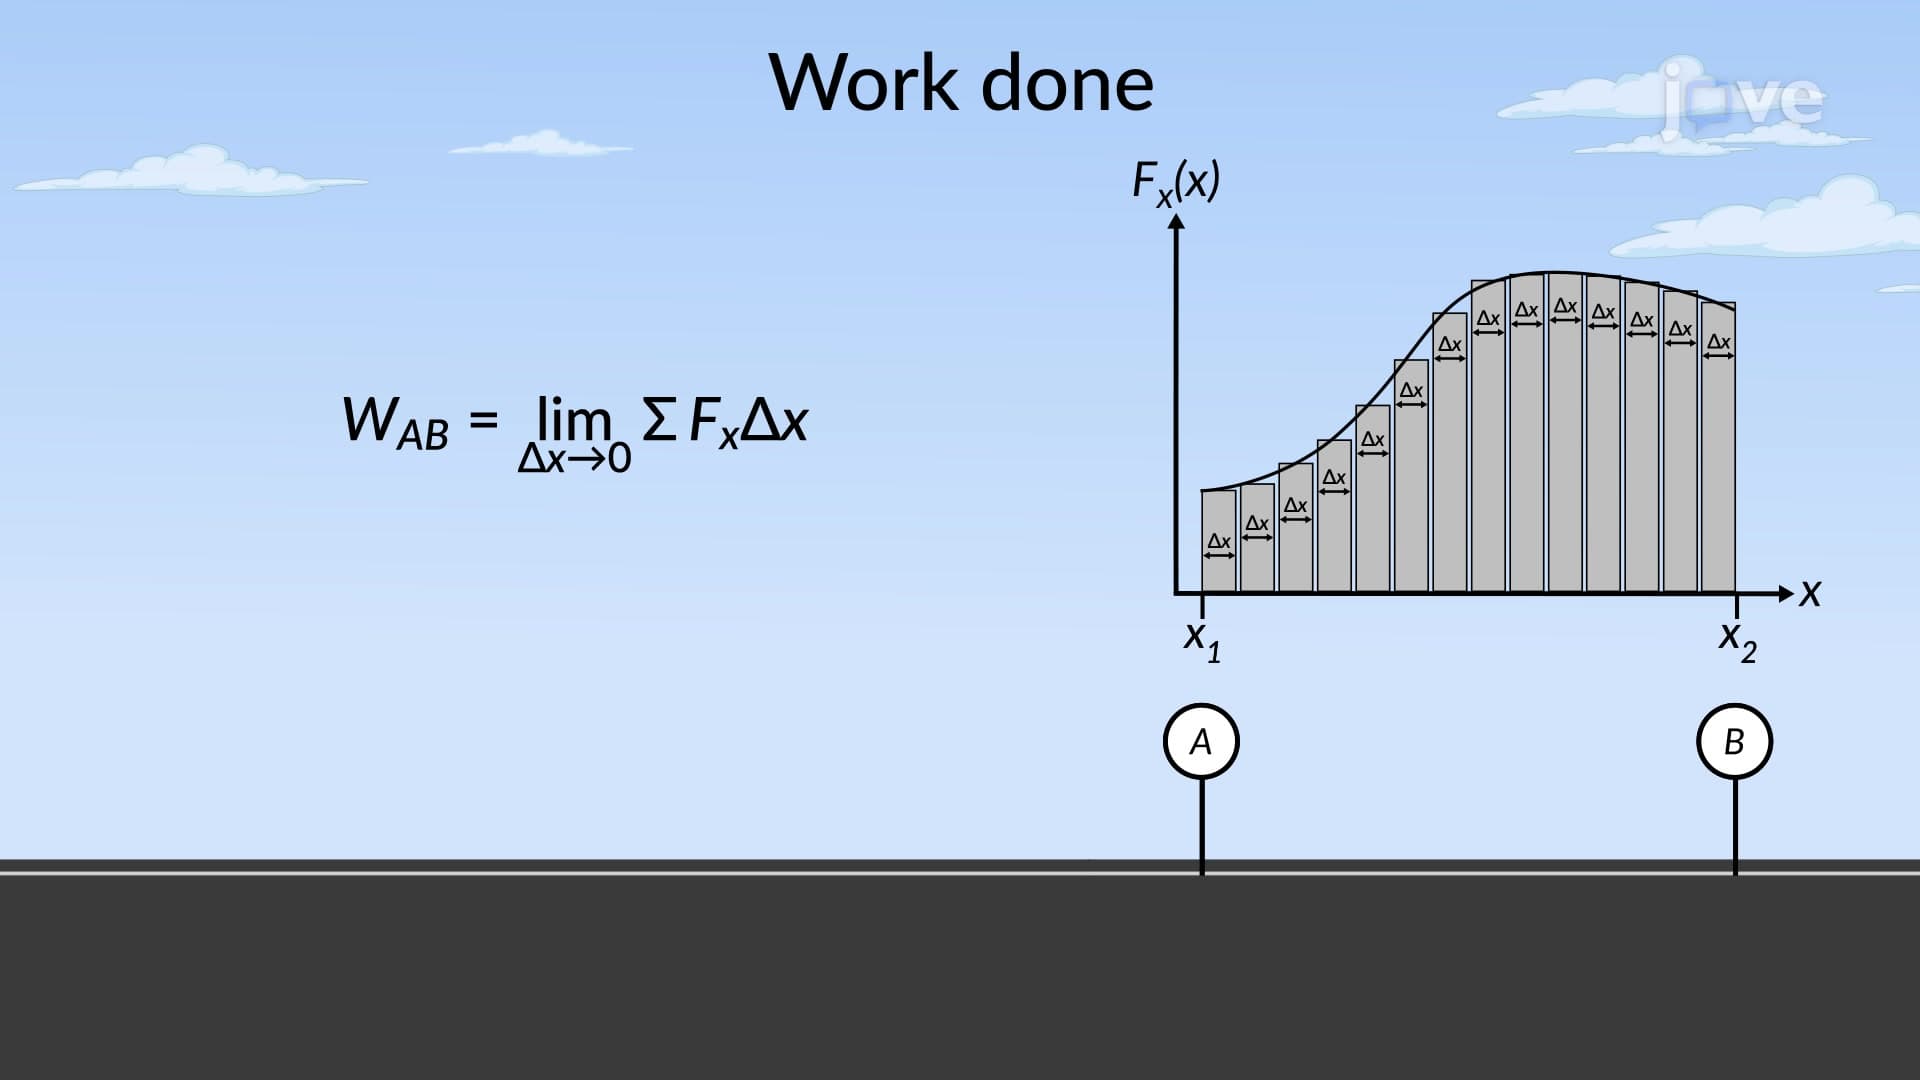
Work and Energy for Variable Forces
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
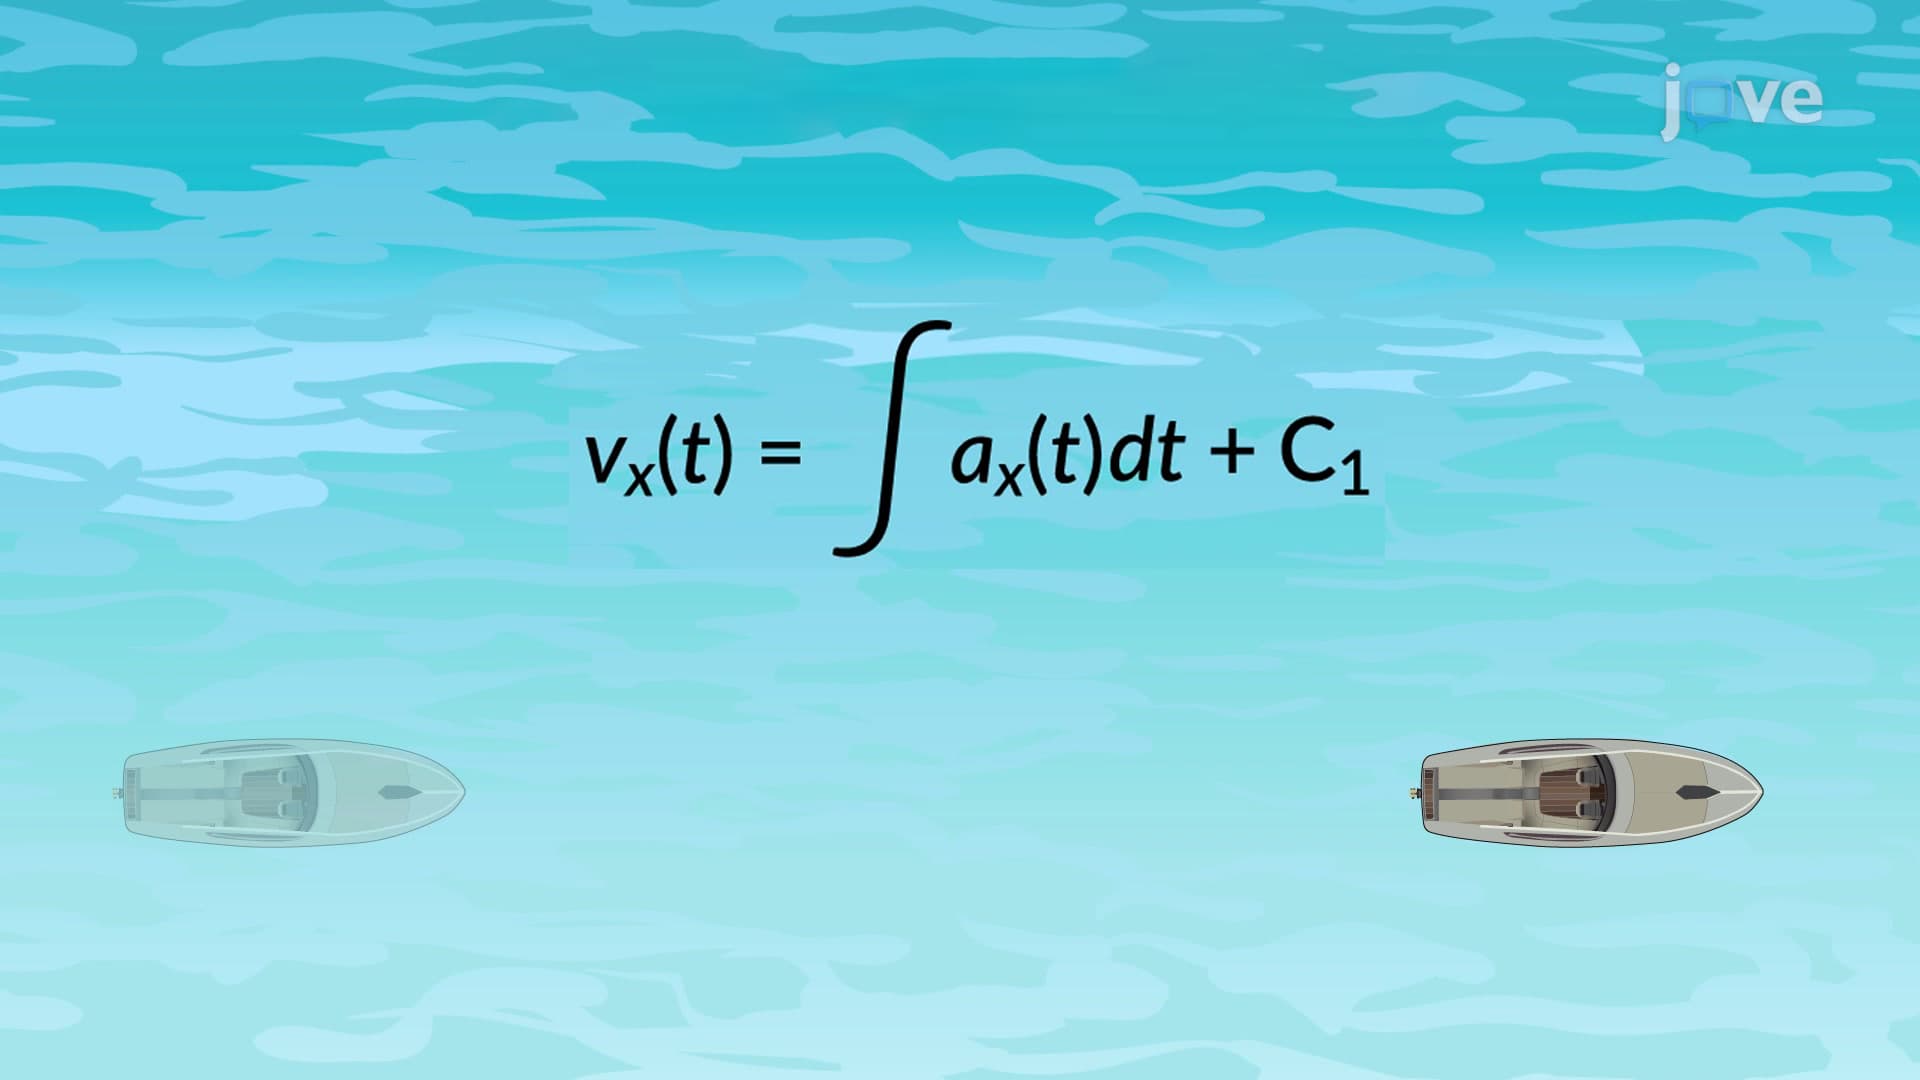 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:13
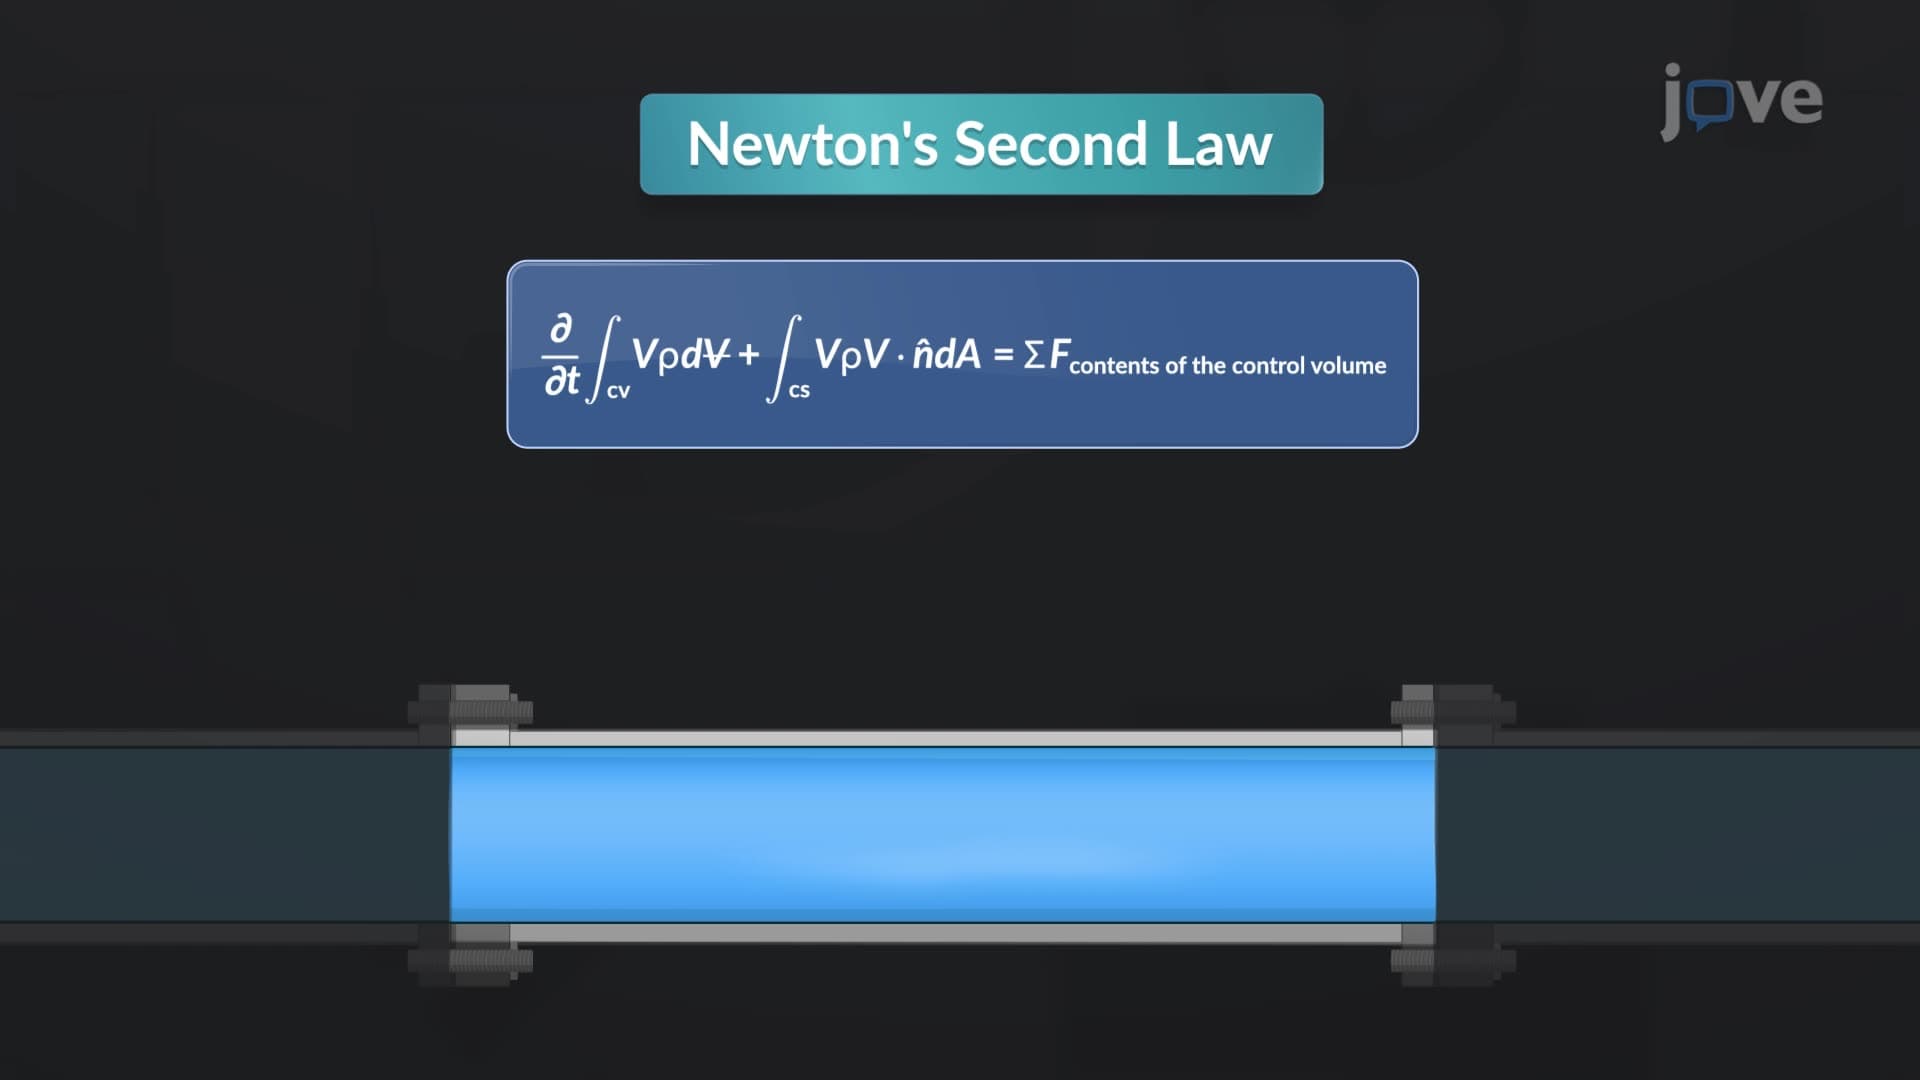
Linear Momentum in Control Volume
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...