Related Experiment Video
Updated: Jun 21, 2026


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Ankle exoskeleton assistance increases task-relevant variability without altering center of mass control during
Cagla Kettner1, Melina Beyerlein1, Charlotte Marquardt2
1BioMotion Center, Institute of Sports and Sports Science, Karlsruhe Institute of Technology, Karlsruhe 76131, Germany.

Background:
Ankle exoskeletons alter joint kinematics during walking, yet their effects on whole-body coordination remain unclear. This study investigated how ankle exoskeleton assistance influences the structure of motor variability and center-of-mass movement during steady-state walking.
Methods:
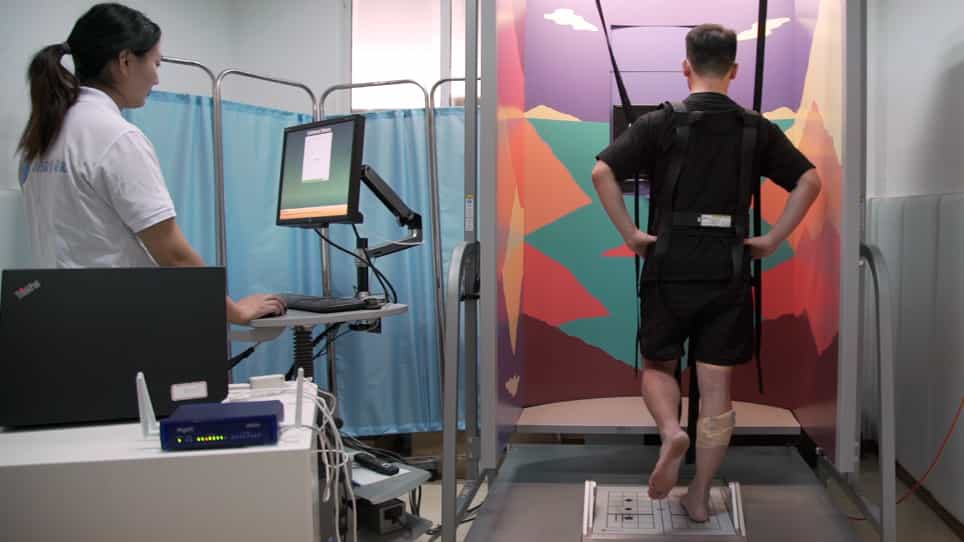
Twenty healthy adults walked on a treadmill at 1.1 m/s without the exoskeleton (noExo) and with active exoskeleton assistance (Exo). Whole-body kinematics were recorded. Variability was analyzed using the Uncontrolled Manifold (UCM) approach. Joint angle variability was decomposed into components that do not affect center-of-mass position (UCM||) and components that do (UCM⊥). Their ratio (UCMratio), reflecting the synergy stabilizing the center-of-mass, was calculated. Center-of-mass position was analyzed separately in three dimensions. Time-continuous differences across the gait cycle were evaluated using statistical parametric mapping.
Results:
UCM|| and UCMratio showed no significant differences between conditions. UCM⊥ was higher with exoskeleton assistance over large portions of the gait cycle (0-80%, p = 0.001; 91-100%, p = 0.022). Center-of-mass movement in the mediolateral and anteroposterior directions did not differ between conditions, while small differences were observed in the vertical direction (higher in Exo at 23-31% and 75-84%, p = 0.037; lower at 48-54%, p = 0.042).
Conclusion:
Ankle exoskeleton assistance increased joint-level variability affecting center-of-mass movement, but overall center-of-mass control was preserved, with only small changes in vertical center-of-mass displacement. Healthy adults maintained whole-body coordination despite altered mechanical conditions introduced by the exoskeleton. These findings are relevant for clinical exoskeleton use, where assistive devices should support walking without compromising center-of-mass control and balance.