Related Experiment Video
Updated: Jul 3, 2026
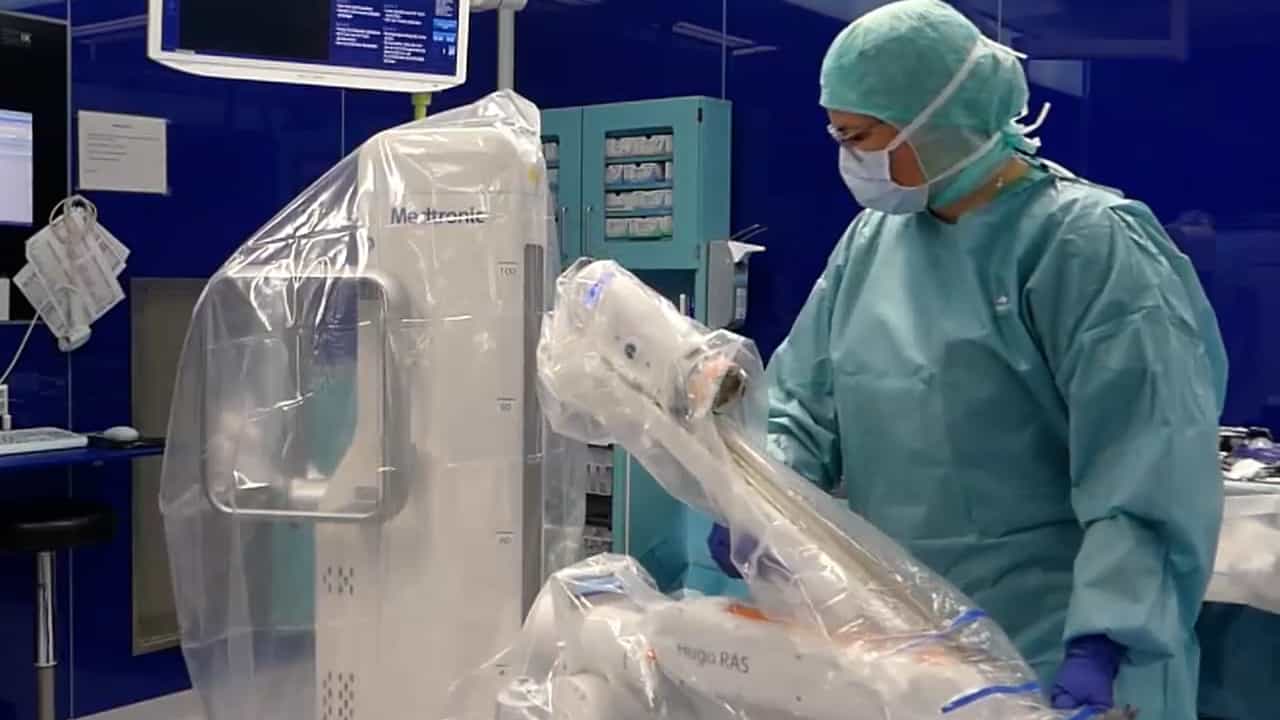

Robotics in Surgery: A Modular Robotic Platform Driven Gastric Wedge Resection
Published on: February 7, 2025
A novel bimanual endoluminal robotic platform compatible with standard gastroscopes for endoscopic submucosal
Yung Lee1, Ji Seok Park1, Stephen Firkins1
1Digestive Disease Institute, Cleveland Clinic, 9500 Euclid Ave A30, Cleveland, OH, 44195, USA.

Background And Aims:
Endoscopic submucosal dissection (ESD) enables en bloc resection of early gastrointestinal neoplasia but remains technically demanding because of limited traction, lack of triangulation, and high operator workload, contributing to a steep learning curve. We evaluated a novel endoluminal robotic platform designed to provide surgical-like bimanual triangulation, stable traction/counter-traction, and improved ergonomics while preserving compatibility with standard gastroscopes.
Methods:
The robotic system (Intilume System, Agilis Robotics, Hong Kong, SAR) uses an external positioning cart to drive two 3.5-mm flexible robotic instruments mounted onto a native gastroscope via a cap-and-sheath interface and controlled by compact pen-style motion-tracking controllers enabling seated operation. Available instruments included a bipolar T-knife and a tissue grasper. In a randomized crossover ex vivo porcine stomach study, two gastroenterology fellows without prior ESD experience and two interventional endoscopy fellows with early experience each performed four ESDs (two robotic, two conventional), for a total of 16 procedures. Outcomes included en bloc resection, procedure time, specimen surface area, dissection speed, tissue injury, and operator workload assessed using NASA-TLX, with exploratory OSATS and GEARS evaluations.
Results:
All procedures were completed (8 robotic, 8 conventional). Robotic ESD achieved 100% en bloc resection versus 75% with conventional ESD (p = 0.47), was significantly faster (14.1 ± 4.3 vs 21.6 ± 7.6 min; p = 0.028), and demonstrated higher dissection speed (36.5 ± 23.4 vs 16.3 ± 10.1 mm2/min; p = 0.05). No muscular injuries occurred with robotic ESD compared with 5/8 conventional cases; no full-thickness injuries occurred. Operator workload was markedly lower with robotic ESD (NASA-TLX 34.7 ± 24.1 vs 75.0 ± 15.4; p = 0.002).
Conclusion:
In a randomized ex vivo model, a bimanual endoluminal robotic platform compatible with standard endoscopes demonstrated promising improvements in ESD efficiency, tissue control, and operator ergonomics compared with conventional ESD. These preliminary findings support further development and progression to first-in-human feasibility evaluation, with potential to facilitate ESD skill acquisition pending clinical validation.
Related Concept Videos
 01:28
Endoscopic Procedures III: Video Capsule Endoscopy
 01:26
Endoscopic Procedures IV: Sigmoidoscopy and Laproscopy
Sigmoidoscopy
Sigmoidoscopy is a diagnostic procedure that uses a flexible sigmoidoscope equipped with a light source and camera to examine the rectum and sigmoid colon. The procedure involves inserting the tube through the anus...
 01:29
Endoscopic Procedures I: Esophagogastroduodenoscopy
During an EGD, the endoscope can be used to: