Related Experiment Video
Updated: Aug 6, 2026


A Teleoperated Robotic System-Assisted Percutaneous Transiliac-Transsacral Screw Fixation Technique
Published on: January 6, 2023
Understanding the Workflows in Dynamic and Robotic Computer-Assisted Implant Surgery
Adria Jorba-Garcia1, Shengchi Fan2, Feng Wang3
1Department of Oral Surgery and Implantology, Faculty of Medicine and Health Sciences, University of Barcelona, Barcelona, Spain.

Abstract:
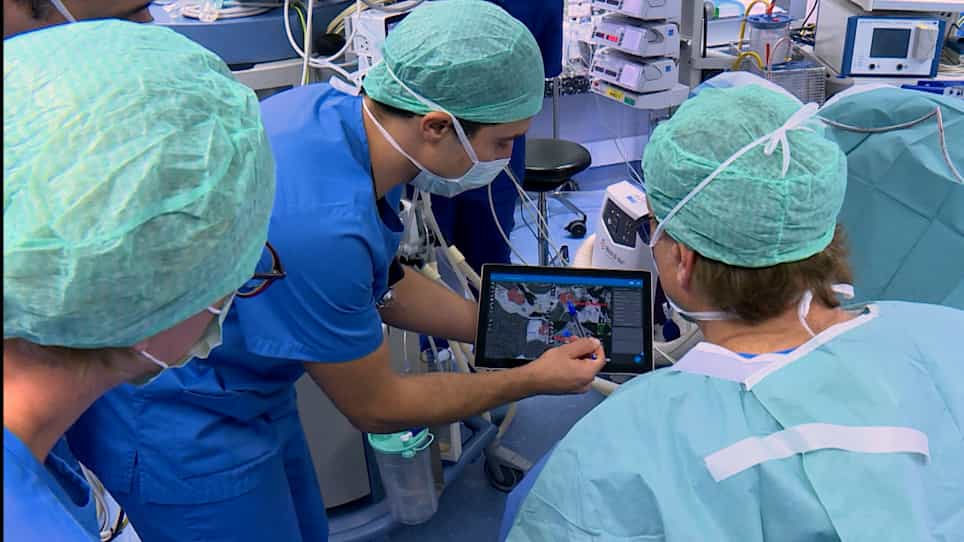
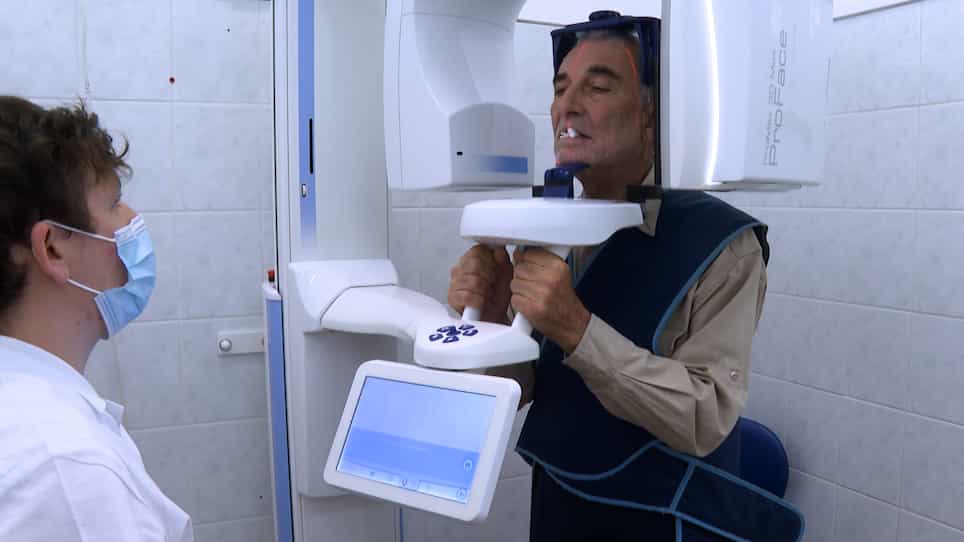
Computer-assisted implant surgery (CAIS) represents a comprehensive digital workflow integrating prosthetically driven planning with various execution modalities. Among these, dynamic (d-CAIS) and robotic (r-CAIS) systems constitute two distinct yet interrelated approaches, sharing core technological principles as well as operative differences. This white paper aims to provide a structured overview of the fundamental concepts and workflows underpinning d- and r-CAIS, focusing on their shared components, procedural steps, and system-specific characteristics. Both approaches rely on accurate digital treatment planning, spatial positioning systems, registration protocols, and real-time feedback mechanisms to guide implant placement. However, while d-CAIS enables operator-controlled freehand execution under real-time navigation, r-CAIS introduces robotic assistance or task autonomy, integrating mechanical actuation into the surgical workflow. Rather than providing exhaustive technical instructions, this work aims to establish a conceptual framework to support clinicians in understanding and evaluating emerging CAIS technologies and their role in contemporary implant dentistry. Furthermore, it discusses current advantages, limitations, and challenges related to clinical implementation, cost, and training requirements.