Related Experiment Video
Updated: Aug 6, 2026
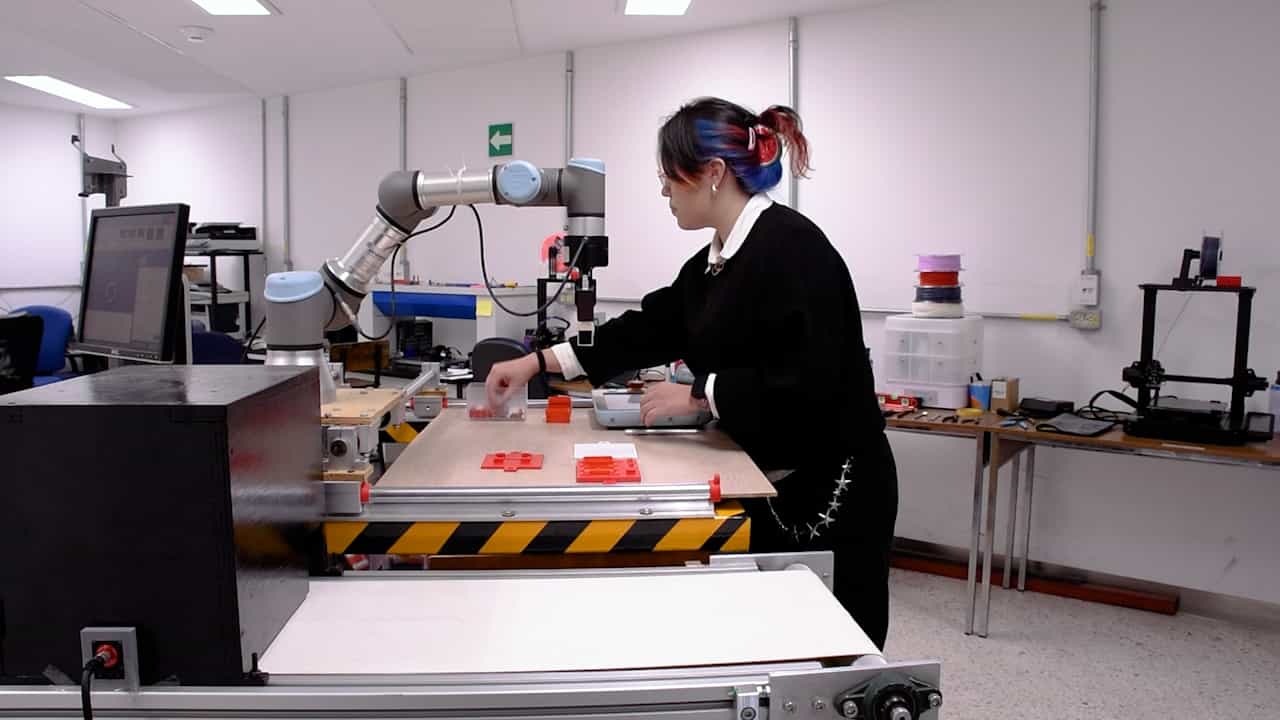

Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Digital twin for scenario-based design evaluation of manufacturing robotic fleets and factory layouts
Sepideh Valiollahi1, Ignacio Rodriguez2, Stefan Nordborg Eriksen3
1Wireless Communication Networks Section, Department of Electronic Systems, Aalborg University, Aalborg Øst, 9220, Denmark. svbi@es.aau.dk.

Abstract:
Digital twin (DT) technology is increasingly used in industrial systems to support data-driven decision making, reduce human intervention, and improve coordination in automated environments. This study investigates how a DT-based simulation framework can support scenario-based design evaluation of production throughput by jointly modeling production processes, factory layouts, and heterogeneous robotic fleets with specialized roles such as transportation and manipulation. The proposed framework provides a high-fidelity representation of robotic operations, workflow dynamics, and spatial constraints across both brownfield and greenfield manufacturing environments. In brownfield settings, constrained by legacy infrastructure, the framework reveals scalability limits of robotic fleets and diminishing returns due to congestion. In greenfield environments, the framework enables systematic evaluation of layout configurations, fleet sizes, and functional role balance. The results show that bottlenecks may arise not only from spatial constraints but also from imbalances within the robotic fleet. In a representative case study, increasing fleet size in brownfield layouts yields limited improvements, whereas balanced configurations in greenfield layouts achieve up to 3.5× throughput gains without reducing productivity per robot.
Related Concept Videos
 02:16
Stereotype Content Model
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...