Related Experiment Video
Updated: Aug 5, 2026


An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Motion-Driven Automatic IMU Orientation Calibration via SO(3) Pattern Alignment
1Department of Mechanical Engineering, Virginia Tech, Blacksburg, VA 24060, USA.

Abstract:
Calibration of body-worn inertial measurement units (IMUs) is essential for accurate motion estimation, yet sensor orientations may drift over time due to slippage or long-term integration errors. This causes an IMU to gradually lose alignment with the body segment on which it is mounted. In this paper, we develop a novel technique for Automatic Calibration-recovering this alignment during normal motion, without a dedicated calibration step. We implement automatic calibration by formulating it as the alignment of motion-induced orientation distributions on SO(3). When the activity being performed is known (e.g., walking), the distribution of orientations for a correctly calibrated IMU exhibits a characteristic and repeatable pattern on SO(3). Although sensor drift may rotate this distribution into a different orientation, the underlying pattern remains similar. Thus, we calibrate a drifted IMU by aligning its observed orientation distribution to a prior reference distribution obtained from the same activity, either from the same subject at an earlier time or from other subjects. To perform this alignment, we employ a correspondence-free spherical pattern matching method on SO(3) (SO3_SPMC), based on transformed basis vector distributions and spherical cross-correlation. We evaluate the proposed automatic calibration framework with N = 5 people wearing body-worn IMUs during activities of daily living, demonstrating calibration accuracy comparable to supervised single-frame calibration without requiring explicit calibration poses or user intervention. The activities of walking, typing, and using using a computer mouse were best for automatically calibrating a sensor on the wrist.
More Related Videos
 11:57
Three-dimensional Super Resolution Microscopy of F-actin Filaments by Interferometric PhotoActivated Localization Microscopy (iPALM)
Published on: December 1, 2016
 09:18
Measurement of Extracellular Ion Fluxes Using the Ion-selective Self-referencing Microelectrode Technique
Published on: May 3, 2015
Related Concept Videos
 01:24
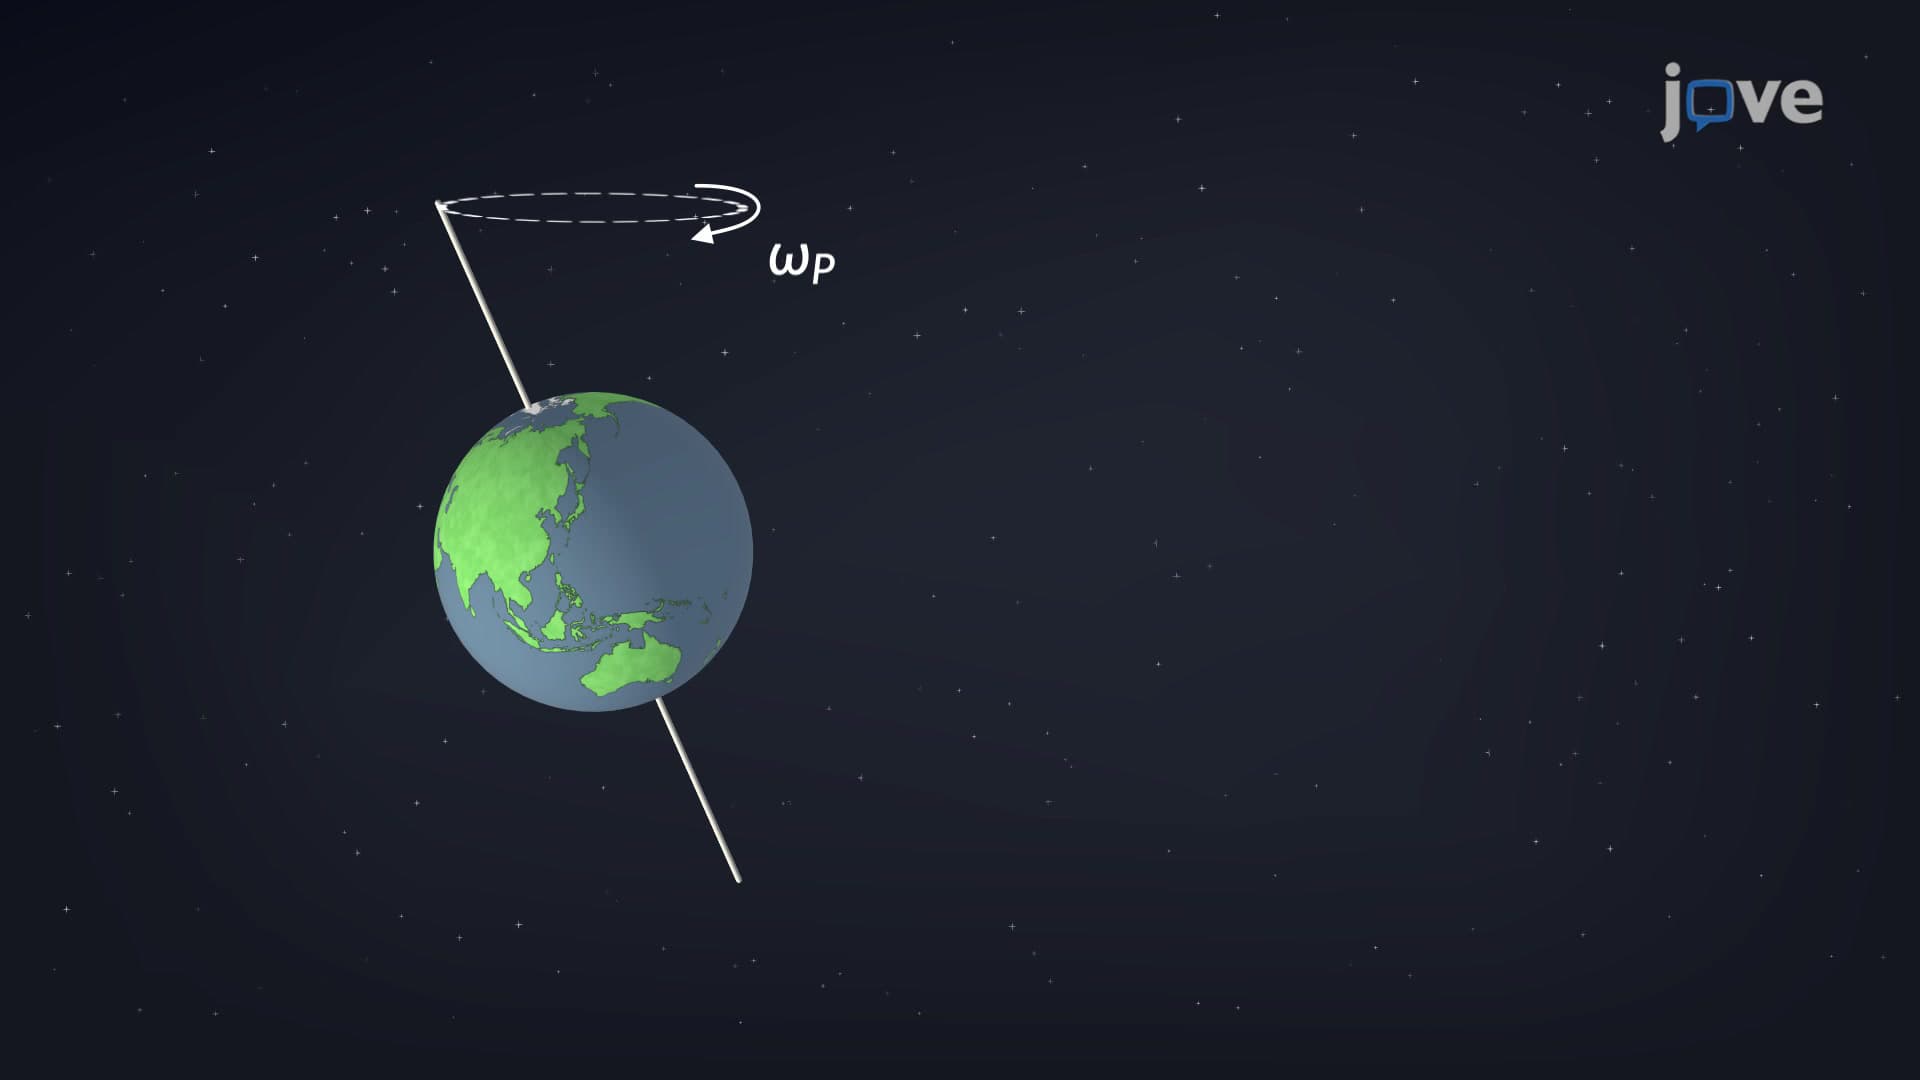
Gyroscope: Precession
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:37
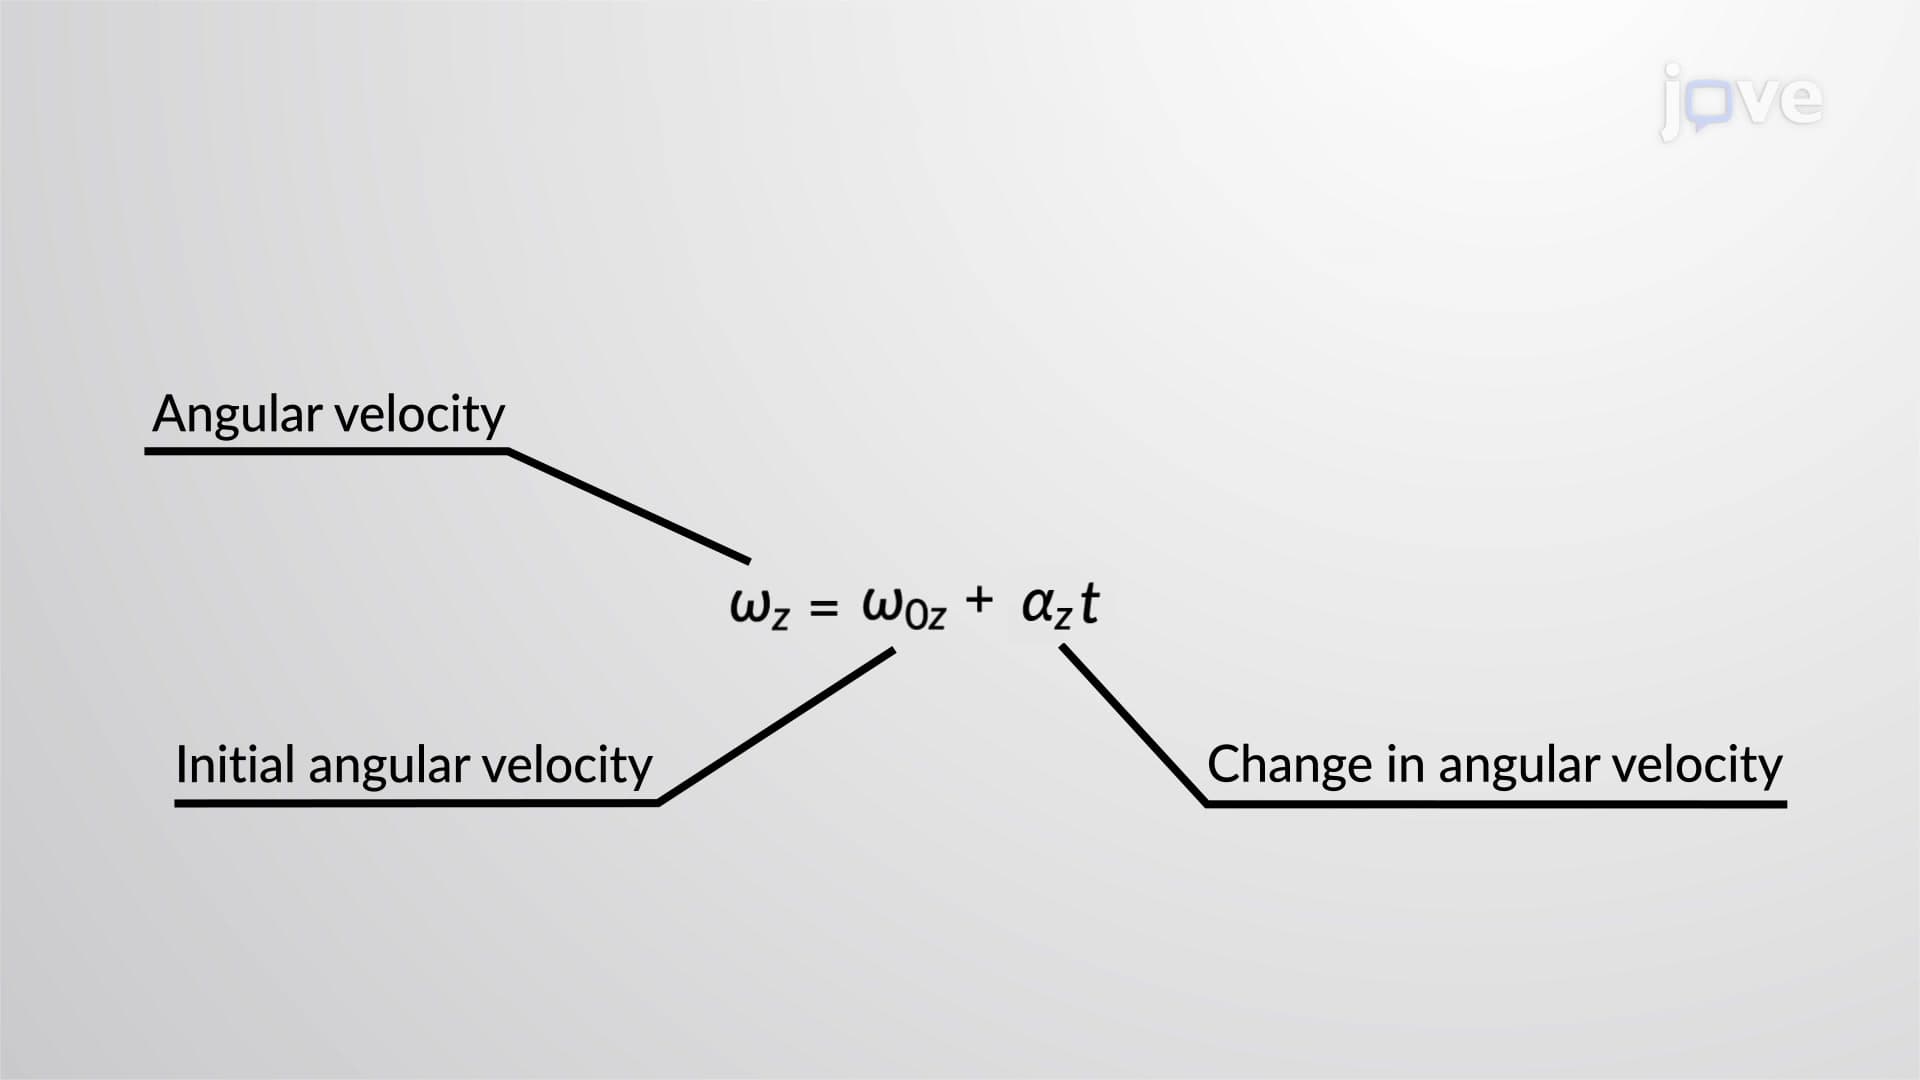
Rotation with Constant Angular Acceleration - I
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...