Related Experiment Video
Updated: Aug 7, 2026

Origami Inspired Self-assembly of Patterned and Reconfigurable Particles
Published on: February 4, 2013
A Rigid-Foldable Kirigami-Inspired Metamorphic Mechanism With Programmable Motion Modes and Self-Locking
Jianlin Wang1, Zhongmin Song2, Ketao Zhang1
1Centre for Advanced Robotics (ARQ), Queen Mary University of London, London, UK.

Abstract:
Compact metamorphic mechanisms capable of multifunctionality, especially geometric-constraint-induced changes in motion mode and intrinsic self-locking without sustained actuation, are valuable for engineering deployable and adaptive robotic systems. This paper presents a rigid-foldable, kirigami-inspired metamorphic parallel mechanism composed solely of revolute joints. Based on screw theory, we establish a unified kinematic model that systematically characterizes the four distinct configurations and their corresponding motion modes, including one uniaxial twisting motion, two coupled translations (lateral-vertical and longitudinal-vertical), and a self-locking state consistent with the motion characteristics of the rigid-foldable kirigami. The analysis reveals that the mechanism can switch among the four motion modes by reconfiguring the geometric constraints through changes in the programming pattern of the four actuated joints, without reassembly of the kinematic structure. The proof-of-concept prototype and experimental tests validate motion-mode switching and the passive structural rigidity of the tested energy-free self-locking configuration. This work demonstrates a way to encode functional adaptability directly into robot body design, reducing reliance on complex actuation and control systems. Such principles have broad implications for scalable, energy-efficient systems in fields ranging from robotics and aerospace structures to biomedical devices.
Related Concept Videos
 01:05
Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
01:05Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
 01:15
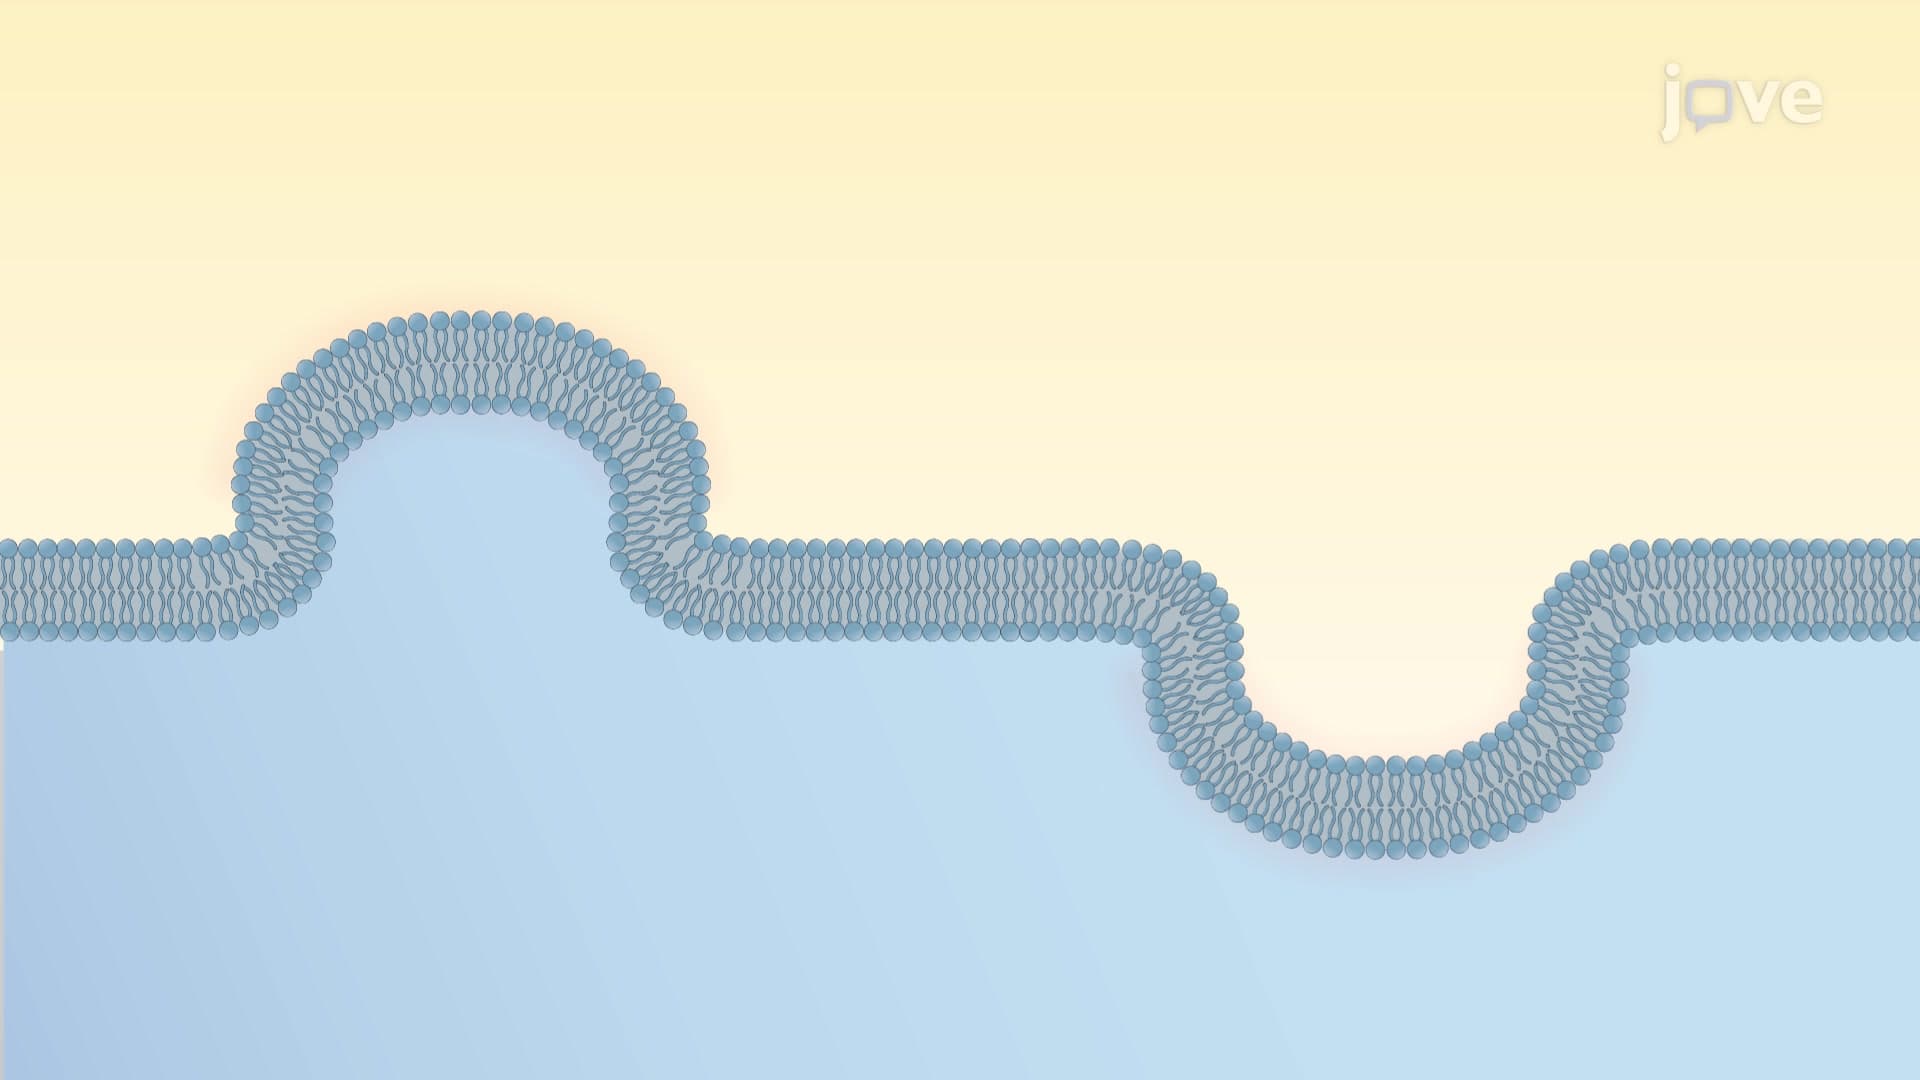
Mechanisms of Membrane-bending
Membrane bending can happen due to intrinsic changes in lipid composition or extrinsic association with different proteins. The proteins involved...
 01:22
Mechanical Systems
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:25
Fascicle Arrangement in Skeletal Muscles
The four primary types of muscle based on fascicle arrangement are: