Related Experiment Video
Updated: Aug 9, 2026

Pavlovian Conditioned Approach Training in Rats
Published on: February 4, 2016
Expert Behavior Prior Reinforcement Learning

Abstract:
Behavior prior reinforcement learning (BPRL) has emerged as a promising paradigm to improve sample efficiency in online reinforcement learning (RL) by leveraging policy priors derived from offline demonstrations. However, most existing BPRL methods rely on static offline datasets, which often suffer from low data diversity and suboptimal trajectory quality. This reliance restricts the effectiveness of policy priors, hindering both policy exploitation and stability during online training. Consequently, agents are prone to inefficient exploration and unstable learning dynamics. To address these limitations, we deviate from existing offline pretraining methods and propose an expert behavior prior (EBP) algorithm. In particular, we introduce a Q-guided conditional variational autoencoder (Q-CVAE) that learns to generate expert policy priors directly from the online replay buffer. This enables the generation of high-value actions for guiding policy updates without relying on precollected expert trajectories. To further enhance policy exploitation, we propose an expert policy guidance (EPG) mechanism that selects expert actions from a generative support set, and we integrate a policy gradient correction (PGC) module to harmonize Q-guidance with expert supervision, promoting stable and consistent policy improvement. Extensive experiments conducted on robotic control (Gym, PyBullet) and industrial control (DMControl) benchmarks demonstrate that EBP significantly outperforms state-of-the-art online RL algorithms, achieving higher sample efficiency and more stable convergence.
Related Concept Videos
 01:28
Behaviorism
The core premise of behaviorism is its focus on observable behavior rather than internal thoughts or feelings. This approach argues that true scientific...
 01:06
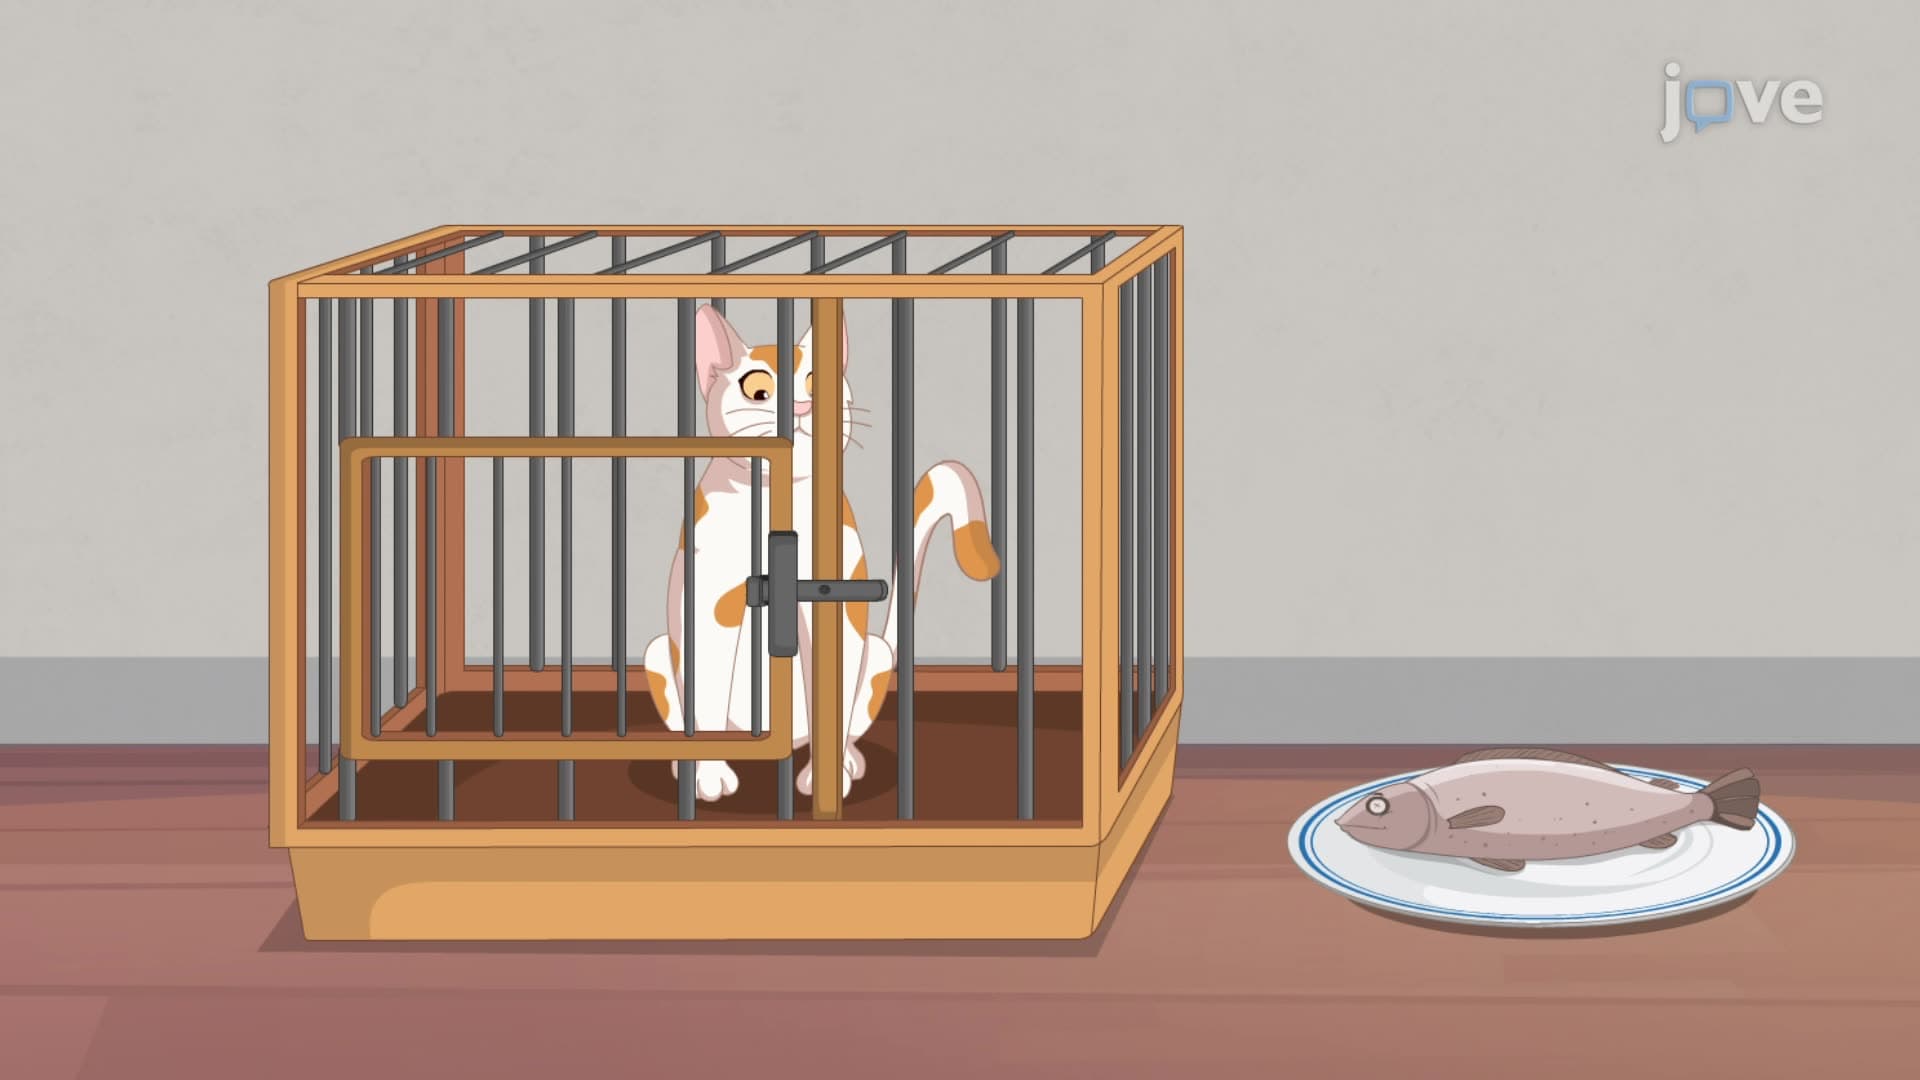
Law of Effect
Edward Thorndike's foundational work involved studying learning in animals, particularly using puzzle boxes...
 01:24
Generalization, Discrimination, and Extinction
Generalization occurs when a behavior reinforced in one context is performed in similar situations. For instance, a student who studies diligently for calculus and receives excellent grades might apply the same study habits to psychology and history, expecting similar results. Generalization shows how learning in one setting can influence behavior in...
 01:23
Reinforcement
Positive reinforcement occurs when a behavior is followed by the presentation of a rewarding stimulus, increasing the frequency of that behavior. For example:
 01:21
Cognitive Learning
E. C. Tolman's theory of purposive behavior emphasizes that much behavior is goal-directed. He argued that to understand behavior, we must look at the entire sequence of actions leading to a goal. For instance, high school students study hard, not just due to past reinforcement but also to achieve the goal of getting into a good college.
Tolman introduced the idea that behavior is influenced by...
 01:27
Associative Learning
Classical conditioning, also known...