Related Experiment Video
Updated: Aug 14, 2026

Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
SONIC: Supersizing motion tracking for natural humanoid whole-body control
Zhengyi Luo1, Ye Yuan1, Tingwu Wang1
1NVIDIA, Santa Clara, CA, USA.

Abstract:
Despite the rise of billion-parameter foundation models trained across thousands of graphical processing units (GPUs), similar scaling gains have not been shown for humanoid control. Current neural controllers for humanoids remain modest in size, target a limited set of behaviors, and are trained on a handful of GPUs. We show that scaling model capacity, data, and compute yields a generalist humanoid controller capable of natural, robust whole-body movements. We position motion tracking as a scalable task for humanoid control, leveraging dense supervision from diverse motion-capture data to acquire human motion priors without manual reward engineering. We build a foundation model for motion tracking by scaling along three axes: network size (1.2 to 42 million parameters), dataset volume (more than 100 million frames from 700 hours of motion capture), and compute (21,000 GPU hours). Beyond demonstrating the benefits of scale, we further show downstream utility through a real-time kinematic planner that bridges motion tracking to tasks such as navigation, enabling natural and interactive control, as well as a unified token space that supports virtual reality (VR) teleoperation and vision-language-action (VLA) models with a single policy. Through this interface, we demonstrate autonomous VLA-driven whole-body locomanipulation requiring coordinated hand and foot placement. Scaling motion tracking exhibits favorable properties: Performance improves steadily with compute and data diversity, and learned policies generalize to unseen motions, establishing motion tracking at scale as a practical foundation for humanoid control.
More Related Videos
 06:52
Deep-Learning Based Multi-Joint Synchronous Tracking for Objective Quantification of Hindlimb Locomotor Kinematics in Rats
Published on: April 3, 2026
 08:24
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
Related Concept Videos
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:15
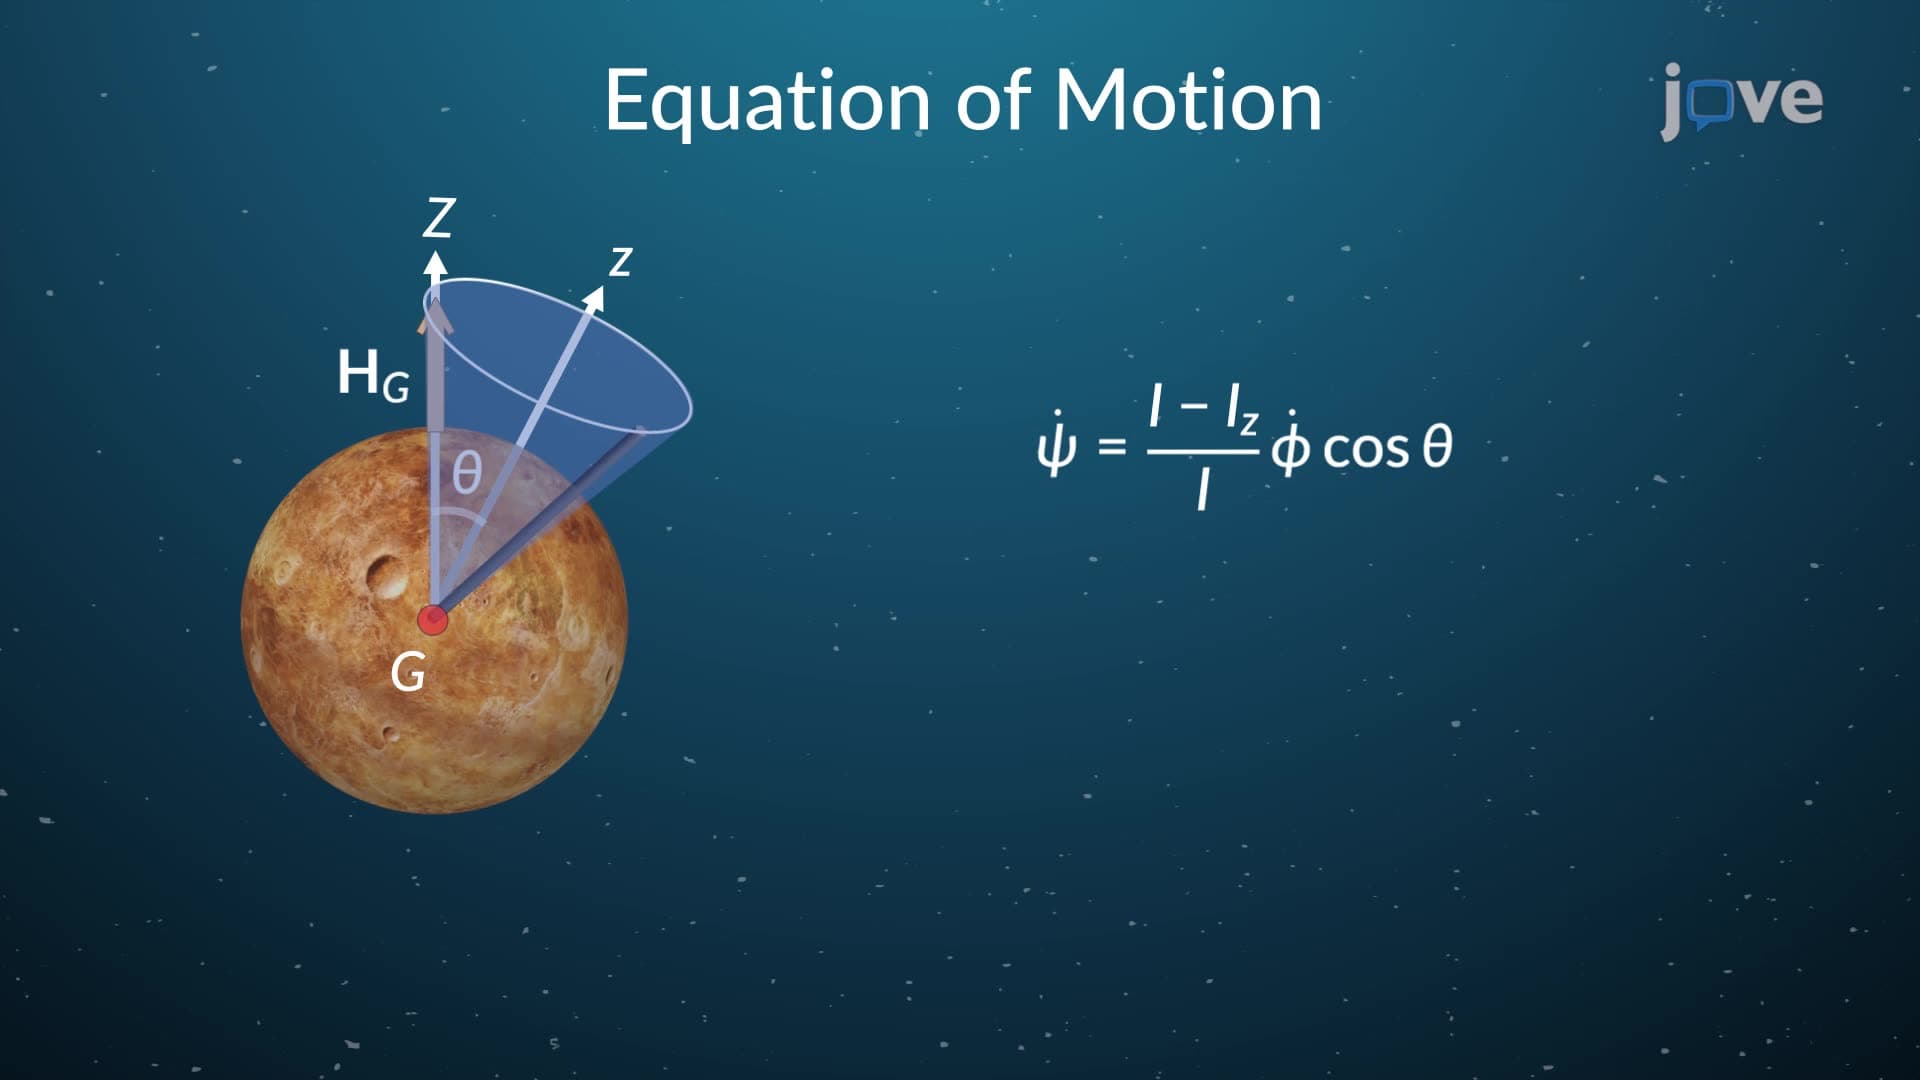
Torque Free Motion
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...