Related Experiment Video
Updated: Sep 9, 2026
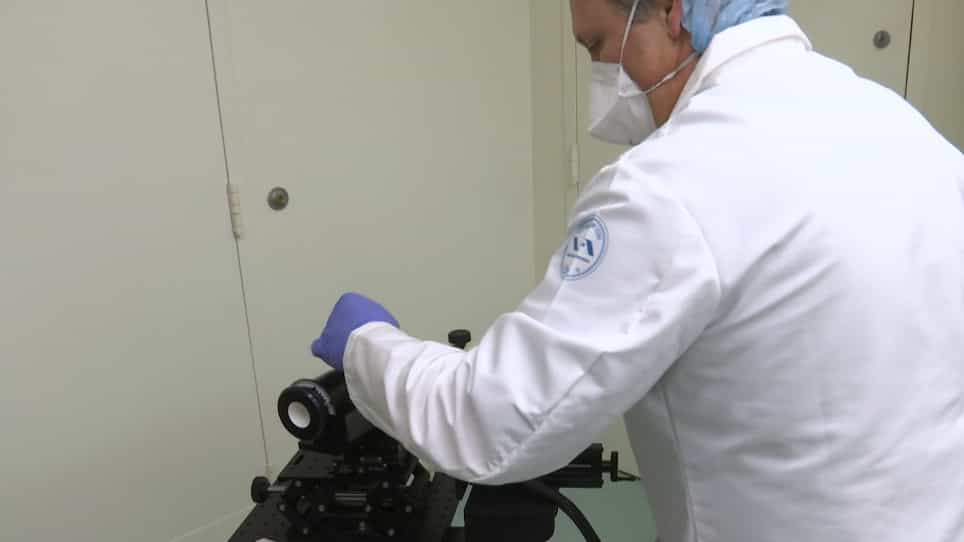

Ultrahigh Resolution Mouse Optical Coherence Tomography to Aid Intraocular Injection in Retinal Gene Therapy Research
Published on: November 2, 2018
SS-OCT-guided dual-arm master-slave robotic system for in vivo subretinal injection in porcine eyes
Zhangwanyu Wei1,2,3, Zhaodong Wang4, Junqi Chen1,2,3
1Department of Ophthalmology, Peking Union Medical College Hospital, Chinese Academy of Medical Sciences and Peking Union Medical College, Beijing, 100730, China.

Abstract:
To evaluate the feasibility, safety, and stability of a novel remote multimodal surgical platform that integrates a dual-arm robotic system with an intraoperative swept-source OCT surgical microscope system for subretinal injection in porcine eyes. Subretinal injection was performed in vivo in Bama miniature pigs (one eye per animal), with six animals assigned to robotic manipulation (RM) and six to manual manipulation (MM). Successful injection was defined as localized subretinal bleb formation confirmed by intraoperative OCT. Outcome measures included procedure time, injection time, first-attempt success rate, bleb morphology, intraoperative complications, postoperative OCT findings, needle-tip tremor amplitude, and histological changes. Subretinal injection was successful in all 12 eyes (100% success rate), with a first-attempt success rate of 5/6 in the RM group and 3/6 in the MM group. Total procedure time was longer in the RM group (901.5 vs. 489.8 s, P = 0.0093), whereas injection time did not differ significantly (median 8.00 vs. 8.50 s, P = 0.6842). Tremor amplitudes were numerically lower in the RM group but did not reach statistical significance (average: 4.48 ± 0.62 vs. 11.06 ± 3.65 μm, P = 0.087; peak: 23.19 ± 2.65 vs. 47.98 ± 18.66 μm, P = 0.146). No severe complications (extensive retinal detachment, uncontrolled bleeding, or lens injury) occurred in either group; minor localized hemorrhage showed a narrower distribution in the RM group than in the MM group. Postoperative OCT confirmed retinal reattachment in all eyes, and histology revealed only localized entry-site changes. This dual-arm robotic platform enabled successful bimanual subretinal injection in all porcine eyes, with comparable injection time, bleb morphology, and short-term tissue safety relative to manual surgery. Despite a longer total procedure time, the system showed a non-significant trend toward reduced needle-tip tremor. These results support the feasibility and preliminary safety of this platform for subretinal injection and warrant further evaluation for remote bimanual vitreoretinal microsurgery.
More Related Videos
 12:45
Development of a Refined Protocol for Trans-scleral Subretinal Transplantation of Human Retinal Pigment Epithelial Cells into Rat Eyes
Published on: August 12, 2017
 06:04
Performing Subretinal Injections in Rodents to Deliver Retinal Pigment Epithelium Cells in Suspension
Published on: January 23, 2015