Related Experiment Video
Updated: Sep 12, 2026
A Networked Desktop Virtual Reality Setup for Decision Science and Navigation Experiments with Multiple Participants
Published on: August 26, 2018
A hierarchical navigation decision-making method for UAV swarms in unknown communication-constrained environments
Huajie Xiong1,2, Baoguo Yu2, Jingkui Zhang1,2
1CETC 54th Research Institute, Shijiazhuang, China.

Abstract:
In recent years, Unmanned Aerial Vehicles (UAVs) have gradually been widely used in various fields such as regional search and disaster relief, and the development of related technologies has also experienced unprecedented growth. Compared to individual UAVs, the collaborative execution of tasks by UAV swarms has more advantages, but it is often difficult to achieve fast and accurate autonomous navigation and obstacle avoidance capabilities in unknown complex obstacle environments due to limitations in computing load and inter-UAV communication capabilities. To solve this problem, a hierarchical navigation decision-making framework for non-communication UAVs in unknown environments is proposed in this paper, which decomposes the UAV navigation planning task into an upper-layer global planning module and a lower-layer autonomous navigation and obstacle avoidance module. For the lower-layer module, an enhanced hybrid feature extraction network is designed, accompanied by a dual-stage training strategy that integrates traditional optimization methods with reinforcement learning. The upper-layer module incorporates a hybrid control strategy combining conventional search methods. Based on the ROS framework, simulation experiments for UAV swarm navigation were systematically conducted. The experimental results demonstrate that the proposed algorithm achieves autonomous navigation decision-making for multiple UAVs in complex unknown obstacle environments without relying on inter-UAV communication, showing significant advantages compared to existing approaches.
Related Concept Videos
 01:14
Decision Making: Traditional Method
First, a specific claim about the population parameter is decided based on the research question and is stated in a simple form. Further, an opposing statement to this claim is also stated. These statements can act as null and alternative hypotheses, out of which a null hypothesis would be a...
 01:09
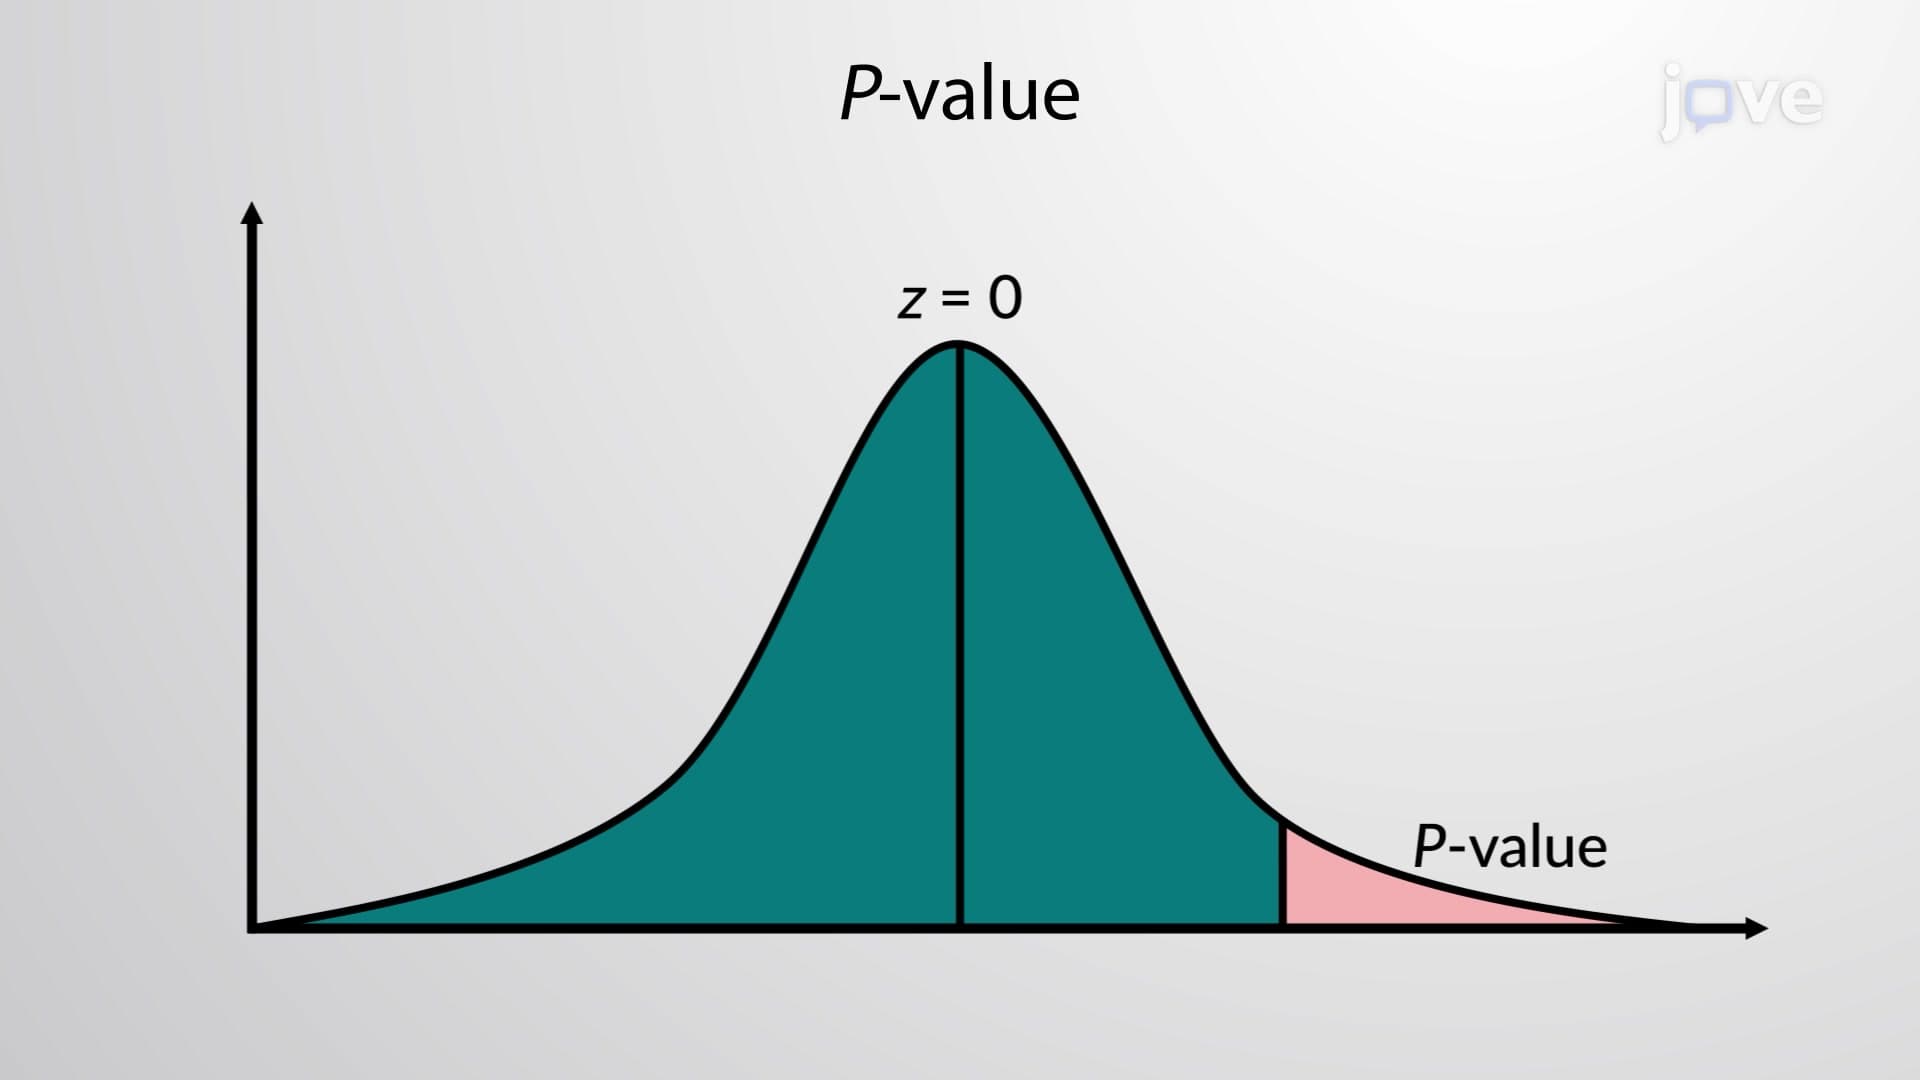
Decision Making: P-value Method
First, a specific claim about the population parameter is proposed. The claim is based on the research question and is stated in a simple form. Further, an opposing statement to the claim is also stated. These statements can act as null and alternative hypotheses: a null hypothesis would be a neutral statement while the alternative hypothesis can have a...
 01:20
Decision Making
Automatic decision-making is fast, intuitive, and relies on gut feelings...
 01:18
Hierarchy of Motor Control
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...