Related Experiment Video
Updated: Sep 14, 2026
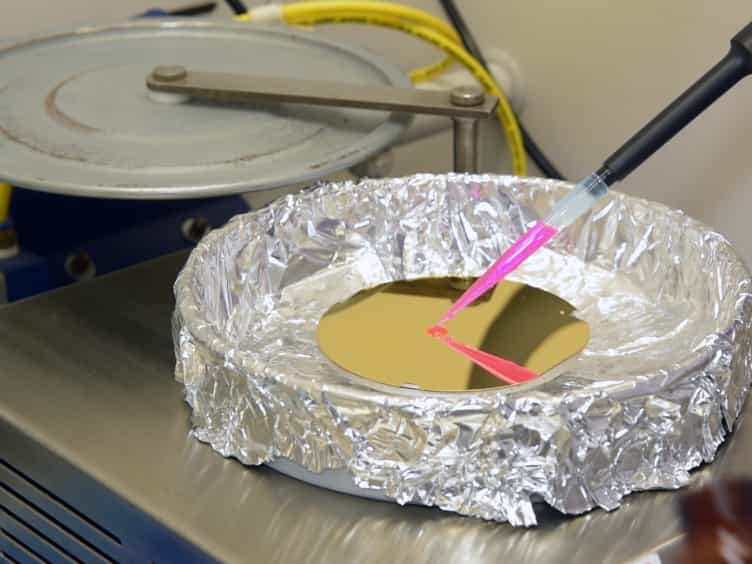

Polymeric Microneedle Array Fabrication by Photolithography
Published on: November 17, 2015
Kirigami-Inspired Deployable Microneedle Robot With Enhanced Conformability for Targeted Oral Drug Delivery
Kun Zhou1, Rujie Sun1, Yuyang Zuo1,2
1Department of Materials, Department of Bioengineering, and Institute of Biomedical Engineering, Imperial College London, London, UK.

Abstract:
Oral drug delivery is widely accessible to patients for the treatment of gastrointestinal diseases such as gastric ulcers. However, the efficacy of orally delivered drugs is often hindered by their short duration of acting and low local drug concentration, due to the dynamic environment of the gastrointestinal tract. Oral microneedle drug delivery systems offer a promising solution for achieving long-term drug release at target sites by inserting microneedles into tissues to prolong drug retention. Yet, their effectiveness is compromised by poor flexibility, which impedes microneedle insertion into rugose tissues. Herein, we introduce a kirigami-inspired deployable microneedle robot (KiriBot) featuring a porous network of cut patterns designed to enhance tissue attachment and facilitate microneedle insertion into the target tissue wall. KiriBot consists of a multilayer foldable microneedle patch that integrates sequential chemical and magnetic actuation to control both microneedle insertion and targeted drug release. Through in vitro and ex vivo evaluation under direct visual observation, we demonstrate that the kirigami design significantly improves flexibility and enables remote magnetic control for targeted microneedle insertion. These proof-of-concept results highlight the potential of KiriBot for localized gastrointestinal drug delivery, while in vivo device localization and magnetic actuation across clinically relevant conditions remain to be established.
Related Concept Videos
 01:30
Modified-Release Drug Delivery Systems: Stimuli-Activated
 01:24
Site-Targeted Drug Delivery Systems: Polymeric Carriers