Related Experiment Video
Updated: Sep 23, 2026

Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013
Quaternionic response geometry for proteins: toward a noncommutative theory of ordered deformations
Xiaoting Chen1, Chon-Fai Kam1,2, Yu Li3
1University Paris City & University of Reunion, 75015, Paris, France.

Abstract:
Protein function may depend not only on endpoint conformations but also on the ordered deformation histories through which they are reached. This distinction is relevant to allostery, conformational switching, mutation-induced rearrangements, and epistatic effects, where different perturbation sequences may produce similar visible structures while retaining distinct internal transport histories. Current state-centered or endpoint-centered representations do not always preserve this order-sensitive information. The practical motivation is therefore to provide a foundation for future descriptors of protein deformation trajectories that can distinguish ordered histories even when endpoint conformations are similar. Such descriptors could support analyses of allosteric switching, mutation-order effects, conformational memory, and path-dependent response in molecular-dynamics trajectories, NMR ensembles, structural families, and outputs of geometric generative models. We propose a deformation-first geometric framework based on quaternionic frame transport along the protein backbone. Local backbone frames are lifted to quaternionic variables, with infinitesimal rotation encoded by [Formula: see text]. Ordered concatenation of admissible deformation paths generates a noncommutative transport algebra, recording that deformation [Formula: see text] followed by [Formula: see text] need not be equivalent to [Formula: see text] followed by [Formula: see text]. From this ordered transport layer, we construct a spectral-response layer comprising a global Dirac-type operator, local spectral germs, a renormalized spectral density, and a mixed response form. A minimal realization on an idealized α-helix shows how localized pitch and bending perturbations can yield similar endpoint descriptors while producing a nonzero endpoint-derived ordered-transport discrepancy. At the formal level, the framework separates an order-sensitive transport-memory sector, lost under a commutative shadow, from a spectral-response sector that remains visible.
Related Concept Videos
 01:08
Equation of Rotational Dynamics
 01:12
Temperature Dependent Deformation
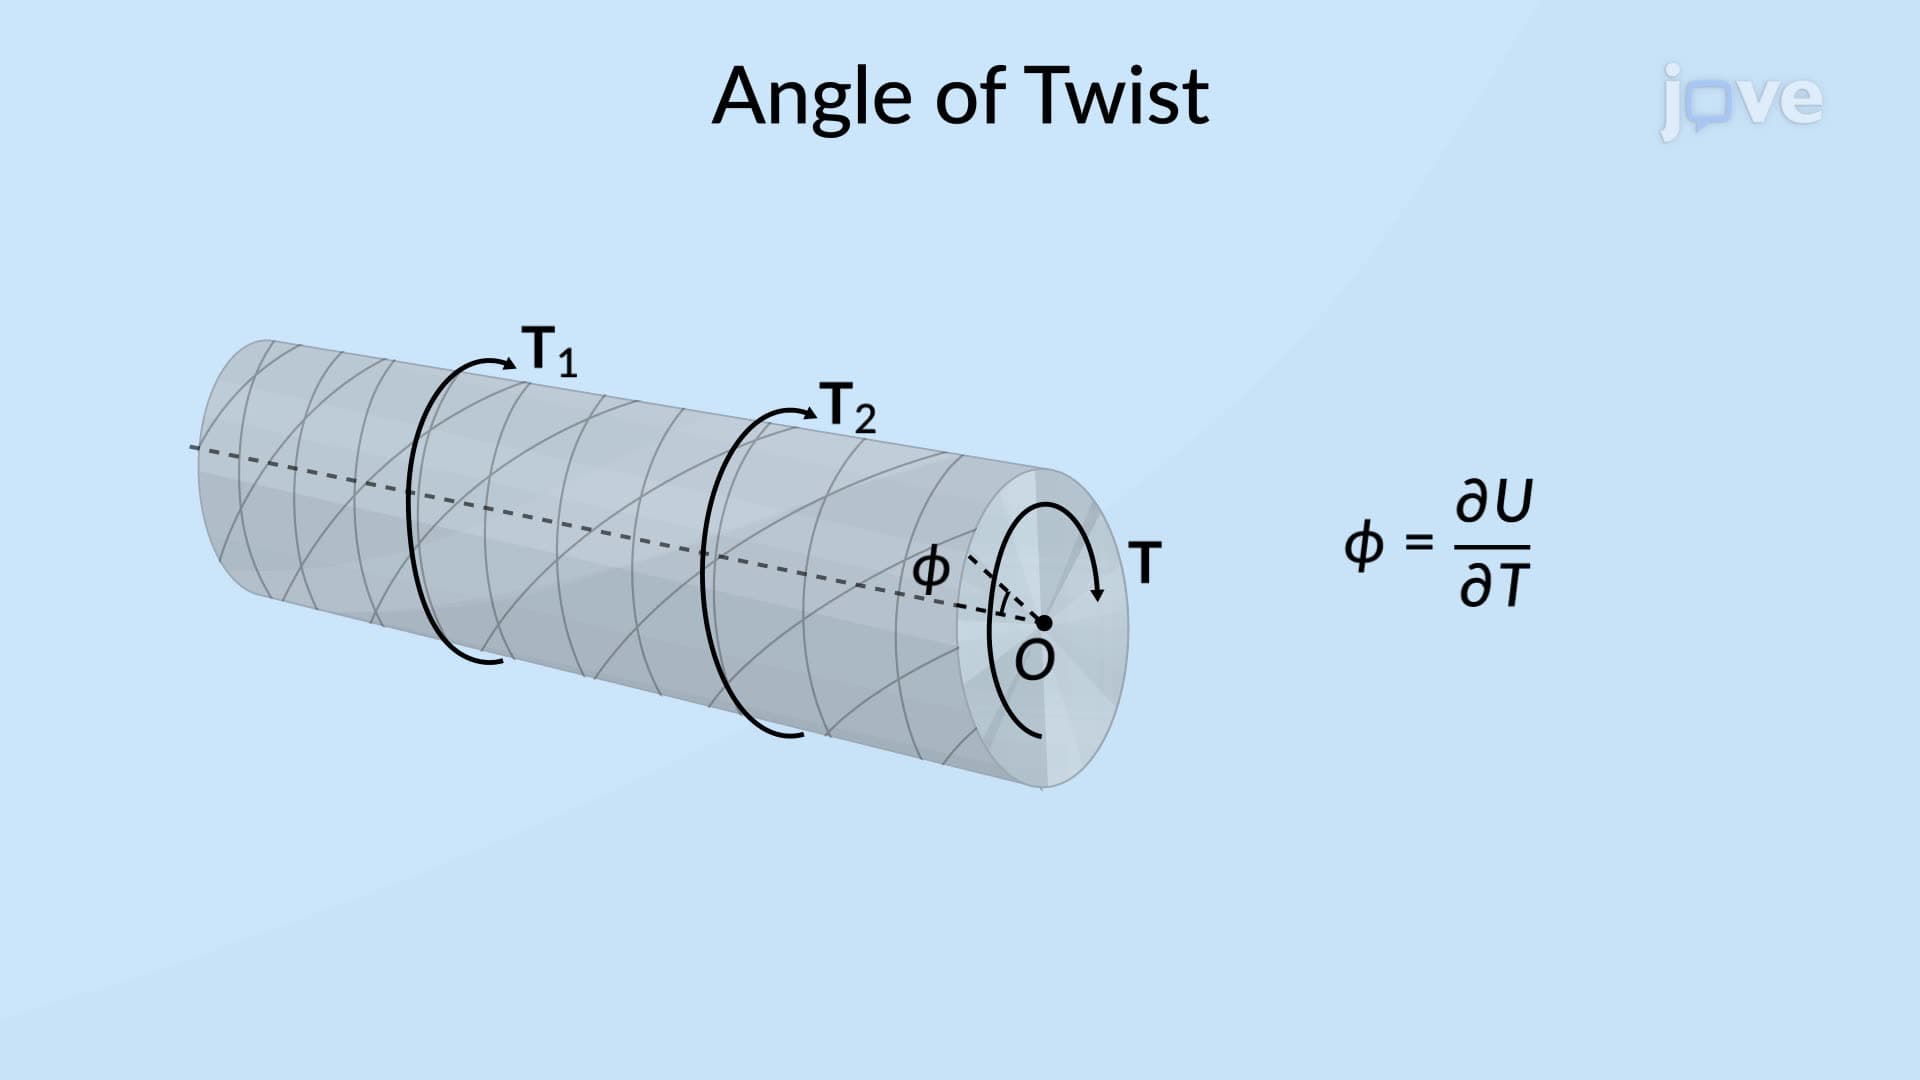 01:18
Castigliano's Theorem
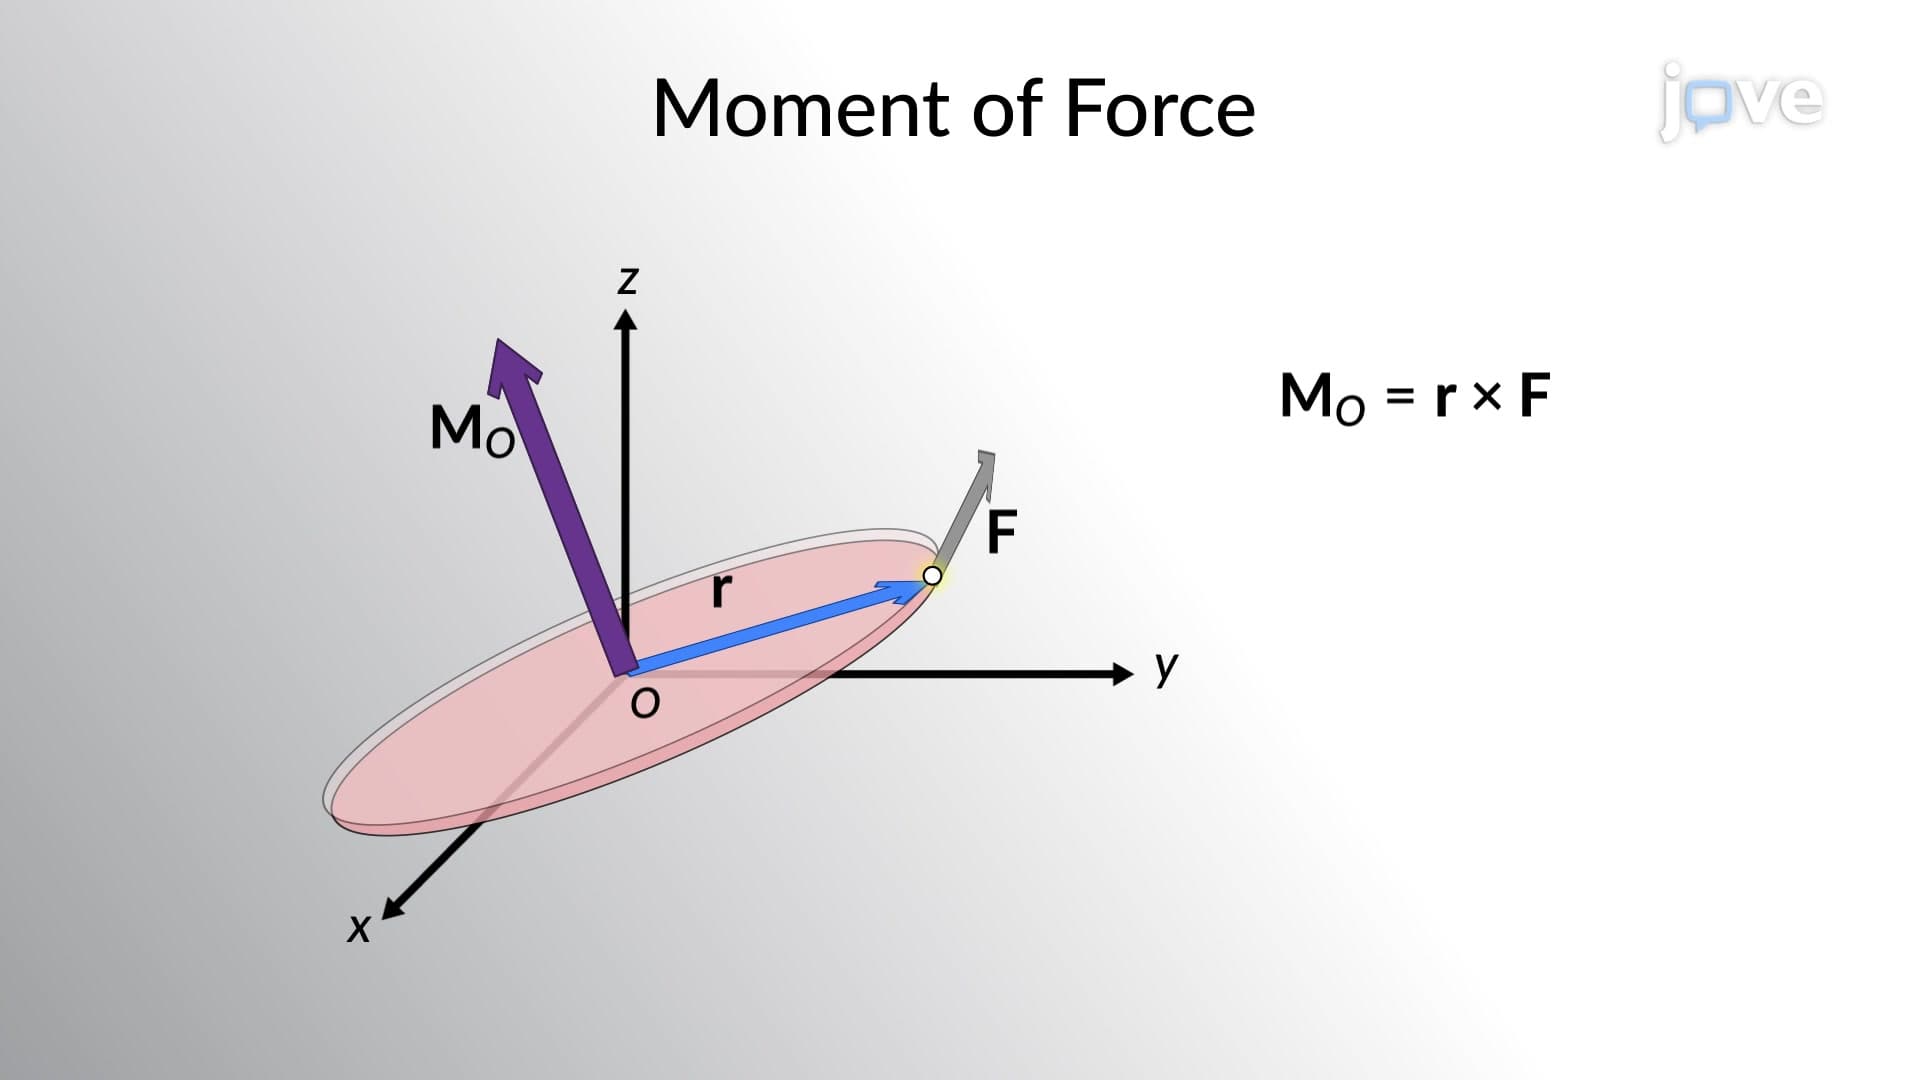 01:26
Cartesian Form for Vector Formulation
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:21
Equations of Motion: Rectangular Coordinates and Cylindrical Coordinates
When a particle moves relative to an inertial frame, the equations of motion can be expressed using rectangular components. If the motion is confined to the x-y plane, the equations having the x and y coordinates only can be used to simplify the mathematical representation.
However, when particles...