Related Experiment Video
Updated: Sep 25, 2026

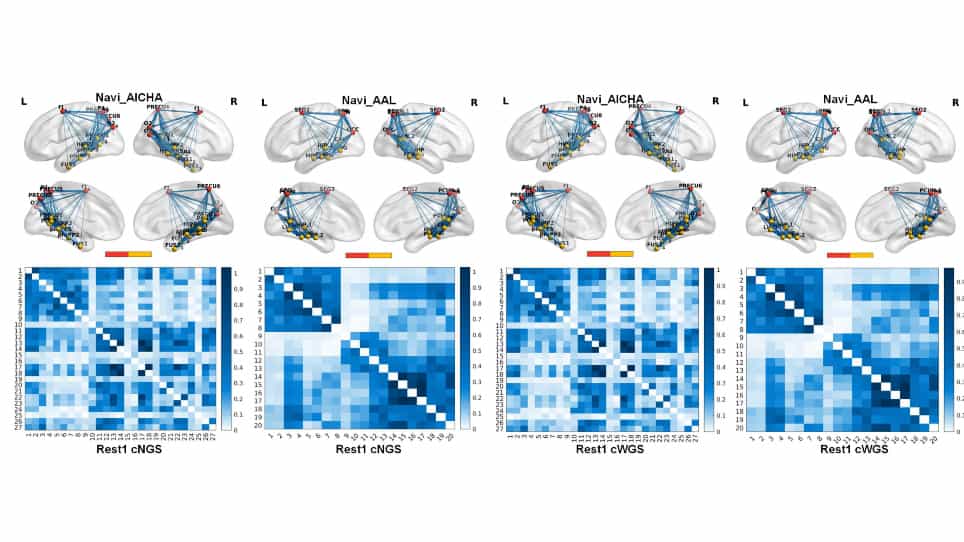
Assessing Human Spatial Navigation in a Virtual Space and its Sensitivity to Exercise
Published on: January 26, 2024
Spatial-Semantic Attention Network With Adaptive Similarity Perception and Memory for Efficient Zero-Shot Object-Goal

Abstract:
This article investigates efficient zero-shot object-goal visual navigation, where an agent localizes unseen targets in novel environments using only visual observations and target representations. Existing methods suffer from an inability to establish a unified visual representation, leading to complex and inefficient spatial-semantic joint matching. Moreover, current visual navigation frameworks, typically divided into Visual Perception and Policy Learning stages, fail to effectively leverage historical visual features, resulting in a weak connection between perception and decision-making. To overcome these limitations, we propose a novel multistage visual navigation paradigm, the spatial-semantic attention network with adaptive similarity perception and memory (S2AN-ASPM), which integrates three core components: 1) a similarity-aware module (SAM) that learns adaptive spatial-semantic embeddings through bilinear similarity metrics and dynamic attention; 2) a target-oriented memory-augmented (TOMA) branch that explicitly encodes historical trajectories and target positions via multiscale aggregation; and 3) a reinforcement learning (RL) policy optimized with a reward function balancing distance, view angle, and target relevance. To evaluate the navigation performance of S2AN-ASPM, we conducted extensive experiments in the AI2-THOR and Habitat HM3D embodied AI environments. Our method outperforms the previous state-of-the-art on the zero-shot ObjectNav task. The simulation results demonstrate the strong generalizability of S2AN-ASPM when dealing with unseen scenes and target objects. The code is available at https://github.com/zihaodong/S2AN-ASPM.