Related Experiment Video
Updated: Sep 30, 2026


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Design and implementation of a Wireless Power Transfer with double-sided LCC compensation for a farming robot
Aryadharma Sudhartio1, Marojahan Tampubolon1, Gervasius Geovan1,2
1Electrical Engineering Study Program, Universitas Multimedia Nusantara, Kabupaten Tangerang, Banten, Indonesia.

Abstract:
Farming robots are used nowadays to increase farming efficiency and production. In this paper, the Wireless Power Transfer (WPT) is proposed to be used as the enabler technology to support the autonomous characteristics of the robot. A low input voltage supplied from a solar panel is assumed as the source for the WPT system in this work. The mathematical modeling, design, and hardware implementation are discussed in this paper. The experimental results of WPT with double-sided LCC compensation maintained its efficiency to a certain distance with output power 5-76 W under the variation of coupling coefficient from 0.18 to 0.05. The peak efficiency obtained from the experiment was 69.19%. In addition, the study also showed that the output voltage of WPT can be regulated at 24V by changing the switching frequency of the inverter.
Related Concept Videos
 01:20
Power Factor Correction
 01:28
Load-frequency control
 01:17
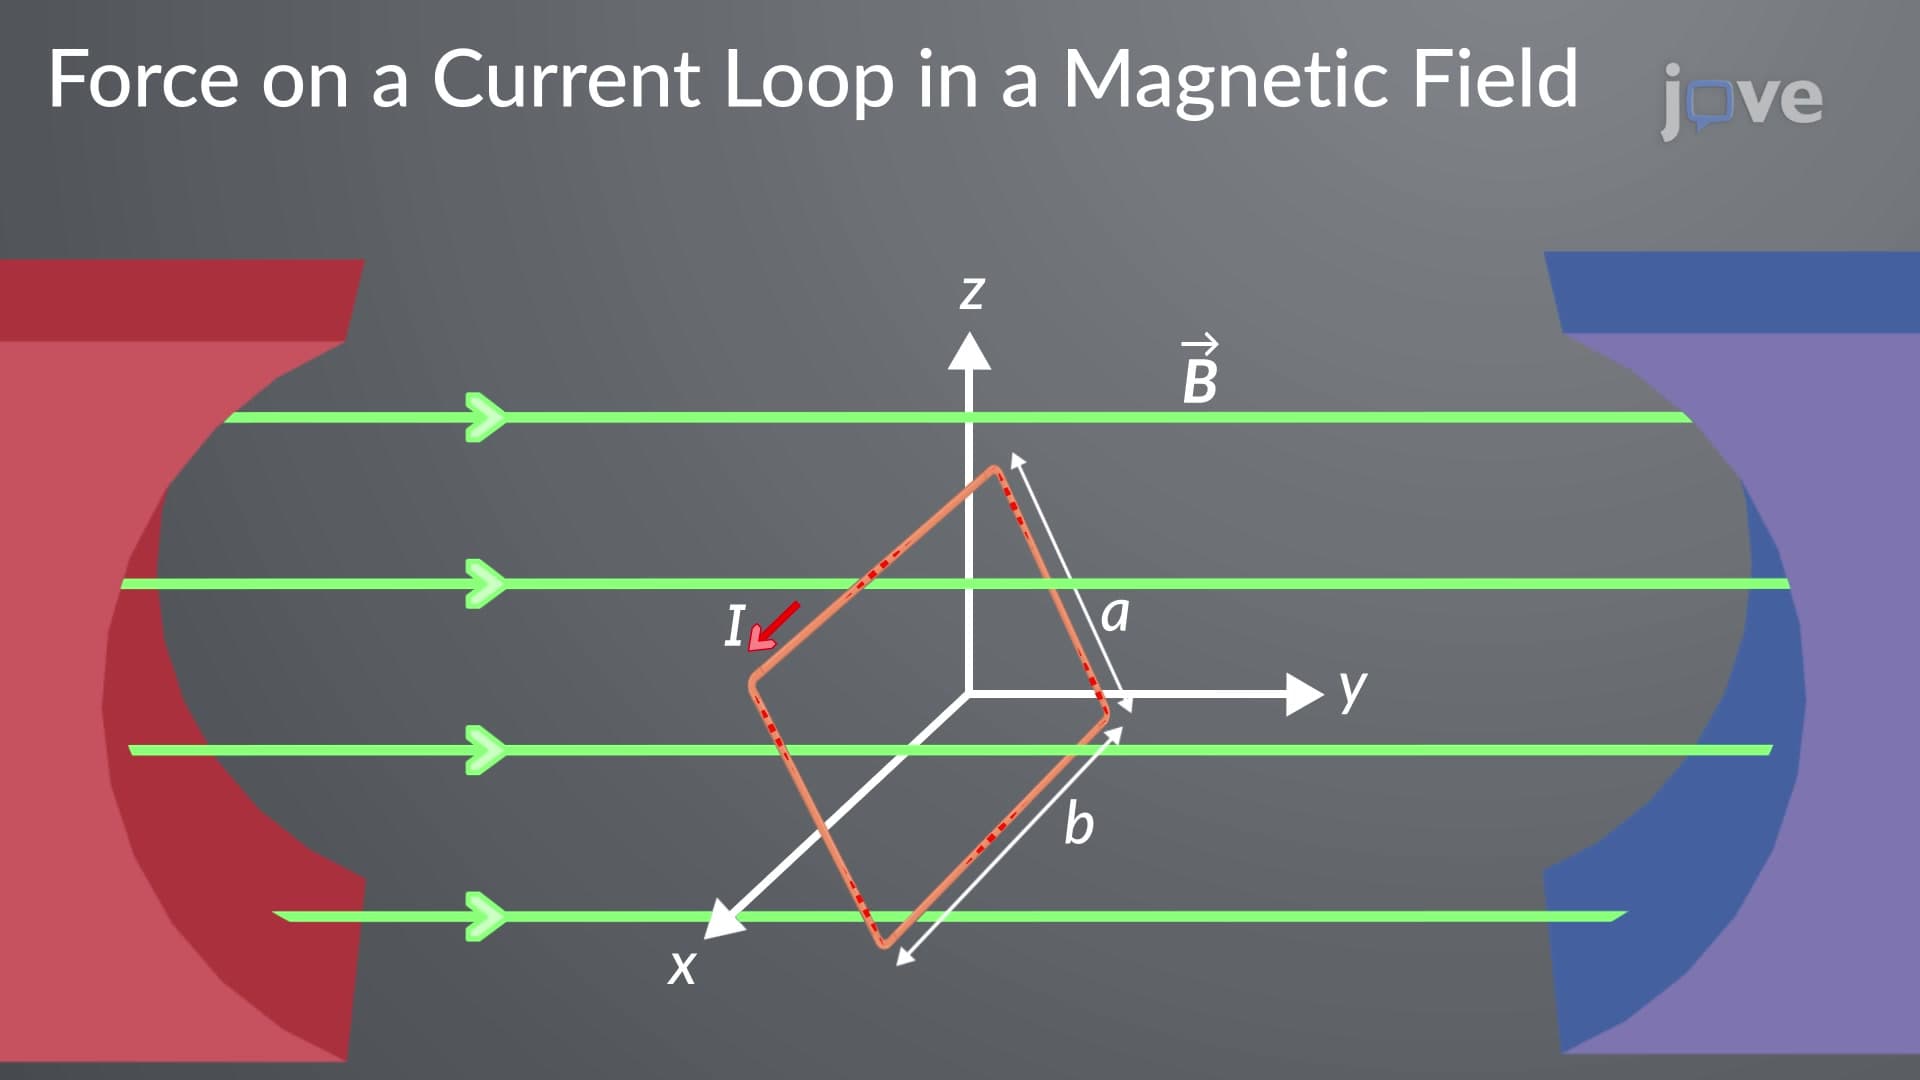
Force On A Current Loop In A Magnetic Field
 01:20
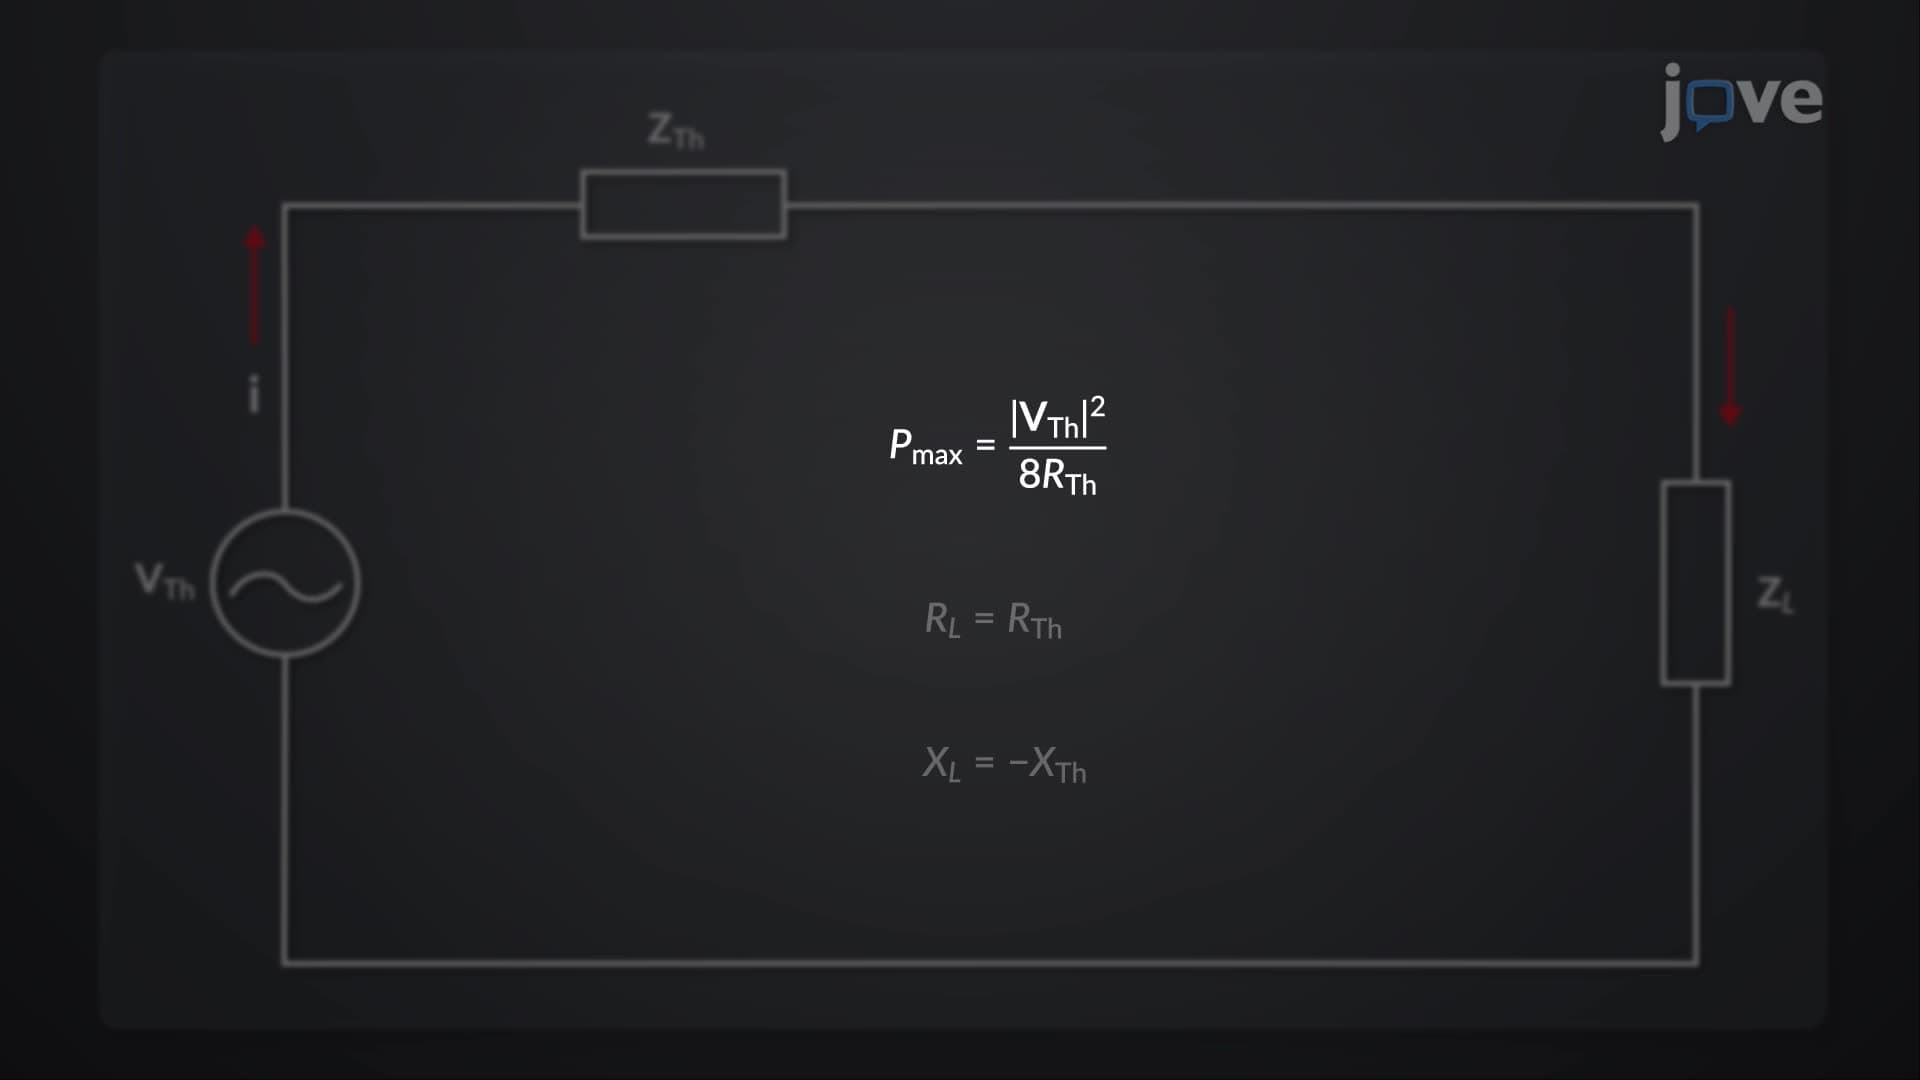
The Maximum Power Transfer Theorem
The load connected draws the current, and the circuit delivers the power to the load. The alternating current flowing through the load is determined using the rectangular form of voltages, currents, network impedance, and load impedance. The average power delivered to the load is obtained from the product of the square of current and load resistance.
 01:24
Fast Decoupled and DC Powerflow
 01:24
Comparison between RL and RC circuits